Skip to content

MAVLab

Micro Air Vehicle Lab – TUDelft

home
  • News
  • Research
    • Research Summary
    • Research
      • Robots
      • Code
      • Open-source code
      • Datasets
      • Competitions
    • Projects
      • Events
    • Spinoffs
  • People
  • Education
    • University Courses
    • Other
  • Publications and Datasets
    • Publications
    • Datasets
    • Open-source code
  • Media
  • Awards
  • Jobs
  • Contact
  • News
  • Research
    • Research Summary
    • Research
      • Robots
      • Code
      • Open-source code
      • Datasets
      • Competitions
    • Projects
      • Events
    • Spinoffs
  • People
  • Education
    • University Courses
    • Other
  • Publications and Datasets
    • Publications
    • Datasets
    • Open-source code
  • Media
  • Awards
  • Jobs
  • Contact

Category: Research

Autonomous swarm of tiny drones finds gas leaks
News, Research

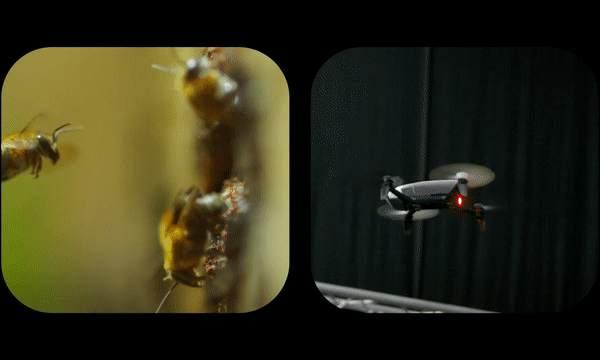
Swarm of autonomous tiny drones can localize gas leaks

Posted onJuly 14, 2021October 29, 2026

A gas leak in a large building or at an industrial site is difficult to find. Human firefighters cannot see the gas, so they have …
Datasets, News, Research

Learning process as a Solution to Fundamental Optical-flow Problems

Posted onJanuary 19, 2021October 30, 2026

Optical flow for small flying robots Flying insects heavily rely on optical flow for visual navigation and flight control. Roboticists have endowed small flying robots …
News, Robots

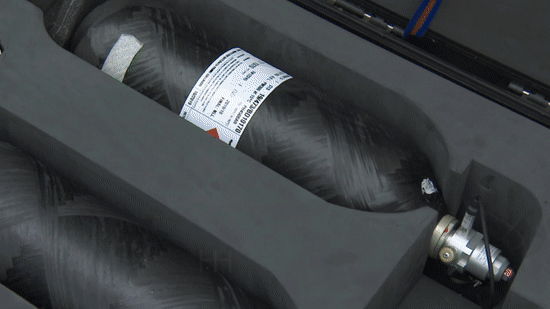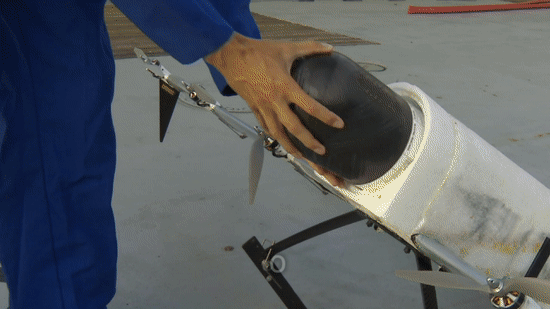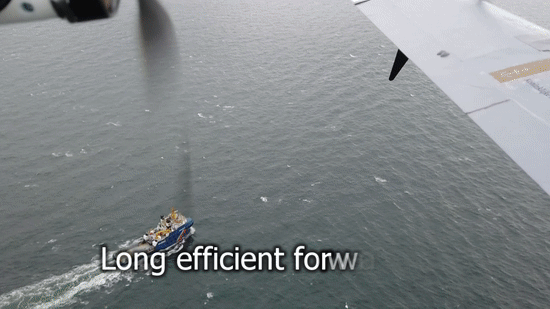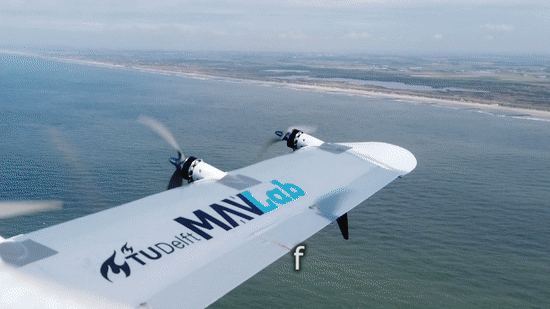
TU Delft maritime hydrogen drone flies longer and greener

Posted onNovember 10, 2020May 13, 2025

    A drone that can fly sustainably for long distances over land and water, and can land almost anywhere, will be able to serve …
Code, News, Robots

Neuromorphic control for optic-flow-based landings of MAVs using the Loihi processor

Posted onNovember 3, 2020October 30, 2026

    Neuromorphic processors like Loihi offer a promising alternative to conventional computing modules for endowing constrained systems like micro air vehicles (MAVs) with robust, …
Code, Research

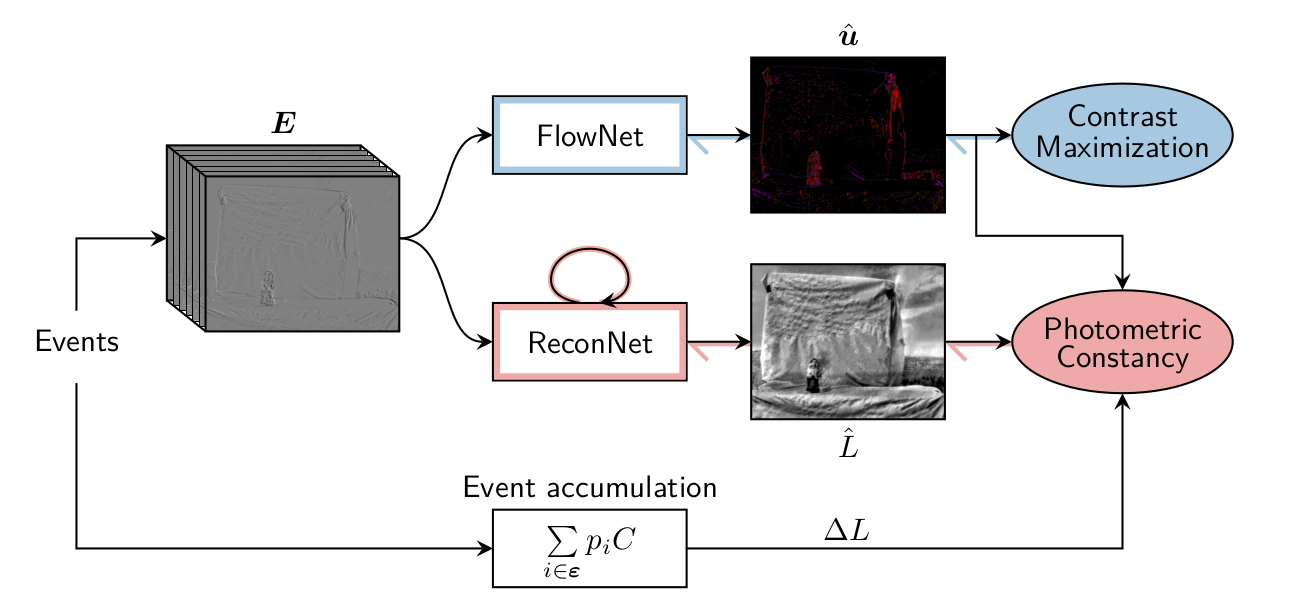
Back to Event Basics: Self-Supervised Learning of Image Reconstruction for Event Cameras via Photometric Constancy

Posted onSeptember 16, 2020October 30, 2026

F. Paredes-Valles, G. C. H. E. de Croon Event cameras are novel vision sensors that sample, in an asynchronous fashion, brightness increments with low latency …
Competitions, Datasets, News, Robots

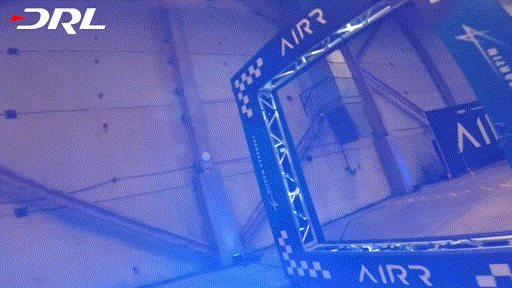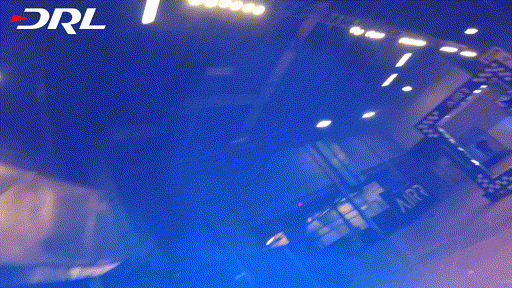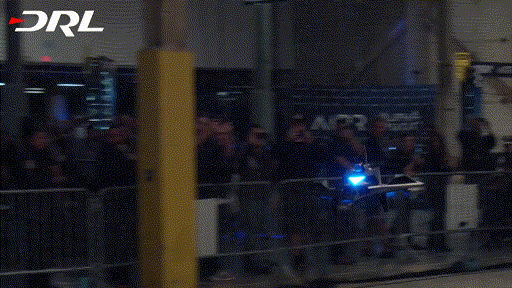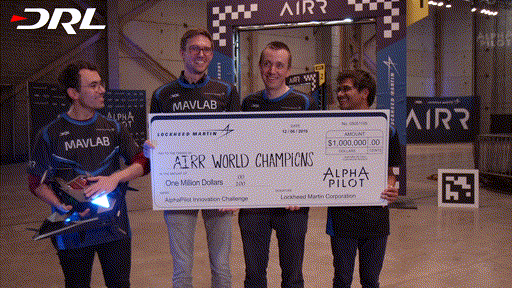
MAVLab wins the AlphaPilot AI challenge

Posted onDecember 9, 2019October 30, 2026

We are very proud to officially announce that we have won the AlphaPilot Drone Racing Innovation challenge!
Datasets, News, Robots

Swarm of tiny drones explores unknown environments

Posted onOctober 23, 2019October 30, 2026

Our latest paper in Science Robotics presents the first swarm of tiny robots that can explore unknown environments completely by themselves. No map, no memory, and no GPS!
Projects, Robots

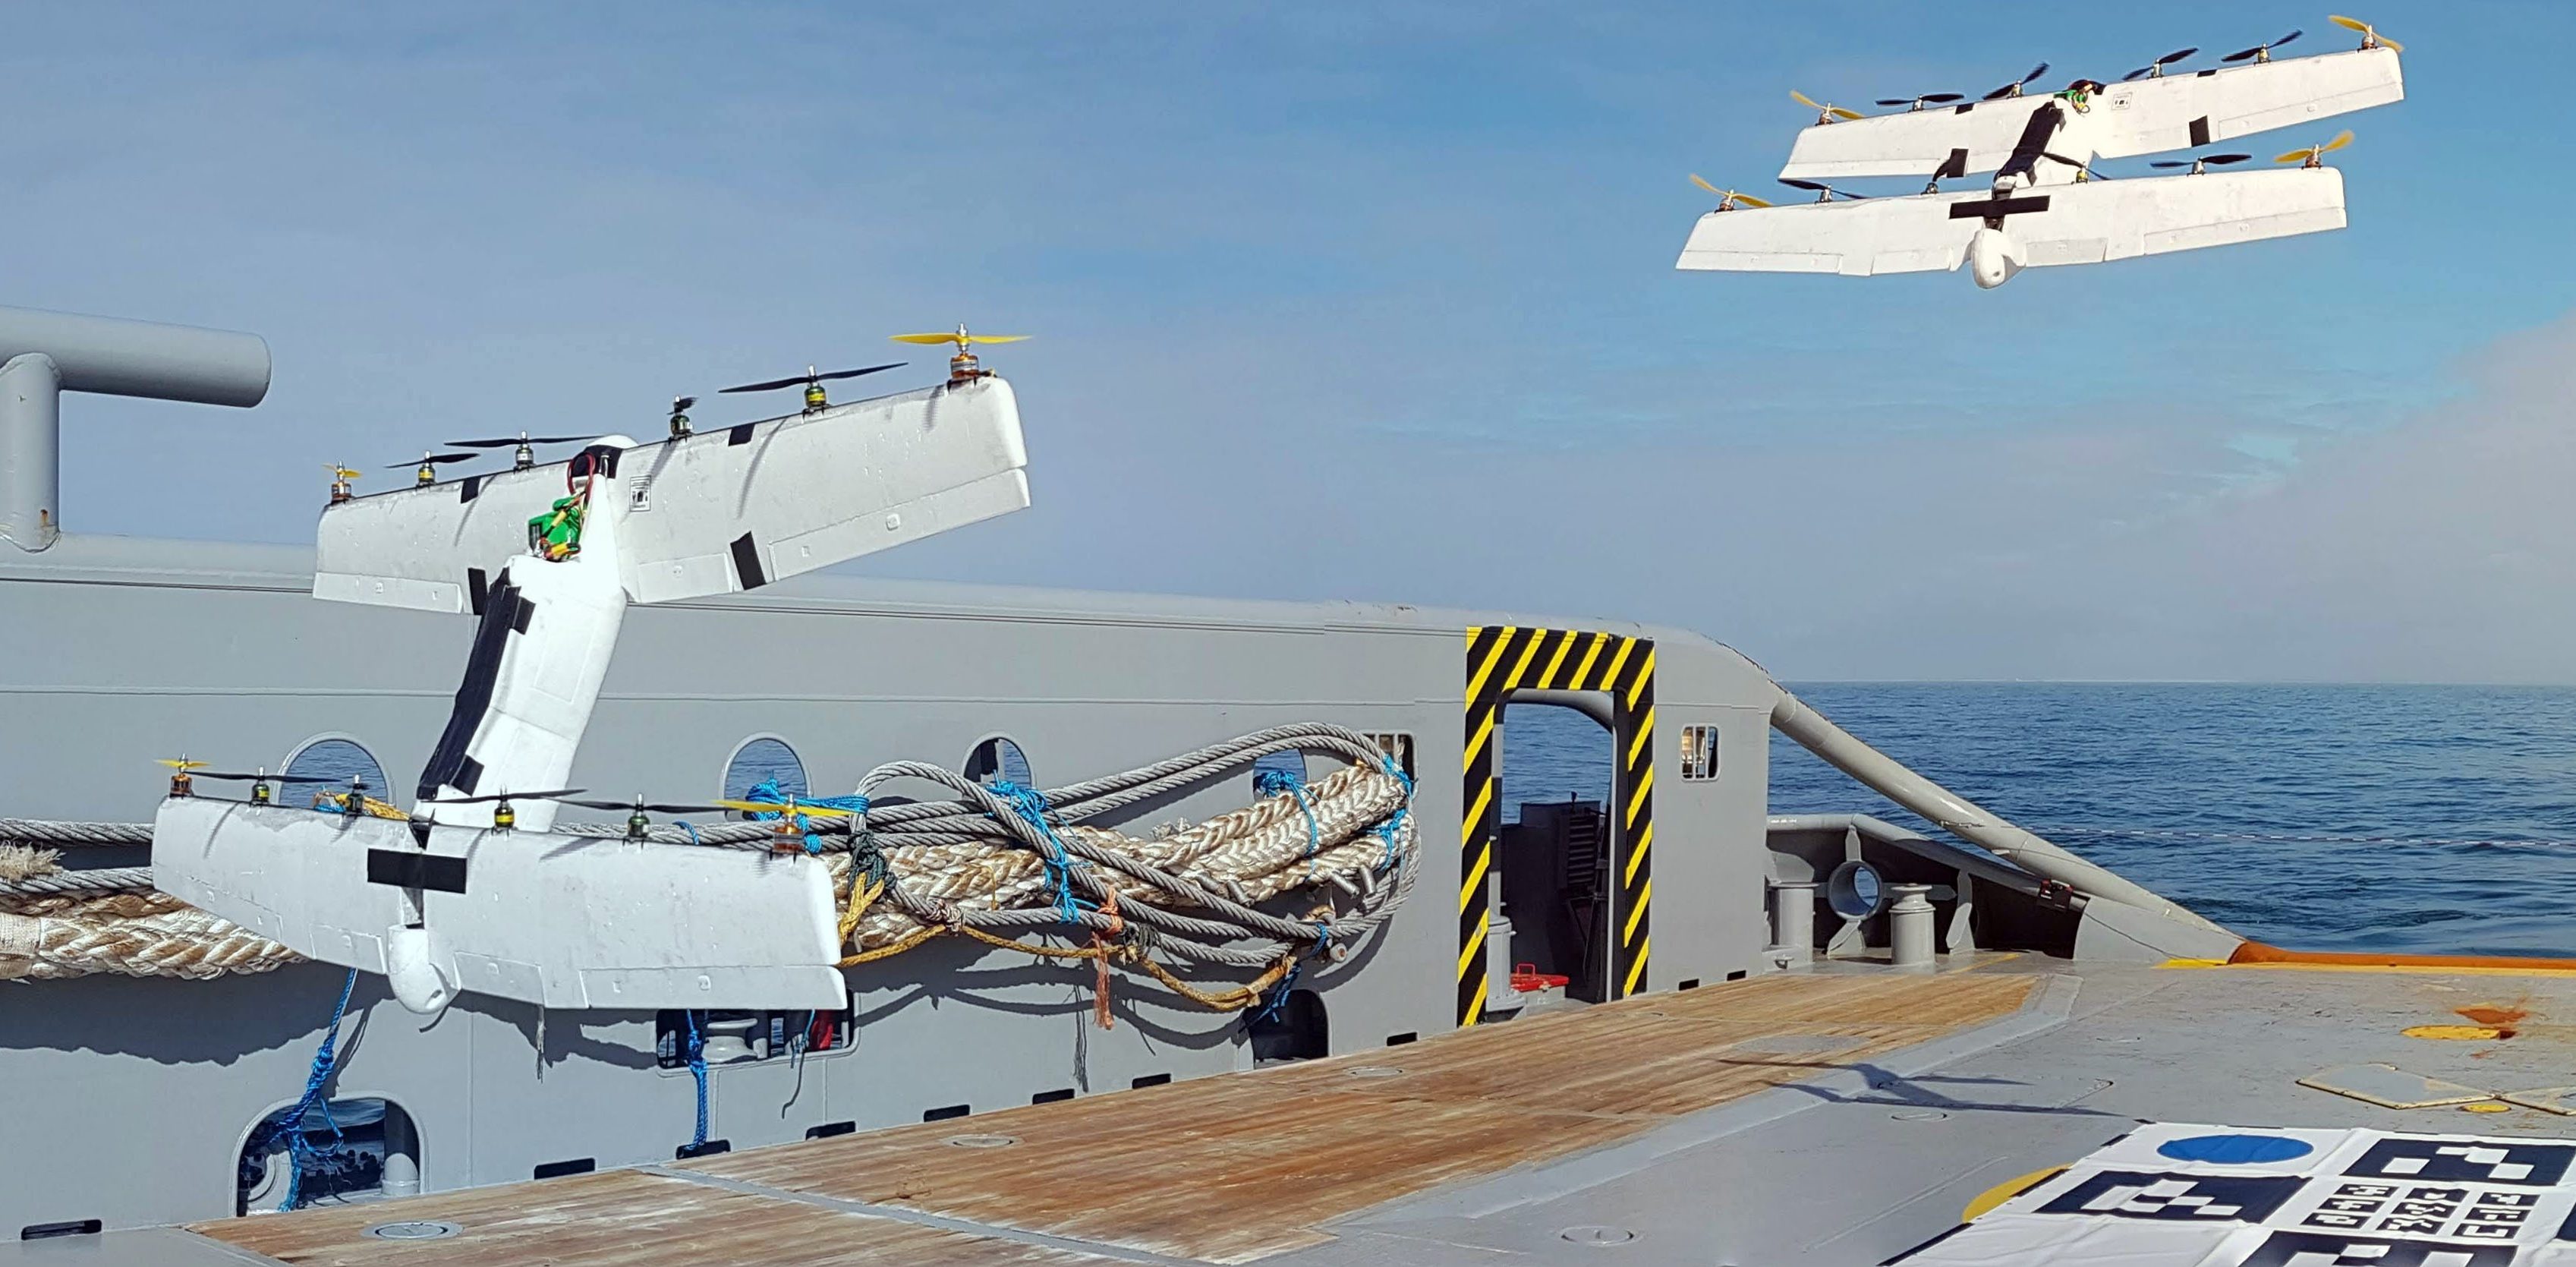
VTOL winged drone for Maritime Operations

Posted onOctober 16, 2019October 30, 2026

Design and Testing of a Vertical take-off and Landing UAV optimized for carrying a Hydrogen Fuel-cell with Pressure Tank.
News, Robots

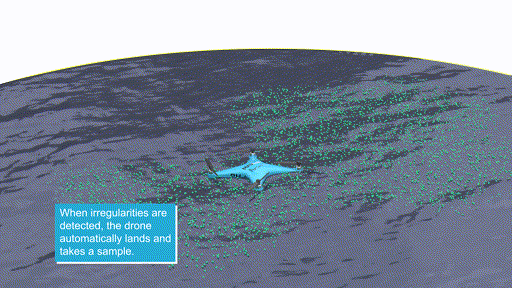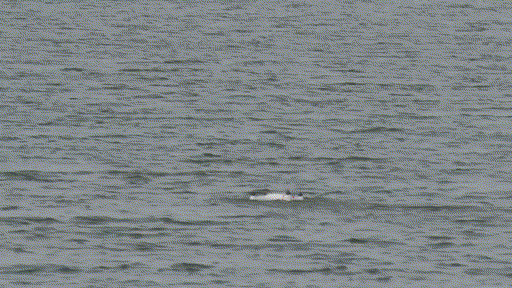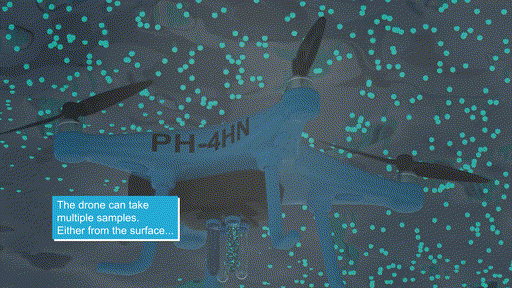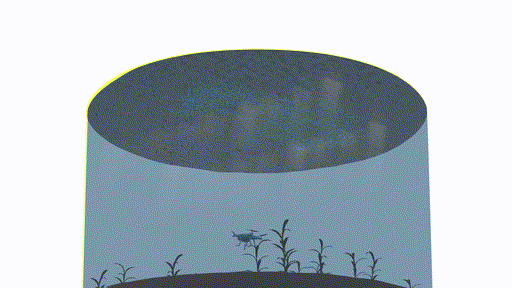
Pelican drone ensures super quick water sampling

Posted onSeptember 25, 2019December 4, 2019

researchers from TU Delft have developed a ‘pelican drone’: a drone capable of taking water samples quickly, in combination with a measuring instrument that immediately analyses the water quality.
News, Robots

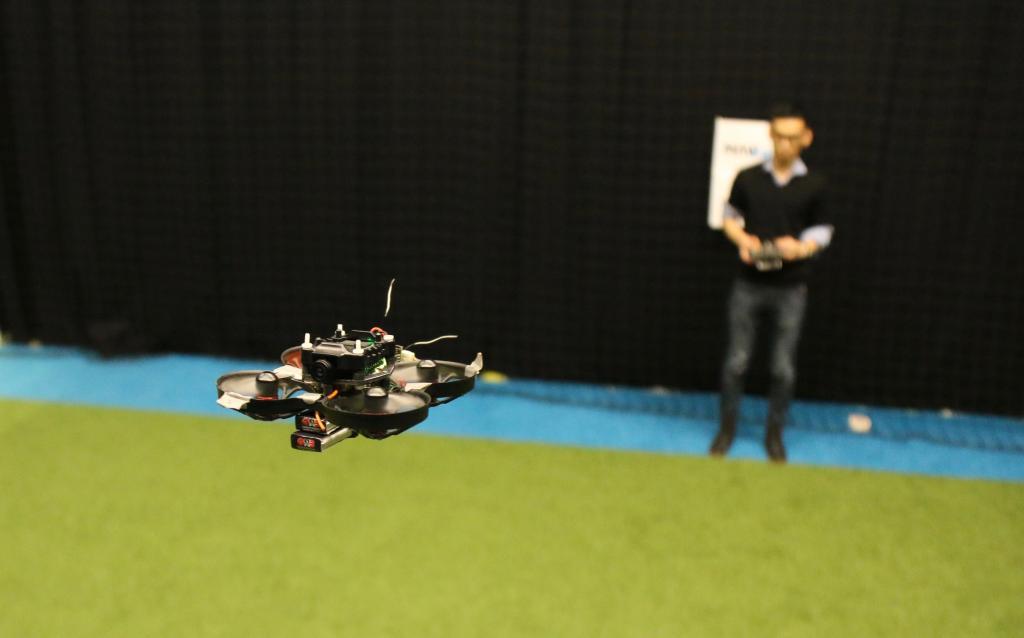
The world’s smallest autonomous racing drone

Posted onMay 27, 2019October 30, 2026

The drone racing team of the MAVLab has presented the currently smallest autonomous racing drone in the world.

Posts pagination

‹ 1 2 3 4 5 6 ‹
© 2026 MAVLab Powered by WordPress Theme by Design Lab