Skip to content

MAVLab

Micro Air Vehicle Lab – TUDelft

home
  • News
  • Research
    • Research Summary
    • Research
      • Robots
      • Code
      • Open-source code
      • Datasets
      • Competitions
    • Projects
      • Events
    • Spinoffs
  • People
  • Education
    • University Courses
    • Other
  • Publications and Datasets
    • Publications
    • Datasets
    • Open-source code
  • Media
  • Awards
  • Jobs
  • Contact
  • News
  • Research
    • Research Summary
    • Research
      • Robots
      • Code
      • Open-source code
      • Datasets
      • Competitions
    • Projects
      • Events
    • Spinoffs
  • People
  • Education
    • University Courses
    • Other
  • Publications and Datasets
    • Publications
    • Datasets
    • Open-source code
  • Media
  • Awards
  • Jobs
  • Contact

Category: Research

Code, Datasets, Research

Direct learning of home vector direction for insect-inspired robot navigation (ICRA’24)

Posted onApril 28, 2024October 30, 2026

Abstract Insects have long been recognized for their ability to navigate and return home using visual cues from their nest’s environment. However, the precise mechanism …
News, Research

ALBERO: Agile Dynamic Perching of Quadrotors on Real Tree Branches

Posted onFebruary 15, 2024October 28, 2026

The work from PhD candidate Liming Zheng and Assistant Professor Salua Hamaza from the BioMorphic Intelligence Lab was published in the journal of IEEE Robotics and Automation …
News, Research

End-to-end neural network based optimal quadcopter control

Posted onJanuary 24, 2024

With an escalating demand for quadcopters in emergency response, inspection and delivery, the need for speed and energy efficiency is paramount. However, developing autonomous systems …
News, Research

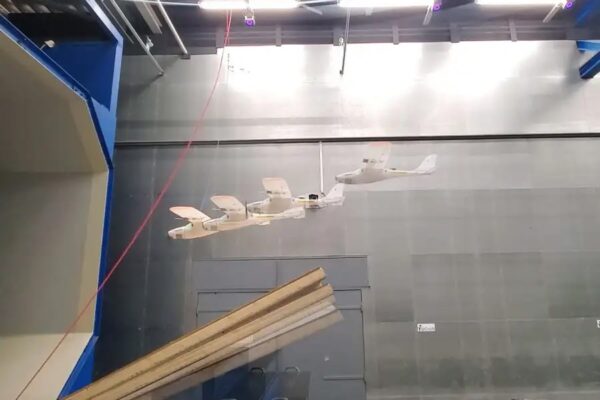
Never Landing Drone: Bird-inspired Autonomous Orographic Soaring

Posted onOctober 25, 2023October 29, 2026

Birds display remarkable adaptability in harnessing their surroundings for efficient flight, exemplified by the ingenious behavior observed in Kestrels. These birds employ a unique technique …
Code, Research

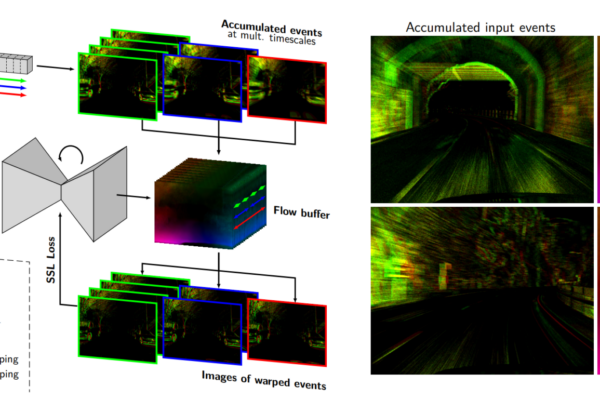
Taming Contrast Maximization for Learning Sequential, Low-latency, Event-based Optical Flow

Posted onAugust 11, 2023October 30, 2026

    Federico Paredes-Vallés, Kirk W. Y. Scheper, Christophe De Wagter, Guido C. H. E. de Croon   Event cameras have recently gained significant traction …
Code, Events, News, Research

AvoidBench @ ICRA 2023

Posted onJune 1, 2023October 30, 2026

At ICRA (IEEE International Conference on Robotics and Automation) 2023, MAVLab presented AvoidBench, a high-fidelity vision-based obstacle avoidance benchmarking suite for multi-rotors. Motivation Vision-based obstacle …
Datasets, News, Research

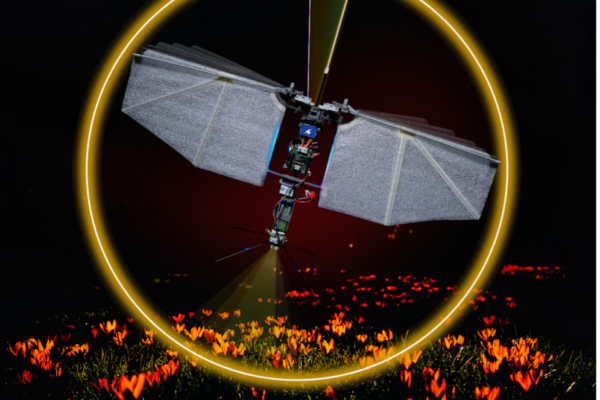
Nature article reveals how flying insects and drones can discern up from down

Posted onOctober 19, 2022October 30, 2026

Researchers from MAVLab and collaborators have developed a new theory on how flying drones and insects can estimate the gravity direction. Whereas drones typically use …
News, Research

Insect-inspired AI for autonomous robots

Posted onJune 15, 2022October 29, 2026

Insect-inspired AI for autonomous robots Small autonomous mobile robots, such as drones, rovers, and legged robots, promise to perform a wide range of tasks, from …
News, Robots

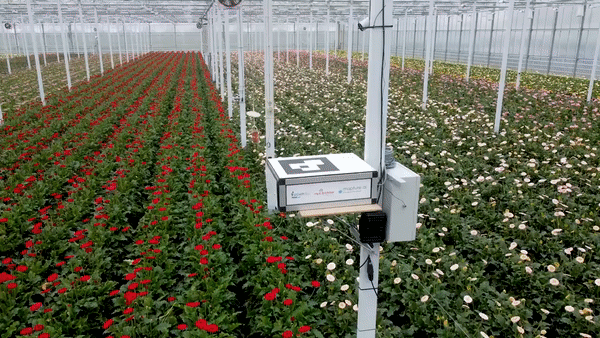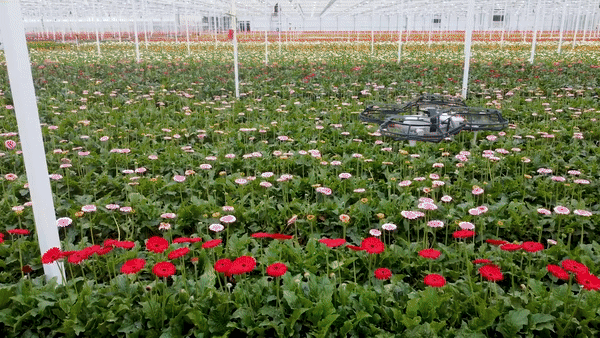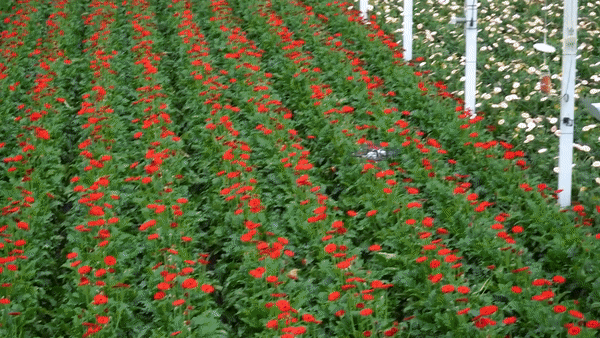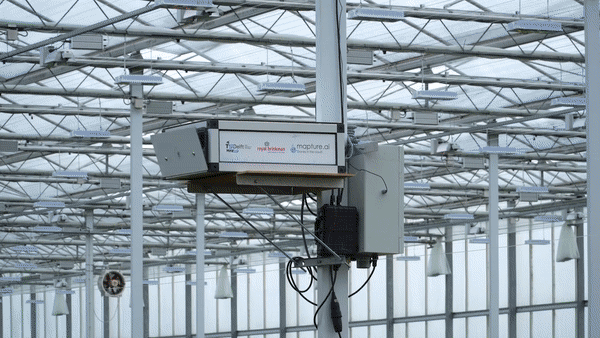
Self-flying drones that monitor greenhouse diseases and pests

Posted onMay 31, 2022October 30, 2026

We have teamed up with Royal Brinkman and start-up Mapture to develop AI and drone technology for greenhouse monitoring. These lightweight drones are able to …

Code, Research

Self-Supervised Learning of Event-Based Optical Flow with Spiking Neural Networks

Posted onOctober 25, 2021October 30, 2026

    Jesse J. Hagenaars*, Federico Paredes-Vallés*, Guido C.H.E. de Croon   The field of neuromorphic computing promises extremely low-power and low-latency sensing and processing. …

Posts pagination

‹ 1 2 3 4 … 6 ‹
© 2026 MAVLab Powered by WordPress Theme by Design Lab