2026
|
Journal Articles
|
J. R.E. Cooke; S. N. Lingam; P. Alavian; C. Collast; G. C.H.E. de Croon; M. Franssen; J. Hagenaars; J. Kober; P. Morsink; K. Liu; Y. H. Liu; E. Matthews; J. Mejias; A. Palffy; C. M.A. Pennartz; W. Sanberg; L. Selen; T. Sun; N. van Nes; R. Verstegen; M. Martens; J. Alsono-Mora; W. P. Medendorp; S. M. Bohte Navigating uncertainty: Safety solutions for autonomous vehicle integration into mixed-mode mobility (Journal Article) In: Transportation Research Interdisciplinary Perspectives, vol. 39, 2026, ISSN: 2590-1982, (Publisher Copyright: © 2026 The Authors.). @article{d48d4ab90495468abd9597552f41aa6b,
title = {Navigating uncertainty: Safety solutions for autonomous vehicle integration into mixed-mode mobility},
author = { J. R.E. Cooke and S. N. Lingam and P. Alavian and C. Collast and G. C.H.E. de Croon and M. Franssen and J. Hagenaars and J. Kober and P. Morsink and K. Liu and Y. H. Liu and E. Matthews and J. Mejias and A. Palffy and C. M.A. Pennartz and W. Sanberg and L. Selen and T. Sun and N. van Nes and R. Verstegen and M. Martens and J. Alsono-Mora and W. P. Medendorp and S. M. Bohte},
url = {https://research.tudelft.nl/en/publications/navigating-uncertainty-safety-solutions-for-autonomous-vehicle-in/},
doi = {10.1016/j.trip.2026.102141},
issn = {2590-1982},
year = {2026},
date = {2026-09-01},
journal = {Transportation Research Interdisciplinary Perspectives},
volume = {39},
publisher = {Elsevier},
note = {Publisher Copyright: © 2026 The Authors.},
keywords = {},
pubstate = {published},
tppubtype = {article}
}
|
Rita Santos Raminhos; Salua Hamaza Task-Oriented Path Planning Towards Autonomous Sensor Network Deployment in Rainforest Canopies (Journal Article) In: Advanced Robotics Research, vol. n/a, no. n/a, pp. e202500198, 2026, ISSN: 2943-9973. @article{4c530f26799f487d9cf91d06923c1146,
title = {Task-Oriented Path Planning Towards Autonomous Sensor Network Deployment in Rainforest Canopies},
author = { Rita Santos Raminhos and Salua Hamaza},
url = {https://research.tudelft.nl/en/publications/task-oriented-path-planning-towards-autonomous-sensor-network-dep/},
doi = {10.1002/adrr.202500198},
issn = {2943-9973},
year = {2026},
date = {2026-01-01},
journal = {Advanced Robotics Research},
volume = {n/a},
number = {n/a},
pages = {e202500198},
publisher = {Wiley},
keywords = {},
pubstate = {published},
tppubtype = {article}
}
|
Evangelos Ntouros; Ewoud J. J. Smeur Guiding-Vector-Field-Based Guidance Under Wind Disturbances Applied to a Tailsitter Drone (Journal Article) In: Journal of Guidance, Control, and Dynamics, 2026, ISSN: 0731-5090. @article{9a72c9f9161f430d97c67e5708259936,
title = {Guiding-Vector-Field-Based Guidance Under Wind Disturbances Applied to a Tailsitter Drone},
author = { Evangelos Ntouros and Ewoud J. J. Smeur},
url = {https://research.tudelft.nl/en/publications/guiding-vector-field-based-guidance-under-wind-disturbances-appli/},
doi = {10.2514/1.G009946},
issn = {0731-5090},
year = {2026},
date = {2026-01-01},
journal = {Journal of Guidance, Control, and Dynamics},
publisher = {American Institute of Aeronautics and Astronautics Inc. (AIAA)},
keywords = {},
pubstate = {published},
tppubtype = {article}
}
|
Anique Altena; Mirjam Snellen; Guido de Croon; Mark Voskuijl Joint sound source localisation of drones and other background sources (Journal Article) In: Applied Acoustics, vol. 254, 2026, ISSN: 0003-682X. @article{e8c6acfa3bec439db2f5fa74432a79ff,
title = {Joint sound source localisation of drones and other background sources},
author = { Anique Altena and Mirjam Snellen and Guido de Croon and Mark Voskuijl},
url = {https://research.tudelft.nl/en/publications/joint-sound-source-localisation-of-drones-and-other-background-so/},
doi = {10.1016/j.apacoust.2026.111474},
issn = {0003-682X},
year = {2026},
date = {2026-01-01},
journal = {Applied Acoustics},
volume = {254},
publisher = {Elsevier},
keywords = {},
pubstate = {published},
tppubtype = {article}
}
|
Moji Shi; Rajitha De Silva; Hang Yu; Riccardo Polvara; Marija Popovic Perception-Aware Autonomous Exploration in Feature-Limited Environments (Journal Article) In: IEEE Robotics and Automation Letters, vol. 11, no. 8, pp. 9970–9977, 2026, ISSN: 2377-3766. @article{8c3fe4321ded4aa0a7384b6d407c669a,
title = {Perception-Aware Autonomous Exploration in Feature-Limited Environments},
author = { Moji Shi and Rajitha De Silva and Hang Yu and Riccardo Polvara and Marija Popovic},
url = {https://research.tudelft.nl/en/publications/perception-aware-autonomous-exploration-in-feature-limited-enviro/},
doi = {10.1109/LRA.2026.3710053},
issn = {2377-3766},
year = {2026},
date = {2026-01-01},
journal = {IEEE Robotics and Automation Letters},
volume = {11},
number = {8},
pages = {9970–9977},
publisher = {IEEE},
keywords = {},
pubstate = {published},
tppubtype = {article}
}
|
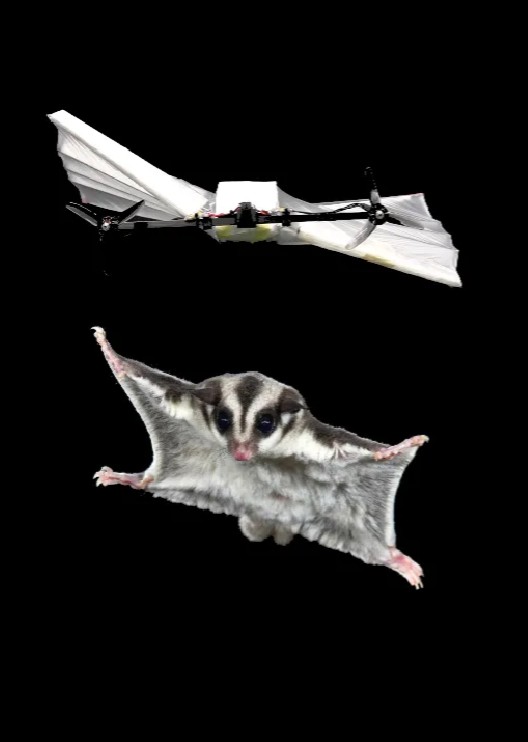
L. Zheng; A.H. van Zuijlen; S. Hamaza A squirrel-inspired drone with enhanced stability, agility and maneuverability via whole-body morphing (Journal Article) In: Nature Communications, vol. 17, no. 1, 2026, ISSN: 2041-1723. @article{27515743028c42ef9d82f33bf1244934,
title = {A squirrel-inspired drone with enhanced stability, agility and maneuverability via whole-body morphing},
author = { L. Zheng and A.H. van Zuijlen and S. Hamaza},
url = {https://research.tudelft.nl/en/publications/a-squirrel-inspired-drone-with-enhanced-stability-agility-and-man/},
doi = {10.1038/s41467-026-72822-w},
issn = {2041-1723},
year = {2026},
date = {2026-01-01},
journal = {Nature Communications},
volume = {17},
number = {1},
publisher = {Nature Research},
keywords = {},
pubstate = {published},
tppubtype = {article}
}
|
Salil Luesutthiviboon; Guido C.H.E. de Croon; Anique Altena; Mirjam Snellen; Mark Voskuijl Improving visual differentiation of drones and birds in aerial surveillance using trajectory features (Journal Article) In: Neural Computing and Applications, vol. 38, no. 12, 2026, ISSN: 0941-0643. @article{303fadd80ffa4a4eab120541e5e334cd,
title = {Improving visual differentiation of drones and birds in aerial surveillance using trajectory features},
author = { Salil Luesutthiviboon and Guido C.H.E. de Croon and Anique Altena and Mirjam Snellen and Mark Voskuijl},
url = {https://research.tudelft.nl/en/publications/improving-visual-differentiation-of-drones-and-birds-in-aerial-su/},
doi = {10.1007/s00521-026-12080-5},
issn = {0941-0643},
year = {2026},
date = {2026-01-01},
journal = {Neural Computing and Applications},
volume = {38},
number = {12},
publisher = {Springer},
keywords = {},
pubstate = {published},
tppubtype = {article}
}
|
Jasper Zevering; Joshua Braun; Martin Hesse; Kedus Mathewos; Dorit Borrmann; Anton Bredenbeck; Andreas Nüchter The Concept of the Virtual Pose Instruction Plane (VPIP) for Controlling Rod-Driven Spherical Robots (Journal Article) In: Machines, vol. 14, no. 5, 2026, ISSN: 2075-1702. @article{1a8035cce7804de98a6a48b336577f37,
title = {The Concept of the Virtual Pose Instruction Plane (VPIP) for Controlling Rod-Driven Spherical Robots},
author = { Jasper Zevering and Joshua Braun and Martin Hesse and Kedus Mathewos and Dorit Borrmann and Anton Bredenbeck and Andreas Nüchter},
url = {https://research.tudelft.nl/en/publications/the-concept-of-the-virtual-pose-instruction-plane-vpip-for-contro/},
doi = {10.3390/machines14050486},
issn = {2075-1702},
year = {2026},
date = {2026-01-01},
journal = {Machines},
volume = {14},
number = {5},
publisher = {MDPI},
keywords = {},
pubstate = {published},
tppubtype = {article}
}
|
Dequan Ou; Jesse J. Hagenaars; Maciej R. Jankowski; Michiel V.M. Firlefyn; Christophe De Wagter; Florian T. Muijres; Jacqueline Degen; Guido C.H.E. de Croon Efficient robot navigation inspired by honeybee learning flights (Journal Article) In: Nature, vol. 653, no. 8116, pp. 1039–1046, 2026, ISSN: 0028-0836. @article{c6052628b49b4ab0abcb61996006b162,
title = {Efficient robot navigation inspired by honeybee learning flights},
author = { Dequan Ou and Jesse J. Hagenaars and Maciej R. Jankowski and Michiel V.M. Firlefyn and Christophe De Wagter and Florian T. Muijres and Jacqueline Degen and Guido C.H.E. de Croon},
url = {https://research.tudelft.nl/en/publications/efficient-robot-navigation-inspired-by-honeybee-learning-flights/},
doi = {10.1038/s41586-026-10461-3},
issn = {0028-0836},
year = {2026},
date = {2026-01-01},
journal = {Nature},
volume = {653},
number = {8116},
pages = {1039–1046},
publisher = {Nature Research},
keywords = {},
pubstate = {published},
tppubtype = {article}
}
|
Sunyi Wang; Martijn den Hoed; Salua Hamaza Delfly Flex: a flapping wing micro air vehicle with a bio-inspired unibody composed of compliant joints (Journal Article) In: Bioinspiration and Biomimetics, vol. 21, no. 3, 2026, ISSN: 1748-3182. @article{0c9d0a1cb0074829a13229d93c06bfa6,
title = {Delfly Flex: a flapping wing micro air vehicle with a bio-inspired unibody composed of compliant joints},
author = { Sunyi Wang and Martijn den Hoed and Salua Hamaza},
url = {https://research.tudelft.nl/en/publications/delfly-flex-a-flapping-wing-micro-air-vehicle-with-a-bio-inspired/},
doi = {10.1088/1748-3190/ae5e10},
issn = {1748-3182},
year = {2026},
date = {2026-01-01},
journal = {Bioinspiration and Biomimetics},
volume = {21},
number = {3},
publisher = {IOP Publishing Ltd.},
keywords = {},
pubstate = {published},
tppubtype = {article}
}
|
Anton Bredenbeck; Anish Jadoenathmisier; Salua Hamaza Aerial tactile perching via an anthropomorphic hand with embodied soft tactile receptors (Journal Article) In: npj Robotics, vol. 4, no. 1, 2026, ISSN: 2731-4278. @article{93b9038eea2c4871b24fe03f61b8a8a5,
title = {Aerial tactile perching via an anthropomorphic hand with embodied soft tactile receptors},
author = { Anton Bredenbeck and Anish Jadoenathmisier and Salua Hamaza},
url = {https://research.tudelft.nl/en/publications/aerial-tactile-perching-via-an-anthropomorphic-hand-with-embodied/},
doi = {10.1038/s44182-026-00109-9},
issn = {2731-4278},
year = {2026},
date = {2026-01-01},
journal = {npj Robotics},
volume = {4},
number = {1},
keywords = {},
pubstate = {published},
tppubtype = {article}
}
|
Jesse J. Hagenaars; Stein Stroobants; Sander M. Bohté; Guido C.H.E. de Croon All eyes, no IMU: learning flight attitude from vision alone (Journal Article) In: npj Robotics, vol. 4, no. 1, 2026, ISSN: 2731-4278. @article{76fd3602bc5343378d3c83c26ee527f7,
title = {All eyes, no IMU: learning flight attitude from vision alone},
author = { Jesse J. Hagenaars and Stein Stroobants and Sander M. Bohté and Guido C.H.E. de Croon},
url = {https://research.tudelft.nl/en/publications/all-eyes-no-imu-learning-flight-attitude-from-vision-alone/},
doi = {10.1038/s44182-026-00081-4},
issn = {2731-4278},
year = {2026},
date = {2026-01-01},
journal = {npj Robotics},
volume = {4},
number = {1},
keywords = {},
pubstate = {published},
tppubtype = {article}
}
|
Gang Chen; Moji Shi; Yu Xing; Marija Popović; Javier Alonso-Mora; Lei Zhang; Jiangmiao Pang Automatic personalized limbed robot design from media inputs (Journal Article) In: npj Robotics, vol. 4, no. 1, 2026, ISSN: 2731-4278. @article{f127b463815e408483538d9536168ffd,
title = {Automatic personalized limbed robot design from media inputs},
author = { Gang Chen and Moji Shi and Yu Xing and Marija Popovi{ć} and Javier Alonso-Mora and Lei Zhang and Jiangmiao Pang},
url = {https://research.tudelft.nl/en/publications/automatic-personalized-limbed-robot-design-from-media-inputs/},
doi = {10.1038/s44182-026-00101-3},
issn = {2731-4278},
year = {2026},
date = {2026-01-01},
journal = {npj Robotics},
volume = {4},
number = {1},
keywords = {},
pubstate = {published},
tppubtype = {article}
}
|
Xingguang Zhong; Yue Pan; Liren Jin; Marija Popović; Jens Behley; Cyrill Stachniss Globally Consistent RGB-D SLAM with 2-D Gaussian Splatting (Journal Article) In: IEEE Transactions on Robotics, vol. 42, pp. 2360–2380, 2026, ISSN: 1552-3098. @article{dad6adcad38f46fbb41c69e484d573ca,
title = {Globally Consistent RGB-D SLAM with 2-D Gaussian Splatting},
author = { Xingguang Zhong and Yue Pan and Liren Jin and Marija Popovi{ć} and Jens Behley and Cyrill Stachniss},
url = {https://research.tudelft.nl/en/publications/globally-consistent-rgb-d-slam-with-2-d-gaussian-splatting/},
doi = {10.1109/TRO.2026.3697159},
issn = {1552-3098},
year = {2026},
date = {2026-01-01},
journal = {IEEE Transactions on Robotics},
volume = {42},
pages = {2360–2380},
publisher = {IEEE},
keywords = {},
pubstate = {published},
tppubtype = {article}
}
|
Sanjeev Ramkumar Sudha; Marija Popović; Erlend M. Coates An Informative Planning Framework for Target Tracking and Active Mapping in Dynamic Environments with ASVs (Journal Article) In: IEEE Robotics and Automation Letters, vol. 11, no. 3, pp. 2690–2697, 2026, ISSN: 2377-3766. @article{7305ebfe315b4f389de941fae63908a4,
title = {An Informative Planning Framework for Target Tracking and Active Mapping in Dynamic Environments with ASVs},
author = { Sanjeev Ramkumar Sudha and Marija Popovi{ć} and Erlend M. Coates},
url = {https://research.tudelft.nl/en/publications/an-informative-planning-framework-for-target-tracking-and-active-/},
doi = {10.1109/LRA.2026.3653335},
issn = {2377-3766},
year = {2026},
date = {2026-01-01},
journal = {IEEE Robotics and Automation Letters},
volume = {11},
number = {3},
pages = {2690–2697},
publisher = {IEEE},
keywords = {},
pubstate = {published},
tppubtype = {article}
}
|
Stavrow A. Bahnam; Robin Ferede; Till M. Blaha; Anton E. Lang; Erin Lucassen; Quentin Missinne; Aderik E. C. Verraest; Christophe De Wagter; Guido C. H. E. de Croon MonoRace: Winning Champion-Level Drone Racing with Robust Monocular AI (Journal Article) In: 2026. @article{2601.15222,
title = {MonoRace: Winning Champion-Level Drone Racing with Robust Monocular AI},
author = { Stavrow A. Bahnam and Robin Ferede and Till M. Blaha and Anton E. Lang and Erin Lucassen and Quentin Missinne and Aderik E. C. Verraest and Christophe De Wagter and Guido C. H. E. de Croon},
url = {https://arxiv.org/abs/2601.15222},
doi = {10.1126/scirobotics.aee9250},
year = {2026},
date = {2026-01-01},
keywords = {},
pubstate = {published},
tppubtype = {article}
}
|
Evangelos Ntouros; Pavel Kelley; Ewoud J.J. Smeur Airspeed estimation for UAVs using only propeller feedback (Journal Article) In: Aerospace Science and Technology, vol. 168, 2026, ISSN: 1270-9638. @article{7e2450c2f066460b9bdffa8ce5680924,
title = {Airspeed estimation for UAVs using only propeller feedback},
author = { Evangelos Ntouros and Pavel Kelley and Ewoud J.J. Smeur},
url = {https://research.tudelft.nl/en/publications/airspeed-estimation-for-uavs-using-only-propeller-feedback/},
doi = {10.1016/j.ast.2025.110999},
issn = {1270-9638},
year = {2026},
date = {2026-01-01},
journal = {Aerospace Science and Technology},
volume = {168},
publisher = {Elsevier Masson},
keywords = {},
pubstate = {published},
tppubtype = {article}
}
|
Ernesto Sanchez-Laulhe; Guido C.H.E. De Croon; Anibal Ollero Equilibrium State for a Tailless Flapping Wing Micro Air Vehicle in Forward Flight (Journal Article) In: IEEE Robotics and Automation Letters, vol. 11, no. 1, pp. 17–24, 2026, ISSN: 2377-3766, (Green Open Access added to TU Delft Institutional Repository as part of the Taverne amendment. More information about this copyright law amendment can be found at https://www.openaccess.nl. Otherwise as indicated in the copyright section: the publisher is the copyright holder of this work and the author uses the Dutch legislation to make this work public.). @article{d2ee299f8656477da479e32aaf780476,
title = {Equilibrium State for a Tailless Flapping Wing Micro Air Vehicle in Forward Flight},
author = { Ernesto Sanchez-Laulhe and Guido C.H.E. De Croon and Anibal Ollero},
url = {https://research.tudelft.nl/en/publications/equilibrium-state-for-a-tailless-flapping-wing-micro-air-vehicle-/},
doi = {10.1109/LRA.2025.3629992},
issn = {2377-3766},
year = {2026},
date = {2026-01-01},
journal = {IEEE Robotics and Automation Letters},
volume = {11},
number = {1},
pages = {17–24},
publisher = {IEEE},
note = {Green Open Access added to TU Delft Institutional Repository as part of the Taverne amendment. More information about this copyright law amendment can be found at https://www.openaccess.nl. Otherwise as indicated in the copyright section: the publisher is the copyright holder of this work and the author uses the Dutch legislation to make this work public.},
keywords = {},
pubstate = {published},
tppubtype = {article}
}
|
Martijn B. J. Brummelhuis; Nathan F. Lepora; Salua Hamaza Omnidirectional Dual-Arm Aerial Manipulator with Proprioceptive Contact Localization for Landing on Slanted Roofs (Journal Article) In: 2026. @article{2602.10703,
title = {Omnidirectional Dual-Arm Aerial Manipulator with Proprioceptive Contact Localization for Landing on Slanted Roofs},
author = { Martijn B. J. Brummelhuis and Nathan F. Lepora and Salua Hamaza},
url = {https://arxiv.org/abs/2602.10703},
doi = {10.1109/ICRA57385.2026.11697086},
year = {2026},
date = {2026-01-01},
howpublished = {2026 IEEE International Conference on Robotics and Automation (ICRA)},
keywords = {},
pubstate = {published},
tppubtype = {article}
}
|
S. Hafner; T. De Ponti; E. Smeur On the Equivalence of Sensory and Incremental Nonlinear Dynamic Inversion (Journal Article) In: IEEE Open Journal of Control Systems, vol. 5, pp. 136–148, 2026, ISSN: 2694-085X. @article{c39095627483482eb22d95746af0143d,
title = {On the Equivalence of Sensory and Incremental Nonlinear Dynamic Inversion},
author = { S. Hafner and T. De Ponti and E. Smeur},
url = {https://research.tudelft.nl/en/publications/on-the-equivalence-of-sensory-and-incremental-nonlinear-dynamic-i/},
doi = {10.1109/OJCSYS.2026.3669038},
issn = {2694-085X},
year = {2026},
date = {2026-01-01},
journal = {IEEE Open Journal of Control Systems},
volume = {5},
pages = {136–148},
publisher = {Institute of Electrical and Electronics Engineers},
keywords = {},
pubstate = {published},
tppubtype = {article}
}
|
Tomaso De Ponti; Simon Hafner; Ewoud Smeur; Bart Remes Actuator nonlinear dynamic inversion for the variable skew quad plane with heterogeneous motor dynamics (Journal Article) In: Control Engineering Practice, vol. 171, 2026, ISSN: 0967-0661. @article{52e68ccf76274f4980ad3661f909075b,
title = {Actuator nonlinear dynamic inversion for the variable skew quad plane with heterogeneous motor dynamics},
author = { Tomaso De Ponti and Simon Hafner and Ewoud Smeur and Bart Remes},
url = {https://research.tudelft.nl/en/publications/actuator-nonlinear-dynamic-inversion-for-the-variable-skew-quad-p/},
doi = {10.1016/j.conengprac.2026.106858},
issn = {0967-0661},
year = {2026},
date = {2026-01-01},
journal = {Control Engineering Practice},
volume = {171},
publisher = {Elsevier},
keywords = {},
pubstate = {published},
tppubtype = {article}
}
|
data
|
Stavrow Bahnam; Robin Ferede; Till Blaha; Anton Lang; Erin Lucassen; Quentin Missinne; Aderik Verraest; Christophe De Wagter; Guido de Croon Data and Code underlying the publication: MonoRace: Robust Monocular AI for Champion-Level Drone Racing (data) 2026, (Software). @data{10.4121/039abd82-094c-4c93-baa1-e7446f562e0e,
title = {Data and Code underlying the publication: MonoRace: Robust Monocular AI for Champion-Level Drone Racing},
author = { Stavrow Bahnam and Robin Ferede and Till Blaha and Anton Lang and Erin Lucassen and Quentin Missinne and Aderik Verraest and Christophe De Wagter and Guido de Croon},
url = {https://doi.org/10.4121/039abd82-094c-4c93-baa1-e7446f562e0e},
doi = {10.4121/039abd82-094c-4c93-baa1-e7446f562e0e},
year = {2026},
date = {2026-01-01},
publisher = {4TU.ResearchData},
abstract = {Data underlying the publication: MonoRACE: Winning Champion-Level Drone Racing with Robust Monocular AI This dataset supports the publication “MonoRACE: Winning Champion-Level Drone Racing with Robust Monocular AI” . The research investigates robust autonomous high-speed drone racing using a single forward-facing monocular camera and an onboard IMU, with the goal of enabling reliable gate detection, state estimation, and control during aggressive flight. The dataset contains flight-log data from eight autonomous drone racing flights, providing experimental data collected during the development and evaluation of the MonoRACE system. The flight logs contain onboard sensor and flight-control data used to analyse the behaviour and robustness of the system during racing. In addition to the flight data, the dataset includes the software components used in the experiments: the MonoRaceGate implementation for monocular gate-based navigation, the INDIFlight flight-control software, and the Optimal Quad Control reinforcement-learning controller developed for the A2RL 2025 autonomous drone racing competition. These components provide the research and implementation context needed to interpret and potentially reuse the data. The dataset therefore combines experimental flight logs with source code for the perception, navigation, reinforcement-learning control, and low-level flight-control components used in the research.},
note = {Software},
keywords = {},
pubstate = {published},
tppubtype = {data}
}
Data underlying the publication: MonoRACE: Winning Champion-Level Drone Racing with Robust Monocular AI This dataset supports the publication “MonoRACE: Winning Champion-Level Drone Racing with Robust Monocular AI” . The research investigates robust autonomous high-speed drone racing using a single forward-facing monocular camera and an onboard IMU, with the goal of enabling reliable gate detection, state estimation, and control during aggressive flight. The dataset contains flight-log data from eight autonomous drone racing flights, providing experimental data collected during the development and evaluation of the MonoRACE system. The flight logs contain onboard sensor and flight-control data used to analyse the behaviour and robustness of the system during racing. In addition to the flight data, the dataset includes the software components used in the experiments: the MonoRaceGate implementation for monocular gate-based navigation, the INDIFlight flight-control software, and the Optimal Quad Control reinforcement-learning controller developed for the A2RL 2025 autonomous drone racing competition. These components provide the research and implementation context needed to interpret and potentially reuse the data. The dataset therefore combines experimental flight logs with source code for the perception, navigation, reinforcement-learning control, and low-level flight-control components used in the research. |
Guido de Croon; Dequan Ou; Christophe De Wagter; Jesse Hagenaars Bee-Nav: Data supporting the publication "Efficient robot navigation inspired by honeybee learning flights" (data) 2026, (Dataset). @data{10.4121/a0217a20-0443-48b2-8a04-9609ac267029,
title = {Bee-Nav: Data supporting the publication "Efficient robot navigation inspired by honeybee learning flights"},
author = { Guido de Croon and Dequan Ou and Christophe De Wagter and Jesse Hagenaars},
url = {https://doi.org/10.4121/a0217a20-0443-48b2-8a04-9609ac267029},
doi = {10.4121/a0217a20-0443-48b2-8a04-9609ac267029},
year = {2026},
date = {2026-01-01},
publisher = {4TU.ResearchData},
abstract = {Robotic experimental data for the paper: "Efficient robot navigation inspired by honeybee learning flights", by D. Ou et al. It contains both flight logs and the omni-directional images that were captured during learning and navigation flights.},
note = {Dataset},
keywords = {},
pubstate = {published},
tppubtype = {data}
}
Robotic experimental data for the paper: "Efficient robot navigation inspired by honeybee learning flights", by D. Ou et al. It contains both flight logs and the omni-directional images that were captured during learning and navigation flights. |
Tomaso De Ponti; Simon Hafner; Ewoud Smeur Test Data of Actuator nonlinear dynamic inversion for the variable skew quad plane with heterogeneous motor dynamics (data) 2026, (Dataset). @data{10.4121/0e146396-715f-43fa-b571-89feb2906d06,
title = {Test Data of Actuator nonlinear dynamic inversion for the variable skew quad plane with heterogeneous motor dynamics},
author = { Tomaso De Ponti and Simon Hafner and Ewoud Smeur},
url = {https://doi.org/10.4121/0e146396-715f-43fa-b571-89feb2906d06},
doi = {10.4121/0e146396-715f-43fa-b571-89feb2906d06},
year = {2026},
date = {2026-01-01},
publisher = {4TU.ResearchData},
abstract = {This dataset accompanies the paper titled "Actuator nonlinear dynamic inversion for the variable skew quad plane with heterogeneous motor dynamics". It includes flight test data, simulation data, post-processing scripts, and derivations. The ANDI controller is demonstrated to be superior in controlling systems with heterogeneus actuator dynamics. The flight test are performed on the Variable Skew Quad Plane.},
note = {Dataset},
keywords = {},
pubstate = {published},
tppubtype = {data}
}
This dataset accompanies the paper titled "Actuator nonlinear dynamic inversion for the variable skew quad plane with heterogeneous motor dynamics". It includes flight test data, simulation data, post-processing scripts, and derivations. The ANDI controller is demonstrated to be superior in controlling systems with heterogeneus actuator dynamics. The flight test are performed on the Variable Skew Quad Plane. |
Jane Pauline Ramirez; Salua Hamaza Aerial Terrestrial Multimodal Robots Database (data) 2026, (Dataset). @data{10.4121/b23850c5-1eef-4a13-955e-b6909a1e93ac,
title = {Aerial Terrestrial Multimodal Robots Database},
author = { Jane Pauline Ramirez and Salua Hamaza},
url = {https://doi.org/10.4121/b23850c5-1eef-4a13-955e-b6909a1e93ac},
doi = {10.4121/b23850c5-1eef-4a13-955e-b6909a1e93ac},
year = {2026},
date = {2026-01-01},
publisher = {4TU.ResearchData},
abstract = {Database of reviewed literature for the review paper entitled Multi-modal Locomotion: Next Generation Aerial-terrestrial Mobile Robotics The database contains literature references of drone prototypes distinguishing among three primary design approaches: 1) additive design: when the morphology of the robot remains unchanged while varying modalities; 2) adaptive design: when robots are capable of altering their morphology (or morph) to traverse different domains effectively; and 3) multi-vehicle design: involves the use of multiple vehicles working together to achieve multimodal functionality. Within each category, subcategories have been defined according to their forms, structures and mechanisms of movement. The references go from years 2000 to 2023 adding up a total of 64 prototypes. See the associated peer reviewed publication for further analysis on the classification, and the advantages and current limitations of each (sub)category.},
note = {Dataset},
keywords = {},
pubstate = {published},
tppubtype = {data}
}
Database of reviewed literature for the review paper entitled Multi-modal Locomotion: Next Generation Aerial-terrestrial Mobile Robotics The database contains literature references of drone prototypes distinguishing among three primary design approaches: 1) additive design: when the morphology of the robot remains unchanged while varying modalities; 2) adaptive design: when robots are capable of altering their morphology (or morph) to traverse different domains effectively; and 3) multi-vehicle design: involves the use of multiple vehicles working together to achieve multimodal functionality. Within each category, subcategories have been defined according to their forms, structures and mechanisms of movement. The references go from years 2000 to 2023 adding up a total of 64 prototypes. See the associated peer reviewed publication for further analysis on the classification, and the advantages and current limitations of each (sub)category. |
Sunyi Wang; Martijn den Hoed; Salua Hamaza Data supporting the publication: Delfly Flex: A Flapping Wing Micro Air Vehicle with a Bio-Inspired Unibody Composed of Compliant Joints (data) 2026, (Dataset). @data{10.4121/eee88ebe-739b-4bff-bf4a-4dd248d91eeb,
title = {Data supporting the publication: Delfly Flex: A Flapping Wing Micro Air Vehicle with a Bio-Inspired Unibody Composed of Compliant Joints},
author = { Sunyi Wang and Martijn den Hoed and Salua Hamaza},
url = {https://doi.org/10.4121/eee88ebe-739b-4bff-bf4a-4dd248d91eeb},
doi = {10.4121/eee88ebe-739b-4bff-bf4a-4dd248d91eeb},
year = {2026},
date = {2026-01-01},
publisher = {4TU.ResearchData},
abstract = {This dataset includes all experimental data that support the figures of the manuscript, in particular the force balance measurements with the ATI Nano 17 (Titanium) system, and in-flight onboard logging of the designed micro air vehicle. For data collection and methodology, please refer to the publication. Supplementary files are not included here, since they can be directly downloaded with the published manuscript.},
note = {Dataset},
keywords = {},
pubstate = {published},
tppubtype = {data}
}
This dataset includes all experimental data that support the figures of the manuscript, in particular the force balance measurements with the ATI Nano 17 (Titanium) system, and in-flight onboard logging of the designed micro air vehicle. For data collection and methodology, please refer to the publication. Supplementary files are not included here, since they can be directly downloaded with the published manuscript. |
Lohithsai Yadala Chanchu; Ruben Zuidgeest; D.M. (Daphne) Stam; Guido de Croon Data underlying publication: Robust Heading Estimation from Polarization Images by Deep Neural Networks (data) 2026, (Dataset). @data{10.4121/eb6efac3-8084-4c10-bb0d-4b3af068ab19,
title = {Data underlying publication: Robust Heading Estimation from Polarization Images by Deep Neural Networks},
author = { Lohithsai Yadala Chanchu and Ruben Zuidgeest and D.M. (Daphne) Stam and Guido de Croon},
url = {https://doi.org/10.4121/eb6efac3-8084-4c10-bb0d-4b3af068ab19},
doi = {10.4121/eb6efac3-8084-4c10-bb0d-4b3af068ab19},
year = {2026},
date = {2026-01-01},
publisher = {4TU.ResearchData},
abstract = {Dataset containing the sky polarization images. These images are captured from the rooftop of the Aerospace Engineering faculty at TU Delft over the course of 4 months. There are 2618 real-life images, and 2500 simulated images. The labels contain the azimuth angle of the sun measured CCW with respects to the positive x-axis. The folder contains the following files:cloudiness.npylabels.npymaps.npysim_cloud_labels.npysim_cloud_maps.npy},
note = {Dataset},
keywords = {},
pubstate = {published},
tppubtype = {data}
}
Dataset containing the sky polarization images. These images are captured from the rooftop of the Aerospace Engineering faculty at TU Delft over the course of 4 months. There are 2618 real-life images, and 2500 simulated images. The labels contain the azimuth angle of the sun measured CCW with respects to the positive x-axis. The folder contains the following files:cloudiness.npylabels.npymaps.npysim_cloud_labels.npysim_cloud_maps.npy |
Book Chapters
|
Guoling Yang; Marija Popovic; Ronald Clark; Mirko Kovac; Basaran Bahadir Kocer Synthetic Data Augmented Leaflet-Level Ash Dieback Detection (Book Chapter) In: Studies in Computational Intelligence, pp. 203–224, Springer Nature, 2026. @inbook{98dad7c0e65e4eea9be84061119aa258,
title = {Synthetic Data Augmented Leaflet-Level Ash Dieback Detection},
author = { Guoling Yang and Marija Popovic and Ronald Clark and Mirko Kovac and Basaran Bahadir Kocer},
url = {https://research.tudelft.nl/en/publications/synthetic-data-augmented-leaflet-level-ash-dieback-detection/},
doi = {10.1007/978-3-032-15812-3_8},
year = {2026},
date = {2026-01-01},
booktitle = {Studies in Computational Intelligence},
pages = {203–224},
publisher = {Springer Nature},
series = {Studies in Computational Intelligence},
keywords = {},
pubstate = {published},
tppubtype = {inbook}
}
|
Proceedings Articles
|
Baihui Chen; Tomas Sinnige; Ewoud Smeur Efficient Modeling of a Tilted Propeller–Wing System over a Wide Angle-of-Attack Range Based on Wind Tunnel and CFD Data (Proceedings Article) In: AIAA AVIATION 2026 Forum, 2026, (AIAA AVIATION 2026 Forum ; Conference date: 08-06-2026 Through 12-06-2026). @inproceedings{675a8f70f3fe4cdf8c86042be53c7bc3,
title = {Efficient Modeling of a Tilted Propeller–Wing System over a Wide Angle-of-Attack Range Based on Wind Tunnel and CFD Data},
author = { Baihui Chen and Tomas Sinnige and Ewoud Smeur},
url = {https://research.tudelft.nl/en/publications/efficient-modeling-of-a-tilted-propellerwing-system-over-a-wide-a/},
doi = {10.2514/6.2026-4138},
year = {2026},
date = {2026-01-01},
booktitle = {AIAA AVIATION 2026 Forum},
note = {AIAA AVIATION 2026 Forum ; Conference date: 08-06-2026 Through 12-06-2026},
keywords = {},
pubstate = {published},
tppubtype = {inproceedings}
}
|
Justin P.G. Dubois; Evangelos Ntouros; Ewoud J.J. Smeur Full Actuator Nonlinear Dynamic Inversion for Enhanced Hybrid UAV Control (Proceedings Article) In: 2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026, pp. 625–632, IEEE, United States, 2026, (2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026 ; Conference date: 15-06-2026 Through 18-06-2026). @inproceedings{b4ab30582710455082edccc6d8086610,
title = {Full Actuator Nonlinear Dynamic Inversion for Enhanced Hybrid UAV Control},
author = { Justin P.G. Dubois and Evangelos Ntouros and Ewoud J.J. Smeur},
url = {https://research.tudelft.nl/en/publications/full-actuator-nonlinear-dynamic-inversion-for-enhanced-hybrid-uav/},
doi = {10.1109/ICUAS69441.2026.11598601},
year = {2026},
date = {2026-01-01},
booktitle = {2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026},
pages = {625–632},
publisher = {IEEE},
address = {United States},
series = {2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026},
note = {2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026 ; Conference date: 15-06-2026 Through 18-06-2026},
keywords = {},
pubstate = {published},
tppubtype = {inproceedings}
}
|
Tom Aantjes; Till Blaha; Spilios Theodoulis; Ewoud Smeur Robust H∞ Controller Design for INDI-Controlled Quadrotor Using Online Parameter Identification (Proceedings Article) In: 2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026, pp. 561–568, IEEE, United States, 2026, (2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026 ; Conference date: 15-06-2026 Through 18-06-2026). @inproceedings{1262199aa0e14d18aac314d92b608c07,
title = {Robust H∞ Controller Design for INDI-Controlled Quadrotor Using Online Parameter Identification},
author = { Tom Aantjes and Till Blaha and Spilios Theodoulis and Ewoud Smeur},
url = {https://research.tudelft.nl/en/publications/robust-hsubsub-controller-design-for-indi-controlled-quadrotor-us/},
doi = {10.1109/ICUAS69441.2026.11598602},
year = {2026},
date = {2026-01-01},
booktitle = {2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026},
pages = {561–568},
publisher = {IEEE},
address = {United States},
series = {2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026},
note = {2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026 ; Conference date: 15-06-2026 Through 18-06-2026},
keywords = {},
pubstate = {published},
tppubtype = {inproceedings}
}
|
Tomaso De Ponti; Ewoud Smeur; Bart Remes Incremental Nonlinear Fault-Tolerant Control of the Variable Skew Quad Plane with Loss of Two Opposing Rotors (Proceedings Article) In: 2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026, pp. 1428–1435, IEEE, United States, 2026, (2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026 ; Conference date: 15-06-2026 Through 18-06-2026). @inproceedings{55079c8897e44115ac80cc8d54102b31,
title = {Incremental Nonlinear Fault-Tolerant Control of the Variable Skew Quad Plane with Loss of Two Opposing Rotors},
author = { Tomaso De Ponti and Ewoud Smeur and Bart Remes},
url = {https://research.tudelft.nl/en/publications/incremental-nonlinear-fault-tolerant-control-of-the-variable-skew/},
doi = {10.1109/ICUAS69441.2026.11598575},
year = {2026},
date = {2026-01-01},
booktitle = {2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026},
pages = {1428–1435},
publisher = {IEEE},
address = {United States},
series = {2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026},
note = {2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026 ; Conference date: 15-06-2026 Through 18-06-2026},
keywords = {},
pubstate = {published},
tppubtype = {inproceedings}
}
|
Mikolaj Heliński; Spilios Theodoulis; Mahmoud Hamandi; Abdullah Mohamed Ali; Anthony Tzes; Marija Popović Local Path Planning and Obstacle Avoidance for an Omnicopter Platform (Proceedings Article) In: 2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026, pp. 317–324, IEEE, United States, 2026, (2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026 ; Conference date: 15-06-2026 Through 18-06-2026). @inproceedings{835d88cf47c14c77b5e74a8ebbac7659,
title = {Local Path Planning and Obstacle Avoidance for an Omnicopter Platform},
author = { Mikolaj Heli{ń}ski and Spilios Theodoulis and Mahmoud Hamandi and Abdullah Mohamed Ali and Anthony Tzes and Marija Popovi{ć}},
url = {https://research.tudelft.nl/en/publications/local-path-planning-and-obstacle-avoidance-for-an-omnicopter-plat/},
doi = {10.1109/ICUAS69441.2026.11598657},
year = {2026},
date = {2026-01-01},
booktitle = {2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026},
pages = {317–324},
publisher = {IEEE},
address = {United States},
series = {2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026},
note = {2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026 ; Conference date: 15-06-2026 Through 18-06-2026},
keywords = {},
pubstate = {published},
tppubtype = {inproceedings}
}
|
Jacob Elskamp; Moji Shi; Leonard Bauersfeld; Davide Scaramuzza; Marija Popović EAAE: Energy-Aware Autonomous Exploration for UAVs in Unknown 3D Environments (Proceedings Article) In: 2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026, pp. 886–893, IEEE, United States, 2026, (2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026 ; Conference date: 15-06-2026 Through 18-06-2026). @inproceedings{5858ef803b3c474fab2d0e35d930334c,
title = {EAAE: Energy-Aware Autonomous Exploration for UAVs in Unknown 3D Environments},
author = { Jacob Elskamp and Moji Shi and Leonard Bauersfeld and Davide Scaramuzza and Marija Popovi{ć}},
url = {https://research.tudelft.nl/en/publications/eaae-energy-aware-autonomous-exploration-for-uavs-in-unknown-3d-e/},
doi = {10.1109/ICUAS69441.2026.11598616},
year = {2026},
date = {2026-01-01},
booktitle = {2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026},
pages = {886–893},
publisher = {IEEE},
address = {United States},
series = {2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026},
note = {2026 International Conference on Unmanned Aircraft Systems, ICUAS 2026 ; Conference date: 15-06-2026 Through 18-06-2026},
keywords = {},
pubstate = {published},
tppubtype = {inproceedings}
}
|
Masters Theses
|
Q. Missinne Towards Decoding Motion: How Depth and Optical Flow Inform Neural Ego-Motion Estimation (Masters Thesis) TU Delft Mechanical Engineering, 2026, (Kooij, J.F.P. (mentor); de Croon, G.C.H.E. (mentor); Zaffar, M. (mentor); Bahnam, S.A. (mentor); Delft University of Technology (degree granting institution); graduation 28-01-2026). @mastersthesis{uuid:ecd458f0-6a6b-4295-a998-619bceaeb00c,
title = {Towards Decoding Motion: How Depth and Optical Flow Inform Neural Ego-Motion Estimation},
author = { Q. Missinne},
url = {https://resolver.tudelft.nl/uuid:ecd458f0-6a6b-4295-a998-619bceaeb00c},
year = {2026},
date = {2026-01-01},
school = {TU Delft Mechanical Engineering},
abstract = {Deep neural networks are increasingly used for ego-motion estimation. Often, in self-supervised ego-motion networks, it is decoded from a depth network and until now has not been decoded from an optical flow network. This is surprising given the tight relationship between optical flow and ego-motion. While both representations are widely used in learning-based approaches, the extent to which their latent space encodes motion information remains poorly understood. This paper presents a controlled analysis of how well depth-based and optical flow-based neural networks encode ego-motion. Using supervised depth, flow and pose networks trained on TartanAirV2, we probe motion information by attaching identical minimal pose decoders to frozen encoders. Representational space analysis through Centered Kernel Analysis (CKA) and feature space analysis through Principal Component Analysis (PCA) are used to examine how motion information is structured across network hierarchies. This work shows that optical flow representations encode ego-motion information more explicitly, in a lower dimensional, linearly accessible structure as opposed to depth representations, which exhibit weak alignment with pose. These findings suggest that in a self-supervised setting, ego-motion estimation can best be decoded from an optical flow network as opposed to a depth network.},
note = {Kooij, J.F.P. (mentor); de Croon, G.C.H.E. (mentor); Zaffar, M. (mentor); Bahnam, S.A. (mentor); Delft University of Technology (degree granting institution); graduation 28-01-2026},
keywords = {},
pubstate = {published},
tppubtype = {mastersthesis}
}
Deep neural networks are increasingly used for ego-motion estimation. Often, in self-supervised ego-motion networks, it is decoded from a depth network and until now has not been decoded from an optical flow network. This is surprising given the tight relationship between optical flow and ego-motion. While both representations are widely used in learning-based approaches, the extent to which their latent space encodes motion information remains poorly understood. This paper presents a controlled analysis of how well depth-based and optical flow-based neural networks encode ego-motion. Using supervised depth, flow and pose networks trained on TartanAirV2, we probe motion information by attaching identical minimal pose decoders to frozen encoders. Representational space analysis through Centered Kernel Analysis (CKA) and feature space analysis through Principal Component Analysis (PCA) are used to examine how motion information is structured across network hierarchies. This work shows that optical flow representations encode ego-motion information more explicitly, in a lower dimensional, linearly accessible structure as opposed to depth representations, which exhibit weak alignment with pose. These findings suggest that in a self-supervised setting, ego-motion estimation can best be decoded from an optical flow network as opposed to a depth network. |
T.L. van der Wal Active Exploration for VLM-Guided Anomaly Inspection using a UAV (Masters Thesis) TU Delft Aerospace Engineering, 2026, (Smeur, E.J.J. (graduation committee member); Popovic, M. (mentor); Blum, Hermann (mentor); Della Santina, C. (graduation committee member); Delft University of Technology (degree granting institution); graduation 19-03-2026). @mastersthesis{uuid:cb78a143-7cf2-4593-9afa-ca2ca900b1b0,
title = {Active Exploration for VLM-Guided Anomaly Inspection using a UAV},
author = { T.L. van der Wal},
url = {https://resolver.tudelft.nl/uuid:cb78a143-7cf2-4593-9afa-ca2ca900b1b0},
year = {2026},
date = {2026-01-01},
school = {TU Delft Aerospace Engineering},
abstract = {Autonomous exploration by drones in unknown environments has traditionally focused on maximizing spatial coverage without semantic understanding. This thesis presents a framework that integrates vision-language models (VLMs) with adaptive path planning to enable anomaly-aware exploration and inspection. The system employs a three-phase approach: frontier-based exploration, continuous VLM-based anomaly detection, and inspection of detected anomalies. Comparative experiments demonstrated that YOLO+CLIP with negative embeddings achieved the highest F1 score of 0.7218 on the SegmentifyMeIfYouCan benchmark. Experiments showed that dedicated inspection yielded improvements over solely exploration observations. However, system-level evaluation across nine experimental runs revealed that the inspection phase took up most of the mission time (85.9% average), with varying anomaly detection consistency across anomaly instances. False positive analysis identified VLM error as the primary limitation (52% of false positives), followed by simulation artifacts (37%) and semantic ambiguity (11%). The framework successfully demonstrated the feasibility of coupling VLM-based anomaly detection with adaptive planning, though precision limitations and large inspection inefficiencies show opportunities for future work.},
note = {Smeur, E.J.J. (graduation committee member); Popovic, M. (mentor); Blum, Hermann (mentor); Della Santina, C. (graduation committee member); Delft University of Technology (degree granting institution); graduation 19-03-2026},
keywords = {},
pubstate = {published},
tppubtype = {mastersthesis}
}
Autonomous exploration by drones in unknown environments has traditionally focused on maximizing spatial coverage without semantic understanding. This thesis presents a framework that integrates vision-language models (VLMs) with adaptive path planning to enable anomaly-aware exploration and inspection. The system employs a three-phase approach: frontier-based exploration, continuous VLM-based anomaly detection, and inspection of detected anomalies. Comparative experiments demonstrated that YOLO+CLIP with negative embeddings achieved the highest F1 score of 0.7218 on the SegmentifyMeIfYouCan benchmark. Experiments showed that dedicated inspection yielded improvements over solely exploration observations. However, system-level evaluation across nine experimental runs revealed that the inspection phase took up most of the mission time (85.9% average), with varying anomaly detection consistency across anomaly instances. False positive analysis identified VLM error as the primary limitation (52% of false positives), followed by simulation artifacts (37%) and semantic ambiguity (11%). The framework successfully demonstrated the feasibility of coupling VLM-based anomaly detection with adaptive planning, though precision limitations and large inspection inefficiencies show opportunities for future work. |
D.F. van Hamersveld Autonomous fixed-wing interception using reinforcement learning (Masters Thesis) TU Delft Aerospace Engineering, 2026, (Smeur, E.J.J. (mentor); Kriachko, I.T. (mentor); Delft University of Technology (degree granting institution); graduation 04-09-2026). @mastersthesis{uuid:bd77521e-91c5-46b4-8349-c847ce8bac78,
title = {Autonomous fixed-wing interception using reinforcement learning},
author = { D.F. van Hamersveld},
url = {https://resolver.tudelft.nl/uuid:bd77521e-91c5-46b4-8349-c847ce8bac78},
year = {2026},
date = {2026-01-01},
school = {TU Delft Aerospace Engineering},
abstract = {Medium altitude, long endurance unmanned aerial systems such as Shahed-type strike drones are an unanswered threat in modern conflicts. Conventional air defense systems are too expensive to provide a feasible large-scale solution. Quadcopter interceptors are a cheap, battle-proven alternative, but their extremely limited flight time restricts them to low altitude targets at short range, whereas fixed-wing platforms have the endurance to reach higher altitude targets from longer distances. However, such interceptors are still operated manually. Recent developments in learning-based controllers show potential for automation. In this work, a fixed-wing interceptor is presented that is controlled by a neural network that maps filtered monocular vision observations directly to actuator commands. The policy was trained in a custom Python environment using reinforcement learning and proximal policy optimization. The policy was then deployed on a fixed-wing platform and tested in real interception scenarios. As a baseline, two classical guidance controllers were also developed and tested in simulation. The policy is able to intercept targets both in simulation and in real flight. In simulation, the policy outperforms the classical controllers under most conditions. The interceptor was ultimately successfully validated in real flight by intercepting maneuvering fixed-wing targets. This novel system shows the potential of artificial intelligence for autonomous control of fixed-wing interceptor drones.},
note = {Smeur, E.J.J. (mentor); Kriachko, I.T. (mentor); Delft University of Technology (degree granting institution); graduation 04-09-2026},
keywords = {},
pubstate = {published},
tppubtype = {mastersthesis}
}
Medium altitude, long endurance unmanned aerial systems such as Shahed-type strike drones are an unanswered threat in modern conflicts. Conventional air defense systems are too expensive to provide a feasible large-scale solution. Quadcopter interceptors are a cheap, battle-proven alternative, but their extremely limited flight time restricts them to low altitude targets at short range, whereas fixed-wing platforms have the endurance to reach higher altitude targets from longer distances. However, such interceptors are still operated manually. Recent developments in learning-based controllers show potential for automation. In this work, a fixed-wing interceptor is presented that is controlled by a neural network that maps filtered monocular vision observations directly to actuator commands. The policy was trained in a custom Python environment using reinforcement learning and proximal policy optimization. The policy was then deployed on a fixed-wing platform and tested in real interception scenarios. As a baseline, two classical guidance controllers were also developed and tested in simulation. The policy is able to intercept targets both in simulation and in real flight. In simulation, the policy outperforms the classical controllers under most conditions. The interceptor was ultimately successfully validated in real flight by intercepting maneuvering fixed-wing targets. This novel system shows the potential of artificial intelligence for autonomous control of fixed-wing interceptor drones. |
M.K. Heliński Local Path Planning and Obstacle Avoidance for an Omnicopter: A 6D-DWA Algorithm for Real-time Omnidirectional Navigation (Masters Thesis) TU Delft Aerospace Engineering, 2026, (Pavel, M.D. (graduation committee member); de Wagter, C. (graduation committee member); Popovic, M. (mentor); Theodoulis, Spilios (mentor); Delft University of Technology (degree granting institution); graduation 05-03-2026). @mastersthesis{uuid:a4248cc6-a95a-481a-9065-965987da8d83,
title = {Local Path Planning and Obstacle Avoidance for an Omnicopter: A 6D-DWA Algorithm for Real-time Omnidirectional Navigation},
author = { M.K. Heliński},
url = {https://resolver.tudelft.nl/uuid:a4248cc6-a95a-481a-9065-965987da8d83},
year = {2026},
date = {2026-01-01},
school = {TU Delft Aerospace Engineering},
abstract = {As omnidirectional UAVs become increasingly prevalent, computationally efficient path planning algorithms are required to facilitate their autonomous traversal of dynamic environments. This thesis presents a real-time local path planning algorithm for an omnicopter, adapted from the Dynamic Window Approach into a 6D-DWA implementation. To ensure computational efficiency, the local path planner incorporates environment voxelisation, a 10-sphere omnicopter structure approximation, and adaptive velocity sampling. The avoidance of dynamic obstacles, detected via depth camera, is facilitated through context-aware 6D-DWA weight adjustments and a separate integrated fast-evasion strategy. Simulation testing in Gazebo demonstrates that the 6D-DWA is a feasible local planning solution, consistently performing below the 0.2 s real-time threshold. Future research into algorithm hybridisation may further mitigate the system's limited foresight and enhance the replanning capabilities.},
note = {Pavel, M.D. (graduation committee member); de Wagter, C. (graduation committee member); Popovic, M. (mentor); Theodoulis, Spilios (mentor); Delft University of Technology (degree granting institution); graduation 05-03-2026},
keywords = {},
pubstate = {published},
tppubtype = {mastersthesis}
}
As omnidirectional UAVs become increasingly prevalent, computationally efficient path planning algorithms are required to facilitate their autonomous traversal of dynamic environments. This thesis presents a real-time local path planning algorithm for an omnicopter, adapted from the Dynamic Window Approach into a 6D-DWA implementation. To ensure computational efficiency, the local path planner incorporates environment voxelisation, a 10-sphere omnicopter structure approximation, and adaptive velocity sampling. The avoidance of dynamic obstacles, detected via depth camera, is facilitated through context-aware 6D-DWA weight adjustments and a separate integrated fast-evasion strategy. Simulation testing in Gazebo demonstrates that the 6D-DWA is a feasible local planning solution, consistently performing below the 0.2 s real-time threshold. Future research into algorithm hybridisation may further mitigate the system's limited foresight and enhance the replanning capabilities. |
T.J. van der Weij Tactile Object Classification Using a Biomimetic Whisker Sensor Array and Spiking Neural Networks (Masters Thesis) TU Delft Mechanical Engineering, 2026, (Hamaza, S. (mentor); Tömen, N. (mentor); Ferranti, L. (mentor); Delft University of Technology (degree granting institution); graduation 22-04-2026). @mastersthesis{uuid:995273bf-d7b7-403d-90ff-546634a673d8,
title = {Tactile Object Classification Using a Biomimetic Whisker Sensor Array and Spiking Neural Networks},
author = { T.J. van der Weij},
url = {https://resolver.tudelft.nl/uuid:995273bf-d7b7-403d-90ff-546634a673d8},
year = {2026},
date = {2026-01-01},
school = {TU Delft Mechanical Engineering},
abstract = {Robots operating in confined or visually degraded environments require sensing modalities that provide reliable close-range feedback. Biologically inspired whisker sensors address this need: passive and lightweight, they encode contact geometry through time-varying signals. Spiking neural networks (SNNs) form a natural processing counterpart — also biologically motivated, they perform sparse, event-driven computation that mirrors neural processing and promises energy-efficient inference on neuromorphic hardware. Despite this complementary fit, training data for neuromorphic tactile sensing remains scarce, and fully spiking architectures have not been evaluated on whisker-based classification, leaving their practical viability an open question. To address this gap, we collected two tactile datasets using a 10-whisker MEMS-based sensor array swept across three object geometries under varying contact conditions. A compact fully spiking network with 901 parameters achieved 100% test accuracy, outperforming larger spiking architectures; classification was reliable from as few as 20 timesteps of contact, and raw pressure signals alone were sufficient. Generalization experiments showed that sweep speed had minimal effect on performance, while indentation depth and sweep direction introduced larger domain shifts. Compared to a structurally equivalent non-spiking baseline, the spiking model matched classification accuracy with an estimated 9.5% reduction in overall inference energy under analog input and a potential 95% reduction under spike-encoded input. These results demonstrate the feasibility of a fully bio-inspired pipeline — from biomimetic whisker sensing to spiking neural inference — for tactile object classification.},
note = {Hamaza, S. (mentor); Tömen, N. (mentor); Ferranti, L. (mentor); Delft University of Technology (degree granting institution); graduation 22-04-2026},
keywords = {},
pubstate = {published},
tppubtype = {mastersthesis}
}
Robots operating in confined or visually degraded environments require sensing modalities that provide reliable close-range feedback. Biologically inspired whisker sensors address this need: passive and lightweight, they encode contact geometry through time-varying signals. Spiking neural networks (SNNs) form a natural processing counterpart — also biologically motivated, they perform sparse, event-driven computation that mirrors neural processing and promises energy-efficient inference on neuromorphic hardware. Despite this complementary fit, training data for neuromorphic tactile sensing remains scarce, and fully spiking architectures have not been evaluated on whisker-based classification, leaving their practical viability an open question. To address this gap, we collected two tactile datasets using a 10-whisker MEMS-based sensor array swept across three object geometries under varying contact conditions. A compact fully spiking network with 901 parameters achieved 100% test accuracy, outperforming larger spiking architectures; classification was reliable from as few as 20 timesteps of contact, and raw pressure signals alone were sufficient. Generalization experiments showed that sweep speed had minimal effect on performance, while indentation depth and sweep direction introduced larger domain shifts. Compared to a structurally equivalent non-spiking baseline, the spiking model matched classification accuracy with an estimated 9.5% reduction in overall inference energy under analog input and a potential 95% reduction under spike-encoded input. These results demonstrate the feasibility of a fully bio-inspired pipeline — from biomimetic whisker sensing to spiking neural inference — for tactile object classification. |
N.I. Grens Safety Cages for Reliable Machine Learning: A framework for exoplanet spectroscopy in the Ariel mission, extended with error-aware model specialisation (Masters Thesis) TU Delft Aerospace Engineering, 2026, (de Croon, G.C.H.E. (mentor); F. Simões, Luís (mentor); Cazaux, S.M. (graduation committee member); Meijer, Vincent (graduation committee member); Delft University of Technology (degree granting institution); graduation 30-06-2026). @mastersthesis{uuid:7e0c7f9d-f418-486a-93d3-9dadf33a6614,
title = {Safety Cages for Reliable Machine Learning: A framework for exoplanet spectroscopy in the Ariel mission, extended with error-aware model specialisation},
author = { N.I. Grens},
url = {https://resolver.tudelft.nl/uuid:7e0c7f9d-f418-486a-93d3-9dadf33a6614},
year = {2026},
date = {2026-01-01},
school = {TU Delft Aerospace Engineering},
abstract = {Ensuring the reliability of machine learning models in safety-critical space missions remains a significant challenge, especially when ground-truth data is unavailable for real-time validation. While machine learning can augment pipelines by extracting transmission spectra from complex light curves, vulnerabilities to instrument anomalies and domain shifts introduce risks. This study evaluates a modular safety cage architecture operating as a parallel monitoring layer to assess prediction validity without modifying the underlying estimator. By monitoring runtime indicators, including uncertainty quantification, out-of-domain detection, and influence functions, the framework constrains the operational domain to a verified region. The results demonstrate that model failure is multifaceted, requiring indicator fusion strategies, and that applying safety-driven rejection allows for a small reduction in data coverage leading to a significant reduction in prediction error. In addition, the framework is extended with an error-aware model specialisation pipeline that partitions the parameter space to deploy specialised local experts.},
note = {de Croon, G.C.H.E. (mentor); F. Simões, Luís (mentor); Cazaux, S.M. (graduation committee member); Meijer, Vincent (graduation committee member); Delft University of Technology (degree granting institution); graduation 30-06-2026},
keywords = {},
pubstate = {published},
tppubtype = {mastersthesis}
}
Ensuring the reliability of machine learning models in safety-critical space missions remains a significant challenge, especially when ground-truth data is unavailable for real-time validation. While machine learning can augment pipelines by extracting transmission spectra from complex light curves, vulnerabilities to instrument anomalies and domain shifts introduce risks. This study evaluates a modular safety cage architecture operating as a parallel monitoring layer to assess prediction validity without modifying the underlying estimator. By monitoring runtime indicators, including uncertainty quantification, out-of-domain detection, and influence functions, the framework constrains the operational domain to a verified region. The results demonstrate that model failure is multifaceted, requiring indicator fusion strategies, and that applying safety-driven rejection allows for a small reduction in data coverage leading to a significant reduction in prediction error. In addition, the framework is extended with an error-aware model specialisation pipeline that partitions the parameter space to deploy specialised local experts. |
D.J. Jagt Anomaly Detection for Cluttered, Multi-Instance E-grocery Stock Containers (Masters Thesis) TU Delft Aerospace Engineering, 2026, (Popovic, M. (mentor); de Wagter, C. (graduation committee member); van Gemert, J.C. (graduation committee member); Schultinga, Kevin (mentor); Delft University of Technology (degree granting institution); graduation 28-05-2026). @mastersthesis{uuid:5e8691b1-cf90-4735-90f2-9fef88af0b67,
title = {Anomaly Detection for Cluttered, Multi-Instance E-grocery Stock Containers},
author = { D.J. Jagt},
url = {https://resolver.tudelft.nl/uuid:5e8691b1-cf90-4735-90f2-9fef88af0b67},
year = {2026},
date = {2026-01-01},
school = {TU Delft Aerospace Engineering},
abstract = {Automated quality inspection of cluttered, multi-instance e-grocery stock containers is challenging because packaging clutter, product boundaries, container wear, and loose debris generate local anomaly responses that do not correspond to genuine quality issues. This thesis develops a modular reference-based inspection pipeline in which normality for each stock keeping unit (SKU) is modelled through automatically constructed and sampled reference sets. Query images are scored by patch-level nearest-neighbour matching of DINOv2 features against a reference memory bank, following the AnomalyDINO paradigm. Edge downweighting and crop-level debris filtering suppress boundary- and debris-driven false positives, while an optical character recognition (OCR)-based branch additionally addresses visually subtle wrong-SKU substitutions. Evaluated on 2,996 normal and 1,657 issue images across 20 SKU classes and five issue families, the full pipeline increases precision from 0.511 to 0.834 and reduces false positives from 1,414 to 201 relative to the core detector (F1-score: 0.705). This improvement comes at a recall cost, with recall decreasing from 0.893 to 0.610. The full pipeline achieves a 99th-percentile end-to-end latency of 1.4 s, within the 10 s operational constraint. The results demonstrate that robust inspection in this setting requires treating false-positive mitigation as a core system requirement rather than relying on raw anomaly sensitivity alone.},
note = {Popovic, M. (mentor); de Wagter, C. (graduation committee member); van Gemert, J.C. (graduation committee member); Schultinga, Kevin (mentor); Delft University of Technology (degree granting institution); graduation 28-05-2026},
keywords = {},
pubstate = {published},
tppubtype = {mastersthesis}
}
Automated quality inspection of cluttered, multi-instance e-grocery stock containers is challenging because packaging clutter, product boundaries, container wear, and loose debris generate local anomaly responses that do not correspond to genuine quality issues. This thesis develops a modular reference-based inspection pipeline in which normality for each stock keeping unit (SKU) is modelled through automatically constructed and sampled reference sets. Query images are scored by patch-level nearest-neighbour matching of DINOv2 features against a reference memory bank, following the AnomalyDINO paradigm. Edge downweighting and crop-level debris filtering suppress boundary- and debris-driven false positives, while an optical character recognition (OCR)-based branch additionally addresses visually subtle wrong-SKU substitutions. Evaluated on 2,996 normal and 1,657 issue images across 20 SKU classes and five issue families, the full pipeline increases precision from 0.511 to 0.834 and reduces false positives from 1,414 to 201 relative to the core detector (F1-score: 0.705). This improvement comes at a recall cost, with recall decreasing from 0.893 to 0.610. The full pipeline achieves a 99th-percentile end-to-end latency of 1.4 s, within the 10 s operational constraint. The results demonstrate that robust inspection in this setting requires treating false-positive mitigation as a core system requirement rather than relying on raw anomaly sensitivity alone. |
J.P.G. Dubois Full Actuator Nonlinear Dynamic Inversion for Enhanced Hybrid UAV Control (Masters Thesis) TU Delft Aerospace Engineering, 2026, (van Kampen, E. (graduation committee member); Smeur, E.J.J. (mentor); Ntouros, E. (mentor); Theodoulis, Spilios (graduation committee member); Delft University of Technology (degree granting institution); graduation 11-02-2026). @mastersthesis{uuid:5640fa42-1c33-4639-838f-5fda5b4cb37f,
title = {Full Actuator Nonlinear Dynamic Inversion for Enhanced Hybrid UAV Control},
author = { J.P.G. Dubois},
url = {https://resolver.tudelft.nl/uuid:5640fa42-1c33-4639-838f-5fda5b4cb37f},
year = {2026},
date = {2026-01-01},
school = {TU Delft Aerospace Engineering},
abstract = {Expanding the operational capabilities of Micro Air Vehicles (MAVs) hinges on control systems that manage highly nonlinear dynamics across broad flight envelopes. Incremental Nonlinear Dynamic Inversion (INDI) is popular for its simplicity and modest modeling needs, but its assumption of infinitely fast actuators and neglect of state-dependent effects limit performance when actuators have slow or heterogeneous dynamics or when aerodynamic effects are significant. Actuator Nonlinear Dynamic Inversion (ANDI) overcomes these limitations by explicitly incorporating state-dependent dynamics and finite actuator bandwidth into the control law, enabling improved tracking performance across diverse actuator configurations. This work implements the full ANDI stabilization controller on the Cyclone, a hybrid MAV tail-sitter, using cascaded complementary filtering for state estimation. Simulation and flight experiments validate the approach and assess whether this compensation yields practical performance gains, establishing ANDI as a viable, generic control solution for MAVs Code is available at: https://github.com/tudelft/paparazzi/tree/feat_stabilization_andi_controller.},
note = {van Kampen, E. (graduation committee member); Smeur, E.J.J. (mentor); Ntouros, E. (mentor); Theodoulis, Spilios (graduation committee member); Delft University of Technology (degree granting institution); graduation 11-02-2026},
keywords = {},
pubstate = {published},
tppubtype = {mastersthesis}
}
Expanding the operational capabilities of Micro Air Vehicles (MAVs) hinges on control systems that manage highly nonlinear dynamics across broad flight envelopes. Incremental Nonlinear Dynamic Inversion (INDI) is popular for its simplicity and modest modeling needs, but its assumption of infinitely fast actuators and neglect of state-dependent effects limit performance when actuators have slow or heterogeneous dynamics or when aerodynamic effects are significant. Actuator Nonlinear Dynamic Inversion (ANDI) overcomes these limitations by explicitly incorporating state-dependent dynamics and finite actuator bandwidth into the control law, enabling improved tracking performance across diverse actuator configurations. This work implements the full ANDI stabilization controller on the Cyclone, a hybrid MAV tail-sitter, using cascaded complementary filtering for state estimation. Simulation and flight experiments validate the approach and assess whether this compensation yields practical performance gains, establishing ANDI as a viable, generic control solution for MAVs Code is available at: https://github.com/tudelft/paparazzi/tree/feat_stabilization_andi_controller. |
A.R.S. Bracke Incremental Nonlinear Dynamic Inversion Control of a Launch Vehicle Testbed (Masters Thesis) TU Delft Aerospace Engineering, 2026, (Smeur, E.J.J. (mentor); van Kampen, E. (mentor); de Visser, C.C. (graduation committee member); Mooij, E. (mentor); Acquatella, P. (mentor); Delft University of Technology (degree granting institution); graduation 27-03-2026). @mastersthesis{uuid:4202cea2-f25f-439d-aa15-cace7cca77cb,
title = {Incremental Nonlinear Dynamic Inversion Control of a Launch Vehicle Testbed},
author = { A.R.S. Bracke},
url = {https://resolver.tudelft.nl/uuid:4202cea2-f25f-439d-aa15-cace7cca77cb},
year = {2026},
date = {2026-01-01},
school = {TU Delft Aerospace Engineering},
abstract = {Launch vehicles traditionally rely on gain-scheduled PID controllers, which are time-consuming to develop, and require extensive modelling. Incremental Nonlinear Dynamic Inversion (INDI) may serve as an alternative to reduce model dependency, and streamline launch vehicle control system design and tuning. This work applies a cascaded INDI controller, with an inner attitude loop and an outer position loop, to the model of a small-scale launch vehicle testbed. Such testbeds are used in the context of Guidance, Navigation & Control (GNC) to develop and test algorithms on a physical system in a cost-effective and low-risk fashion. Wind disturbance, propellant sloshing, and tail-wags-dog, i.e. the effect of the engine’s motion on the rest of the vehicle, are considered in the model. The results show that INDI provides a simple way to develop a nonlinear control law that maintains robust position reference tracking in the presence of disturbance and model uncertainty. Finally, it is determined that a small-scale testbed is not suitable for studying the impact of sloshing on the closed loop control systems of launch vehicles, since at this scale the sloshing mass is too small and the natural frequency of the sloshing dynamics is too high.},
note = {Smeur, E.J.J. (mentor); van Kampen, E. (mentor); de Visser, C.C. (graduation committee member); Mooij, E. (mentor); Acquatella, P. (mentor); Delft University of Technology (degree granting institution); graduation 27-03-2026},
keywords = {},
pubstate = {published},
tppubtype = {mastersthesis}
}
Launch vehicles traditionally rely on gain-scheduled PID controllers, which are time-consuming to develop, and require extensive modelling. Incremental Nonlinear Dynamic Inversion (INDI) may serve as an alternative to reduce model dependency, and streamline launch vehicle control system design and tuning. This work applies a cascaded INDI controller, with an inner attitude loop and an outer position loop, to the model of a small-scale launch vehicle testbed. Such testbeds are used in the context of Guidance, Navigation & Control (GNC) to develop and test algorithms on a physical system in a cost-effective and low-risk fashion. Wind disturbance, propellant sloshing, and tail-wags-dog, i.e. the effect of the engine’s motion on the rest of the vehicle, are considered in the model. The results show that INDI provides a simple way to develop a nonlinear control law that maintains robust position reference tracking in the presence of disturbance and model uncertainty. Finally, it is determined that a small-scale testbed is not suitable for studying the impact of sloshing on the closed loop control systems of launch vehicles, since at this scale the sloshing mass is too small and the natural frequency of the sloshing dynamics is too high. |
R.J.N. Zwikker Continuous-Time Modelling of Pixel Attributes: The Development of a Continuous Frame Interpolation Method and a Fast, Real-Time Event Camera Simulator (Masters Thesis) TU Delft Aerospace Engineering, 2026, (de Croon, G.C.H.E. (mentor); Wu, Y. (mentor); Delft University of Technology (degree granting institution); graduation 31-03-2026). @mastersthesis{uuid:2f3427d8-7779-41ab-8915-ca38e58edb1f,
title = {Continuous-Time Modelling of Pixel Attributes: The Development of a Continuous Frame Interpolation Method and a Fast, Real-Time Event Camera Simulator},
author = { R.J.N. Zwikker},
url = {https://resolver.tudelft.nl/uuid:2f3427d8-7779-41ab-8915-ca38e58edb1f},
year = {2026},
date = {2026-01-01},
school = {TU Delft Aerospace Engineering},
abstract = {There is an increasing interest in Event-based cameras for computer vision purposes. These cameras provide benefits such as high temporal resolution and high dynamic range by capturing the change in brightness instead of the absolute brightness signal. In order to train learning-based behaviours with event-based cameras, it is essential to be able to simulate the output of these cameras in a virtual world. Unlike their traditional frame-based counterparts, there are no real-time event-based camera rendering engines yet. All existing methods of generating events from virtual scenes impose a significant computational burden, simulating events by generating frames at a very high temporal resolution and converting these frames to events. This thesis proposes a novel method of event generation, by continuously interpolating between frames at a low temporal resolution, using auxiliary data from the rendering engine, such as depth and optical flow. In this method, the backwards pixel sampling problem is solved using a triangle grid created between all pixels, that is used to model the continuous response of each pixel between rendered frames. Other than previous methods that used VFI to temporally upsample LFR frames for event generation, this method does not create intermediate frames, instead simulating events directly from the continuous model. This method is implemented on the CPU, where it is shown to correctly interpolate the signal between frames. It is also implemented in Unreal Engine, where it is used to generate events in near real-time.},
note = {de Croon, G.C.H.E. (mentor); Wu, Y. (mentor); Delft University of Technology (degree granting institution); graduation 31-03-2026},
keywords = {},
pubstate = {published},
tppubtype = {mastersthesis}
}
There is an increasing interest in Event-based cameras for computer vision purposes. These cameras provide benefits such as high temporal resolution and high dynamic range by capturing the change in brightness instead of the absolute brightness signal. In order to train learning-based behaviours with event-based cameras, it is essential to be able to simulate the output of these cameras in a virtual world. Unlike their traditional frame-based counterparts, there are no real-time event-based camera rendering engines yet. All existing methods of generating events from virtual scenes impose a significant computational burden, simulating events by generating frames at a very high temporal resolution and converting these frames to events. This thesis proposes a novel method of event generation, by continuously interpolating between frames at a low temporal resolution, using auxiliary data from the rendering engine, such as depth and optical flow. In this method, the backwards pixel sampling problem is solved using a triangle grid created between all pixels, that is used to model the continuous response of each pixel between rendered frames. Other than previous methods that used VFI to temporally upsample LFR frames for event generation, this method does not create intermediate frames, instead simulating events directly from the continuous model. This method is implemented on the CPU, where it is shown to correctly interpolate the signal between frames. It is also implemented in Unreal Engine, where it is used to generate events in near real-time. |
A.H.H. Dourleijn Hardware-in-the-loop simulation for Earth-based testing of On-Orbit Servicing using Soft Continuum Robotics (Masters Thesis) TU Delft Aerospace Engineering, 2026, (Della Santina, Cosimo (mentor); Popovic, M. (mentor); Delft University of Technology (degree granting institution); graduation 27-08-2026). @mastersthesis{uuid:24578072-a7e5-46ba-8baa-79896cb09f3c,
title = {Hardware-in-the-loop simulation for Earth-based testing of On-Orbit Servicing using Soft Continuum Robotics},
author = { A.H.H. Dourleijn},
url = {https://resolver.tudelft.nl/uuid:24578072-a7e5-46ba-8baa-79896cb09f3c},
year = {2026},
date = {2026-01-01},
school = {TU Delft Aerospace Engineering},
abstract = {Soft continuum robots offer several advantages compared to rigid manipulators when used for on-orbit servicing (OOS) due to their inherent compliance and infinite degrees of freedom. However, these advantages also mean that their behaviour is heavily influenced by the presence of gravity, making representative testing on earth impossible without gravity compensation. This report presents a novel hardware-in-the-loop (HIL) testing setup that allows for representative, terrestrial testing of rigid-soft spacecraft dynamics. Dynamical models of a hybrid chaser spacecraft, featuring soft continuum manipulators (CSM) mounted on a rigid base, and a rigid target body are considered. The hybrid chaser is modelled using the geometrical variable strain approach using a single set of generalised coordinates to represent both the rigid body movement as well as CSM deformations allowing dynamical coupling between the base and the CSMs. A contact model is used to model interactions of the CSMs with the target body. In the HIL setup the relative dynamics between the chaser and the target are reproduced using a rigid manipulator on which the target body is mounted. External forces on the target body are recorded using a force-torque sensor mounted between the body and the manipulator. The setup is tested using two OOS scenarios: successful capture and single CSM interaction. Experiments show that positional errors between the simulated and reproduced bodies on the testbed lie are in the magnitude of 1 cm, both during approach and capture phases. Despite concurrent force measurements from both the FTS and the contact model, the coupled simulation remains numerically stable, the system energy remains bounded and CSM state in simulation as on the testbed remain closely matched. These results demonstrate that the proposed HIL framework can accurately reproduce the coupled dynamics of rigid-soft spacecraft interactions, providing a practical platform for terrestrial validation of continuum manipulator concepts for on-orbit servicing.},
note = {Della Santina, Cosimo (mentor); Popovic, M. (mentor); Delft University of Technology (degree granting institution); graduation 27-08-2026},
keywords = {},
pubstate = {published},
tppubtype = {mastersthesis}
}
Soft continuum robots offer several advantages compared to rigid manipulators when used for on-orbit servicing (OOS) due to their inherent compliance and infinite degrees of freedom. However, these advantages also mean that their behaviour is heavily influenced by the presence of gravity, making representative testing on earth impossible without gravity compensation. This report presents a novel hardware-in-the-loop (HIL) testing setup that allows for representative, terrestrial testing of rigid-soft spacecraft dynamics. Dynamical models of a hybrid chaser spacecraft, featuring soft continuum manipulators (CSM) mounted on a rigid base, and a rigid target body are considered. The hybrid chaser is modelled using the geometrical variable strain approach using a single set of generalised coordinates to represent both the rigid body movement as well as CSM deformations allowing dynamical coupling between the base and the CSMs. A contact model is used to model interactions of the CSMs with the target body. In the HIL setup the relative dynamics between the chaser and the target are reproduced using a rigid manipulator on which the target body is mounted. External forces on the target body are recorded using a force-torque sensor mounted between the body and the manipulator. The setup is tested using two OOS scenarios: successful capture and single CSM interaction. Experiments show that positional errors between the simulated and reproduced bodies on the testbed lie are in the magnitude of 1 cm, both during approach and capture phases. Despite concurrent force measurements from both the FTS and the contact model, the coupled simulation remains numerically stable, the system energy remains bounded and CSM state in simulation as on the testbed remain closely matched. These results demonstrate that the proposed HIL framework can accurately reproduce the coupled dynamics of rigid-soft spacecraft interactions, providing a practical platform for terrestrial validation of continuum manipulator concepts for on-orbit servicing. |
S.D. Bhawan Energy-Aware Multi-UAV Coordination using Informative Path Planning for Maritime Search and Rescue: Exploiting Flight-Regime Energy Dynamics (Masters Thesis) TU Delft Aerospace Engineering, 2026, (Popovic, M. (mentor); Remes, B.D.W. (mentor); Delft University of Technology (degree granting institution); graduation 23-04-2026). @mastersthesis{uuid:0b624189-f88b-490e-ad4f-fb90951d5fef,
title = {Energy-Aware Multi-UAV Coordination using Informative Path Planning for Maritime Search and Rescue: Exploiting Flight-Regime Energy Dynamics},
author = { S.D. Bhawan},
url = {https://resolver.tudelft.nl/uuid:0b624189-f88b-490e-ad4f-fb90951d5fef},
year = {2026},
date = {2026-01-01},
school = {TU Delft Aerospace Engineering},
abstract = {Autonomous maritime search and rescue faces critical challenges due to limited endurance and dynamic victim drift. This thesis presents a centralized multi-UAV coordination framework based on Energy-Aware Informative Path Planning. The aim is to maximize mission endurance by exploiting the distinct energy dynamics of different flight regimes, such as the efficiency of fixed-wing cruise versus the high cost of hovering. Locally, a Receding Horizon Planner optimizes the trade-off between entropy reduction and energy consumption. The framework provides global coordination by dynamically switching agents between high-altitude exploration and low-altitude target tracking while accounting for the effects of ocean drift. Monte Carlo simulations using the empirical power model of the Variable Skew Quad Plane evaluate the swarm size required to achieve 80% global entropy reduction and successfully confirm multiple victims within a strict 10-minute timespan. The evaluation reveals a fundamental trade-off between spatial clearing speed and environmental robustness—defined as the system's ability to maintain consistent search performance despite adverse wind disturbances. Although boustrophedon coverage is efficient in optimal conditions, adverse crosswinds cause accelerated energy drain, potentially leading to early mission failure. By dynamically surfing wind gradients, the proposed method extends mission endurance while maintaining sufficient coverage capabilities in these severe crosswind scenarios. Finally, the communication and coordination logic of the framework was validated through real-world flight tests with a swarm of Parrot Bebop 2s.},
note = {Popovic, M. (mentor); Remes, B.D.W. (mentor); Delft University of Technology (degree granting institution); graduation 23-04-2026},
keywords = {},
pubstate = {published},
tppubtype = {mastersthesis}
}
Autonomous maritime search and rescue faces critical challenges due to limited endurance and dynamic victim drift. This thesis presents a centralized multi-UAV coordination framework based on Energy-Aware Informative Path Planning. The aim is to maximize mission endurance by exploiting the distinct energy dynamics of different flight regimes, such as the efficiency of fixed-wing cruise versus the high cost of hovering. Locally, a Receding Horizon Planner optimizes the trade-off between entropy reduction and energy consumption. The framework provides global coordination by dynamically switching agents between high-altitude exploration and low-altitude target tracking while accounting for the effects of ocean drift. Monte Carlo simulations using the empirical power model of the Variable Skew Quad Plane evaluate the swarm size required to achieve 80% global entropy reduction and successfully confirm multiple victims within a strict 10-minute timespan. The evaluation reveals a fundamental trade-off between spatial clearing speed and environmental robustness—defined as the system's ability to maintain consistent search performance despite adverse wind disturbances. Although boustrophedon coverage is efficient in optimal conditions, adverse crosswinds cause accelerated energy drain, potentially leading to early mission failure. By dynamically surfing wind gradients, the proposed method extends mission endurance while maintaining sufficient coverage capabilities in these severe crosswind scenarios. Finally, the communication and coordination logic of the framework was validated through real-world flight tests with a swarm of Parrot Bebop 2s. |
E.K. Cho An Active Perception Framework for Assessing Object Pushability with Aerial Robots (Masters Thesis) TU Delft Aerospace Engineering, 2026, (Popovic, M. (mentor); Hamaza, S. (mentor); Delft University of Technology (degree granting institution); graduation 03-11-2026). @mastersthesis{uuid:94266598-acb5-498f-8316-da3e4a001f3c,
title = {An Active Perception Framework for Assessing Object Pushability with Aerial Robots},
author = { E.K. Cho},
url = {https://resolver.tudelft.nl/uuid:94266598-acb5-498f-8316-da3e4a001f3c},
year = {2026},
date = {2026-01-01},
school = {TU Delft Aerospace Engineering},
abstract = {Aerial robots typically treat surrounding objects as obstacles, even when some could be pushed aside. This thesis presents a vision-based active-perception framework for assessing whether an aerial robot has sufficient force to push an unknown object. The framework includes an uncertain outcome to indicate when visual estimates do not support a definite decision and physical probing would be needed; executing physical probing and pushing is outside the scope of this work. Pushability is modeled relative to the robot's available horizontal force and the object's estimated resistance to sliding. Active multi-view voxel reconstruction estimates object volume, while material classification provides a class associated with predefined density and static-friction coefficient intervals. These estimates form a friction-force interval that, together with a material-confidence check, produces one of three outcomes: pushable, not pushable, or uncertain. In the integrated Unity evaluation, no object was incorrectly classified as pushable. However, only 10 of 22 force-feasibility decisions for objects with accepted material predictions matched the reference outcome, and six of seven reference-ambiguous objects were classified as not pushable rather than uncertain. Counterfactual analysis linked most errors to limitations in the density–friction model, with a plausible contributing explanation being the mismatch between solid-material density assumptions and the effective densities of hollow or composite objects. In Gazebo, two of eight objects received the intended decision, while three could not complete viewpoint acquisition. The framework provides a baseline for visual assessment of aerial pushing force feasibility, while the results highlight the need for more representative physical-property models, explicit treatment of volume uncertainty, and integration of physical probing.},
note = {Popovic, M. (mentor); Hamaza, S. (mentor); Delft University of Technology (degree granting institution); graduation 03-11-2026},
keywords = {},
pubstate = {published},
tppubtype = {mastersthesis}
}
Aerial robots typically treat surrounding objects as obstacles, even when some could be pushed aside. This thesis presents a vision-based active-perception framework for assessing whether an aerial robot has sufficient force to push an unknown object. The framework includes an uncertain outcome to indicate when visual estimates do not support a definite decision and physical probing would be needed; executing physical probing and pushing is outside the scope of this work. Pushability is modeled relative to the robot's available horizontal force and the object's estimated resistance to sliding. Active multi-view voxel reconstruction estimates object volume, while material classification provides a class associated with predefined density and static-friction coefficient intervals. These estimates form a friction-force interval that, together with a material-confidence check, produces one of three outcomes: pushable, not pushable, or uncertain. In the integrated Unity evaluation, no object was incorrectly classified as pushable. However, only 10 of 22 force-feasibility decisions for objects with accepted material predictions matched the reference outcome, and six of seven reference-ambiguous objects were classified as not pushable rather than uncertain. Counterfactual analysis linked most errors to limitations in the density–friction model, with a plausible contributing explanation being the mismatch between solid-material density assumptions and the effective densities of hollow or composite objects. In Gazebo, two of eight objects received the intended decision, while three could not complete viewpoint acquisition. The framework provides a baseline for visual assessment of aerial pushing force feasibility, while the results highlight the need for more representative physical-property models, explicit treatment of volume uncertainty, and integration of physical probing. |
T. Vennink Asynchronous Event-Based Visual-Inertial Odometry for Flapping-Wing MAVs (Masters Thesis) TU Delft Mechanical Engineering, 2026, (de Croon, G.C.H.E. (graduation committee member); Shyrokau, B. (graduation committee member); de Wagter, C. (graduation committee member); Kober, J. (mentor); Stroobants, S. (mentor); Delft University of Technology (degree granting institution); graduation 24-07-2026). @mastersthesis{uuid:6b1796a0-4c41-43b9-ae07-f11ce44f1f83,
title = {Asynchronous Event-Based Visual-Inertial Odometry for Flapping-Wing MAVs},
author = { T. Vennink},
url = {https://resolver.tudelft.nl/uuid:6b1796a0-4c41-43b9-ae07-f11ce44f1f83},
year = {2026},
date = {2026-01-01},
school = {TU Delft Mechanical Engineering},
abstract = {Flapping-Wing Micro Air Vehicles (FWMAVs) operate under severe Size, Weight, and Power (SWaP) constraints, and their high-frequency flapping produces strong oscillatory dynamics that degrade conventional frame-based visual perception. Event cameras are well suited to these conditions, but event-based visual-inertial odometry (EVIO) methods typically rely on short time-window, locally linear motion assumptions that flapping flight breaks: under flapping, event-alignment methods such as plane fitting and contrast maximization recover mostly the high-frequency flapping-induced body rotation rather than the platform's translation. This work presents the first full EVIO pipeline running entirely on-board a small, high-frequency flapping-wing platform. The front-end deliberately avoids short-window alignment and instead exploits the abundance of flapping-induced events: it detects corner features event-by-event, clusters them into compact spatiotemporal features, and tracks these while discarding the fine oscillatory structure. The resulting feature tracks are fused with inertial measurements in a tightly coupled Extended Kalman Filter. The complete pipeline runs in real time on an on-board microcontroller within a sensing-and-compute payload of roughly 21 g. On flight datasets recorded on-board the FWMAV, the pipeline recovers velocity and attitude during flapping flight, and in a closed-loop flight test the on-board position estimate is accurate enough to hold a stationary hover in the horizontal plane. The same event stream that breaks conventional EVIO assumptions is thus sufficient not only for on-board state estimation, but for closing a position-control loop in flight.},
note = {de Croon, G.C.H.E. (graduation committee member); Shyrokau, B. (graduation committee member); de Wagter, C. (graduation committee member); Kober, J. (mentor); Stroobants, S. (mentor); Delft University of Technology (degree granting institution); graduation 24-07-2026},
keywords = {},
pubstate = {published},
tppubtype = {mastersthesis}
}
Flapping-Wing Micro Air Vehicles (FWMAVs) operate under severe Size, Weight, and Power (SWaP) constraints, and their high-frequency flapping produces strong oscillatory dynamics that degrade conventional frame-based visual perception. Event cameras are well suited to these conditions, but event-based visual-inertial odometry (EVIO) methods typically rely on short time-window, locally linear motion assumptions that flapping flight breaks: under flapping, event-alignment methods such as plane fitting and contrast maximization recover mostly the high-frequency flapping-induced body rotation rather than the platform's translation. This work presents the first full EVIO pipeline running entirely on-board a small, high-frequency flapping-wing platform. The front-end deliberately avoids short-window alignment and instead exploits the abundance of flapping-induced events: it detects corner features event-by-event, clusters them into compact spatiotemporal features, and tracks these while discarding the fine oscillatory structure. The resulting feature tracks are fused with inertial measurements in a tightly coupled Extended Kalman Filter. The complete pipeline runs in real time on an on-board microcontroller within a sensing-and-compute payload of roughly 21 g. On flight datasets recorded on-board the FWMAV, the pipeline recovers velocity and attitude during flapping flight, and in a closed-loop flight test the on-board position estimate is accurate enough to hold a stationary hover in the horizontal plane. The same event stream that breaks conventional EVIO assumptions is thus sufficient not only for on-board state estimation, but for closing a position-control loop in flight. |
Miscellaneous
|
Evangelos Ntouros; Ewoud J. J. Smeur Coordinated Incremental Trajectory Tracking of a Tailsitter Drone (Miscellaneous) 2026. @misc{2607.11651,
title = {Coordinated Incremental Trajectory Tracking of a Tailsitter Drone},
author = { Evangelos Ntouros and Ewoud J. J. Smeur},
url = {https://arxiv.org/abs/2607.11651},
year = {2026},
date = {2026-01-01},
keywords = {},
pubstate = {published},
tppubtype = {misc}
}
|
Tom Aantjes; Till M. Blaha; Spilios Theodoulis; Ewoud J. J. Smeur Robust $mathcalH_ınfty$ Controller Design For INDI-Controlled Quadrotor Using Online Parameter Identification (Miscellaneous) 2026. @misc{2605.05483,
title = {Robust $mathcalH_ınfty$ Controller Design For INDI-Controlled Quadrotor Using Online Parameter Identification},
author = { Tom Aantjes and Till M. Blaha and Spilios Theodoulis and Ewoud J. J. Smeur},
url = {https://arxiv.org/abs/2605.05483},
year = {2026},
date = {2026-01-01},
keywords = {},
pubstate = {published},
tppubtype = {misc}
}
|