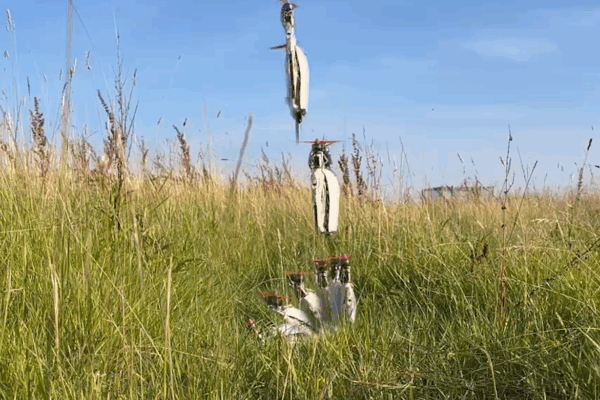
Design and Control of A Tilt-Rotor Tailsitter Aircraft with Pivoting VTOL Capability Content: In our newly accepted paper in IEEE Robotics and Automation Letters, we …
Micro Air Vehicle Lab – TUDelft
Design and Control of A Tilt-Rotor Tailsitter Aircraft with Pivoting VTOL Capability Content: In our newly accepted paper in IEEE Robotics and Automation Letters, we …
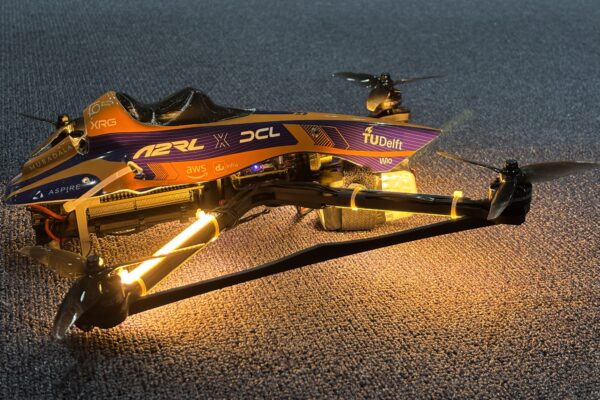
A team of scientists and students from TU Delft has taken first place at the A2RL Drone Championship in Abu Dhabi – an international race …
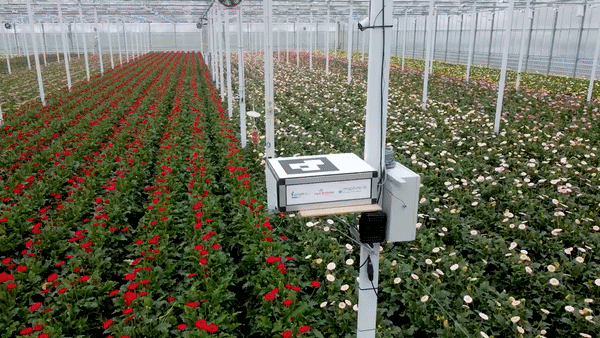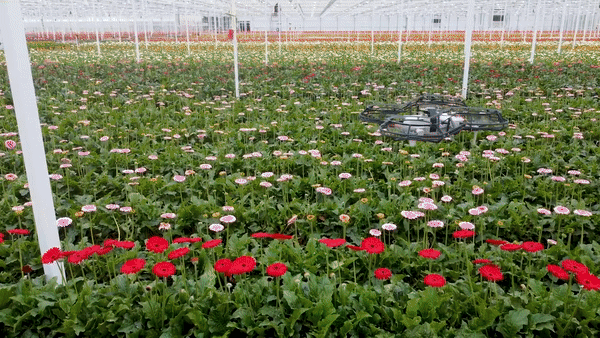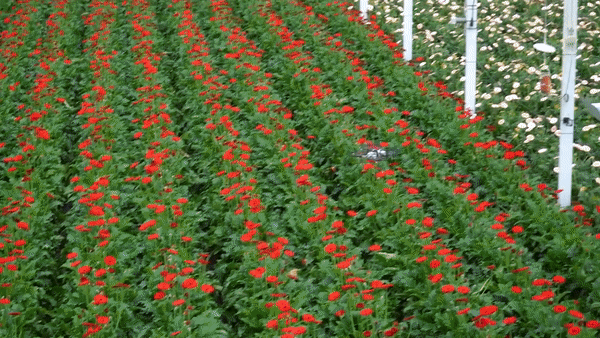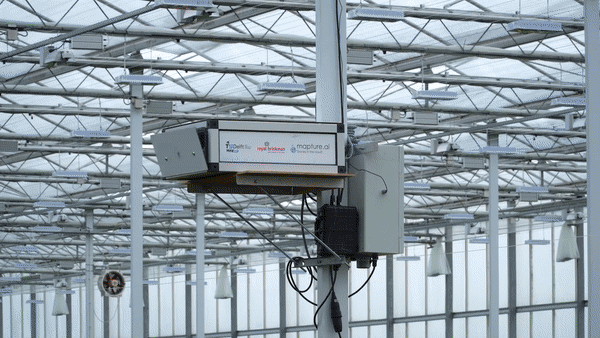
We have teamed up with Royal Brinkman and start-up Mapture to develop AI and drone technology for greenhouse monitoring. These lightweight drones are able to …
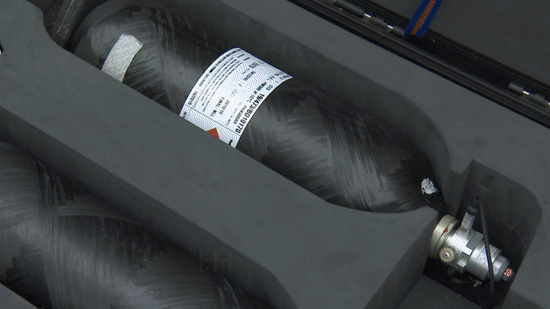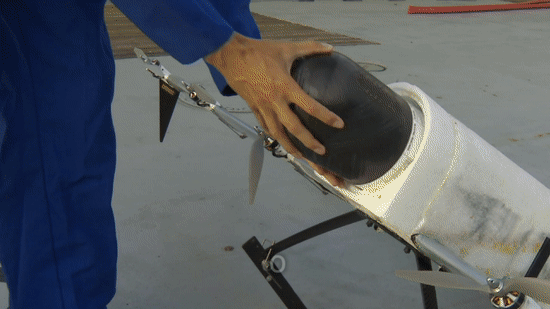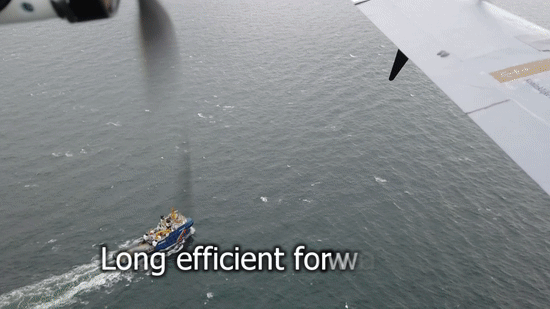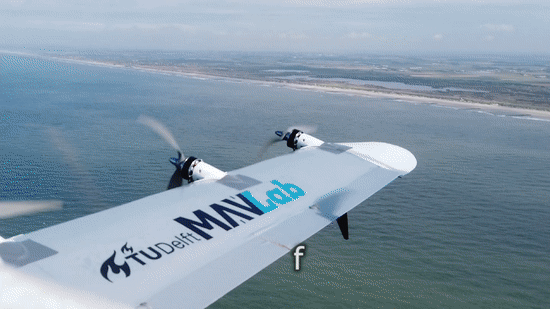
A drone that can fly sustainably for long distances over land and water, and can land almost anywhere, will be able to serve …
Neuromorphic processors like Loihi offer a promising alternative to conventional computing modules for endowing constrained systems like micro air vehicles (MAVs) with robust, …
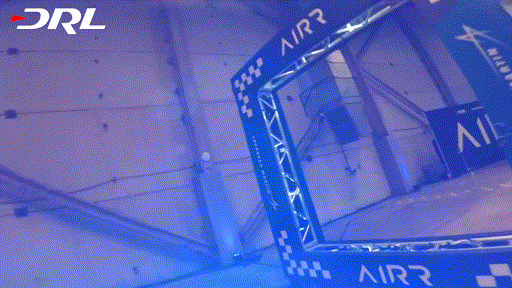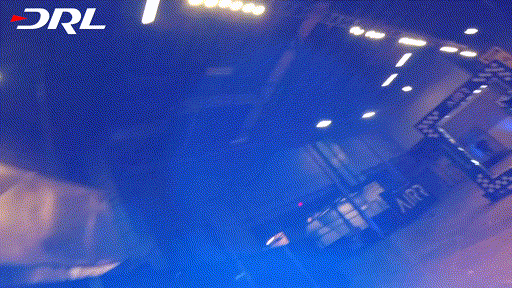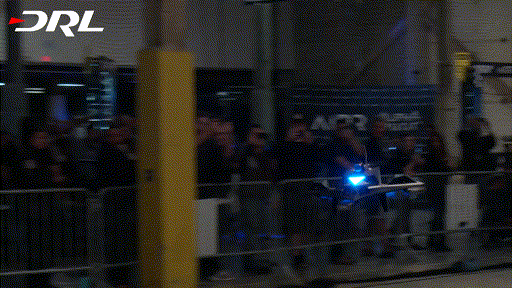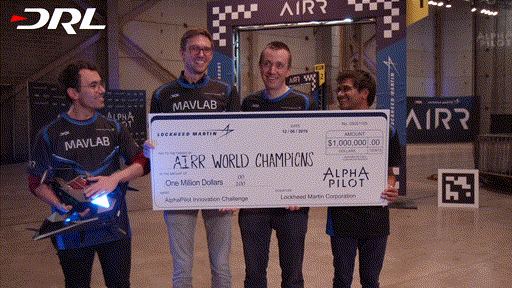
We are very proud to officially announce that we have won the AlphaPilot Drone Racing Innovation challenge!
Our latest paper in Science Robotics presents the first swarm of tiny robots that can explore unknown environments completely by themselves. No map, no memory, and no GPS!
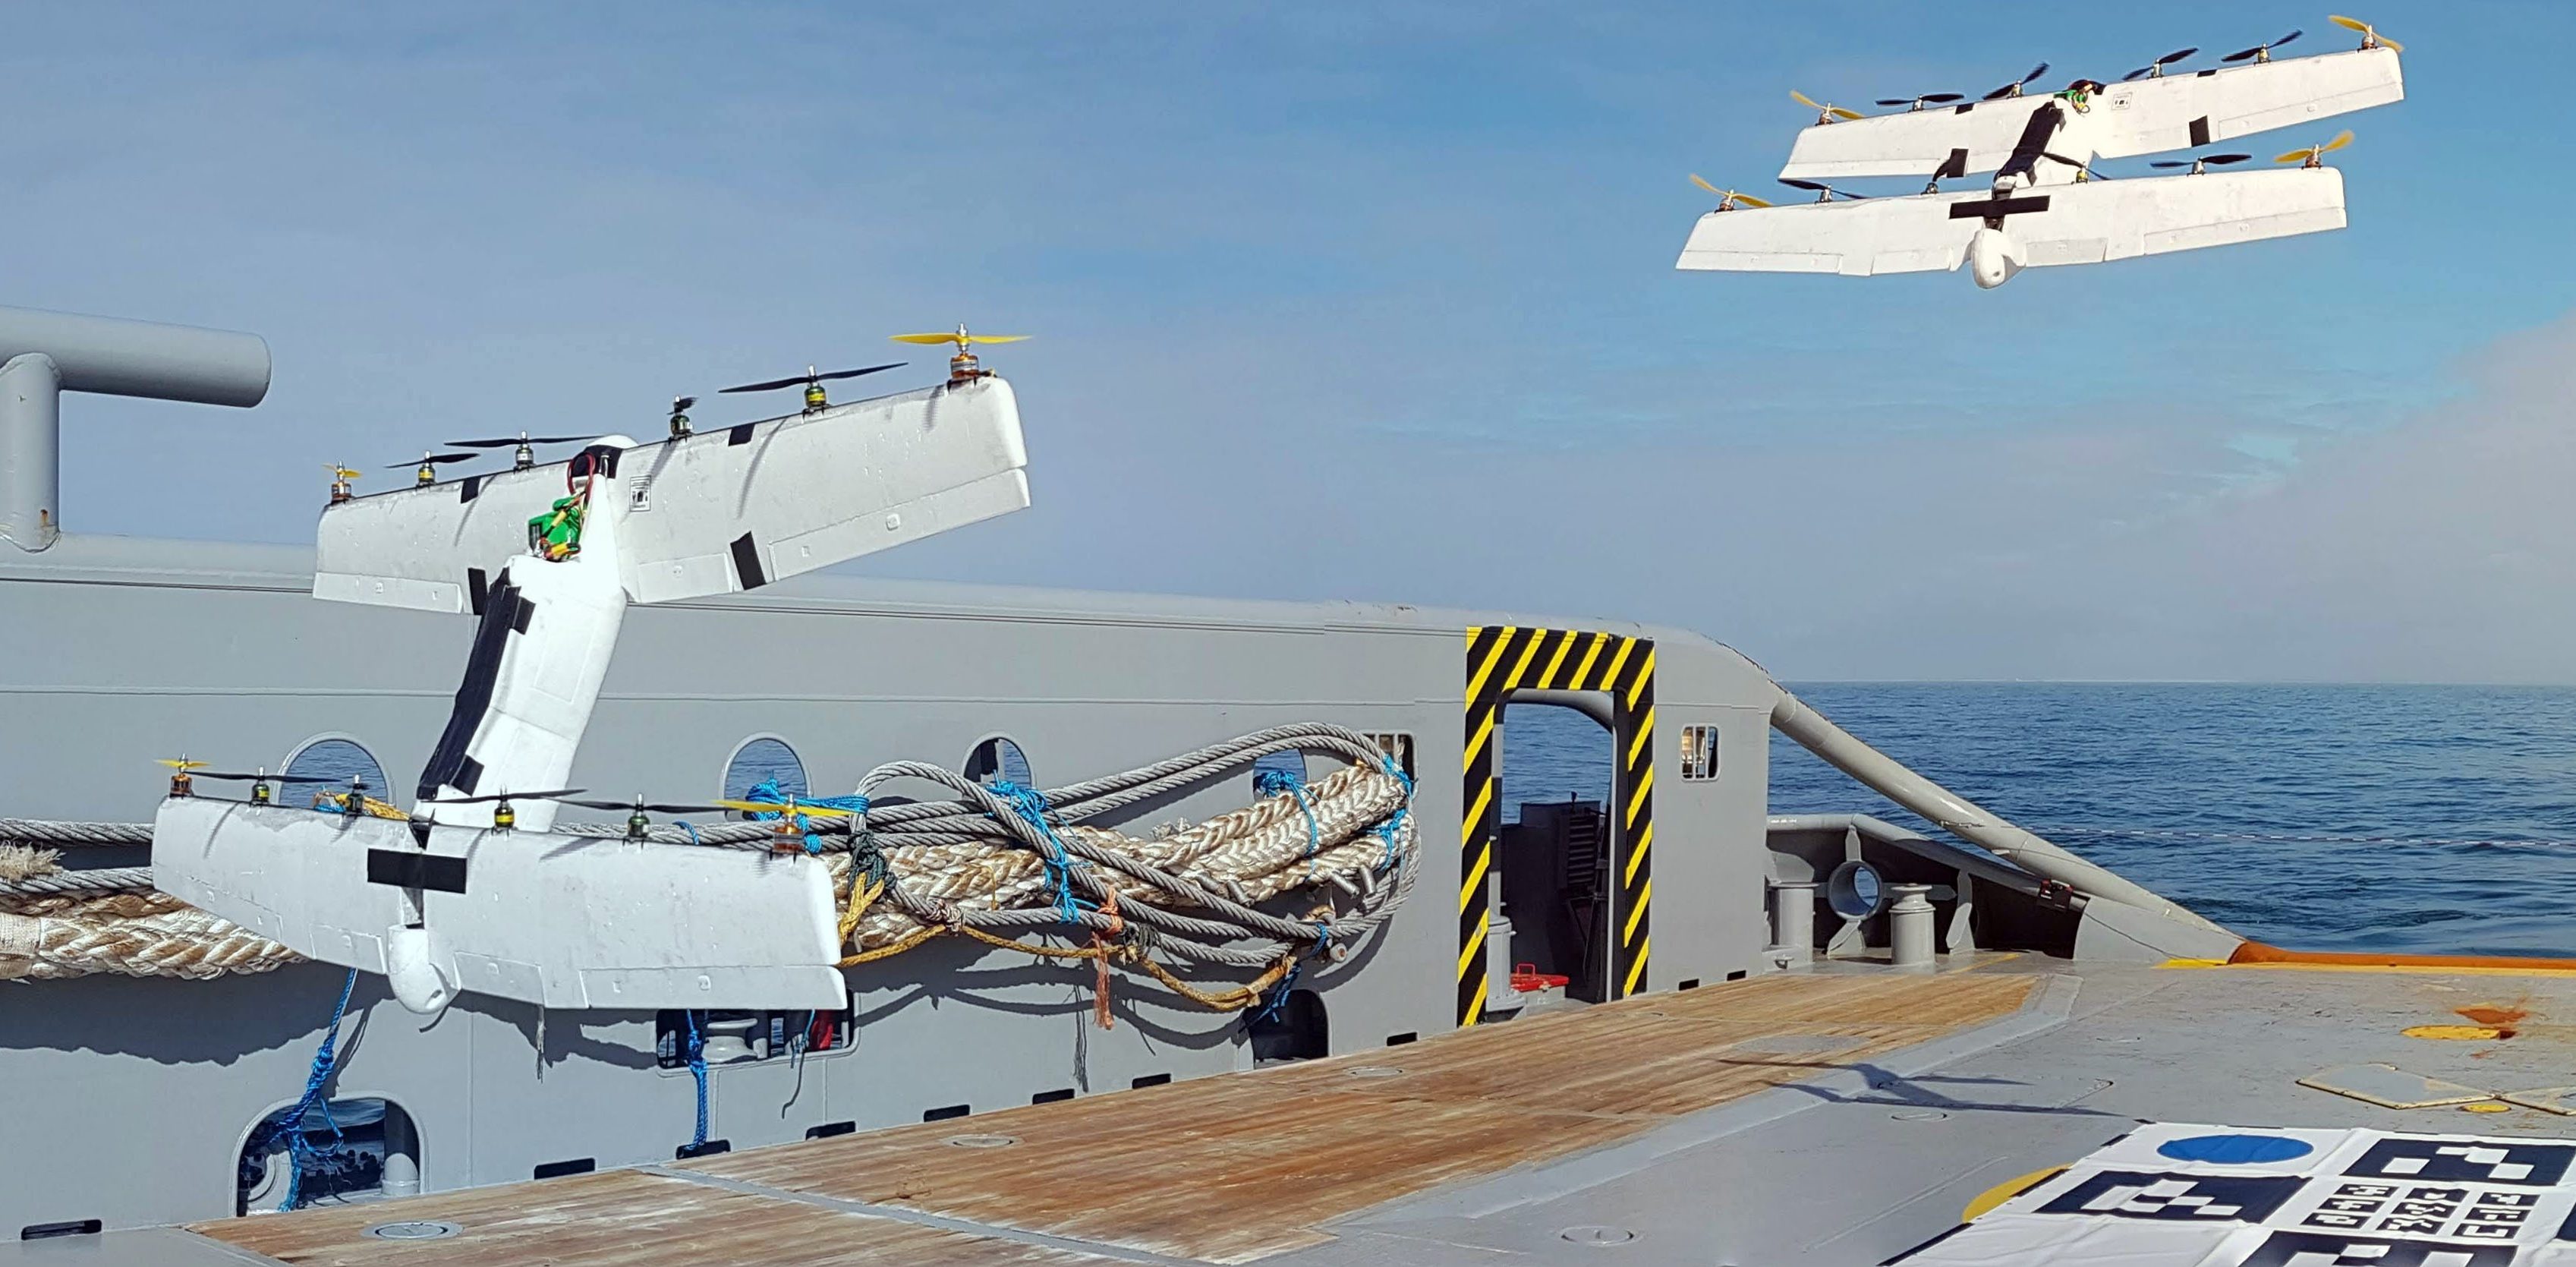
Design and Testing of a Vertical take-off and Landing UAV optimized for carrying a Hydrogen Fuel-cell with Pressure Tank.
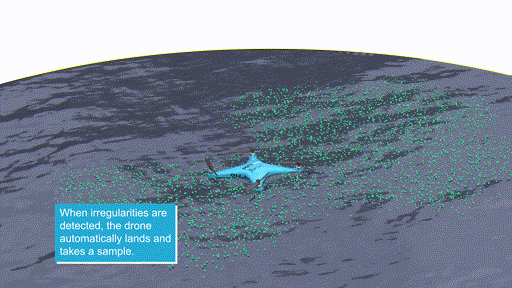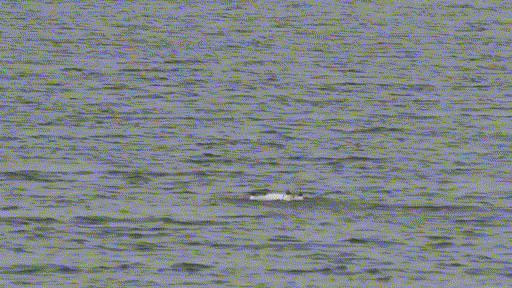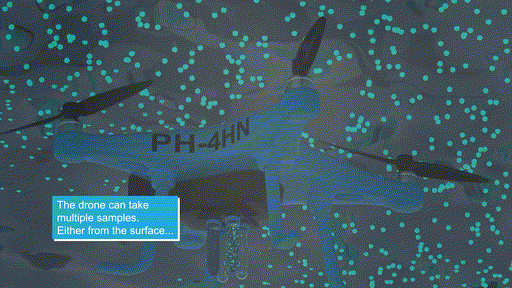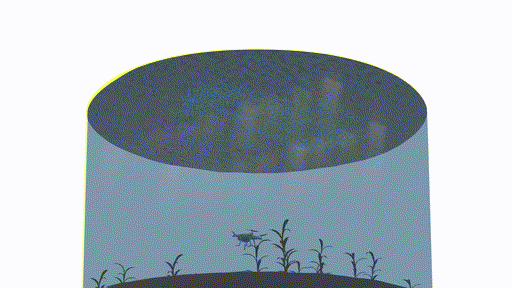
researchers from TU Delft have developed a ‘pelican drone’: a drone capable of taking water samples quickly, in combination with a measuring instrument that immediately analyses the water quality.
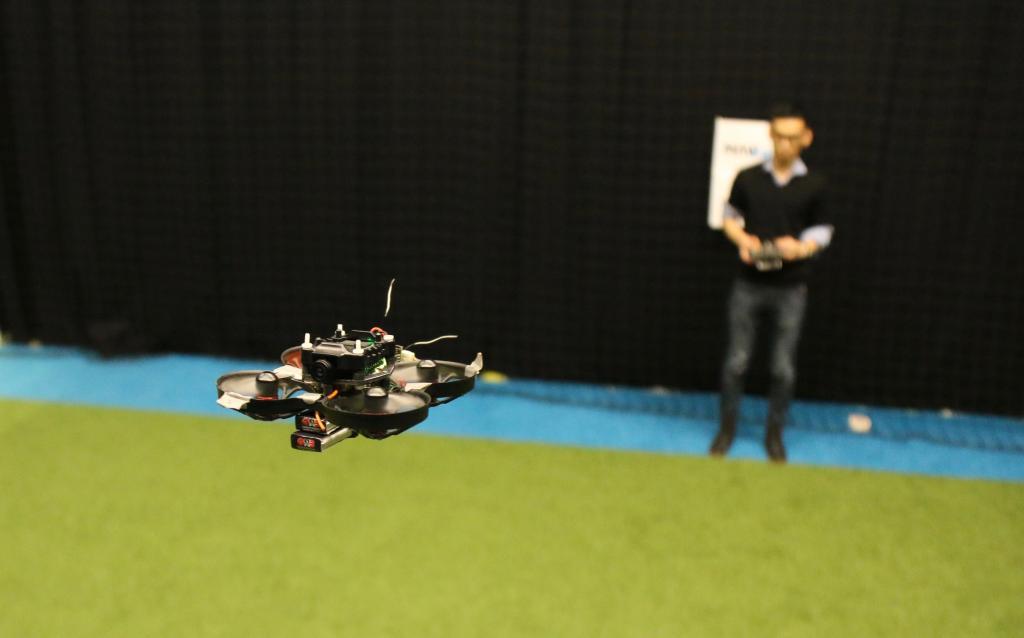
The drone racing team of the MAVLab has presented the currently smallest autonomous racing drone in the world.