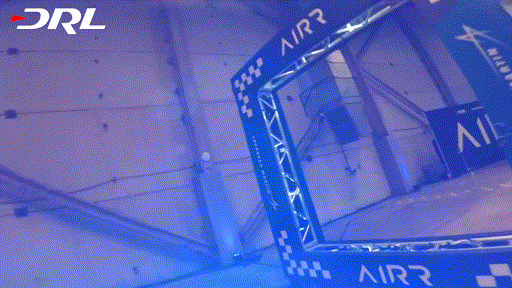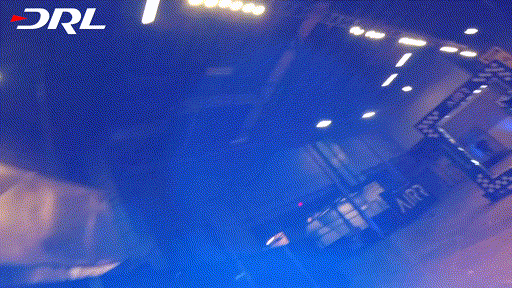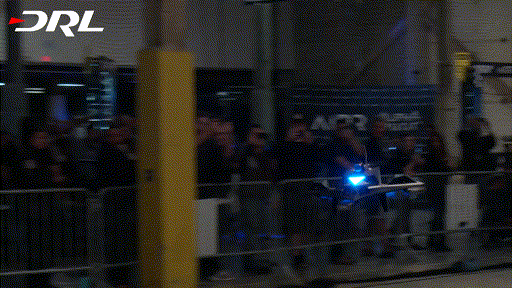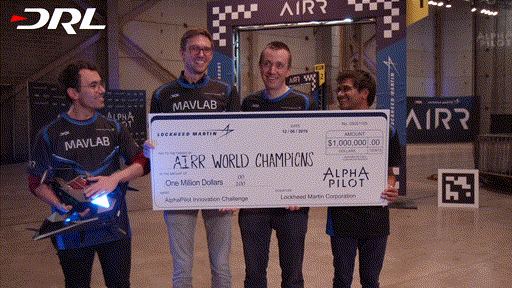
We are very proud to officially announce that we have won the AlphaPilot Drone Racing Innovation challenge!
Micro Air Vehicle Lab – TUDelft
We are very proud to officially announce that we have won the AlphaPilot Drone Racing Innovation challenge!
Our latest paper in Science Robotics presents the first swarm of tiny robots that can explore unknown environments completely by themselves. No map, no memory, and no GPS!
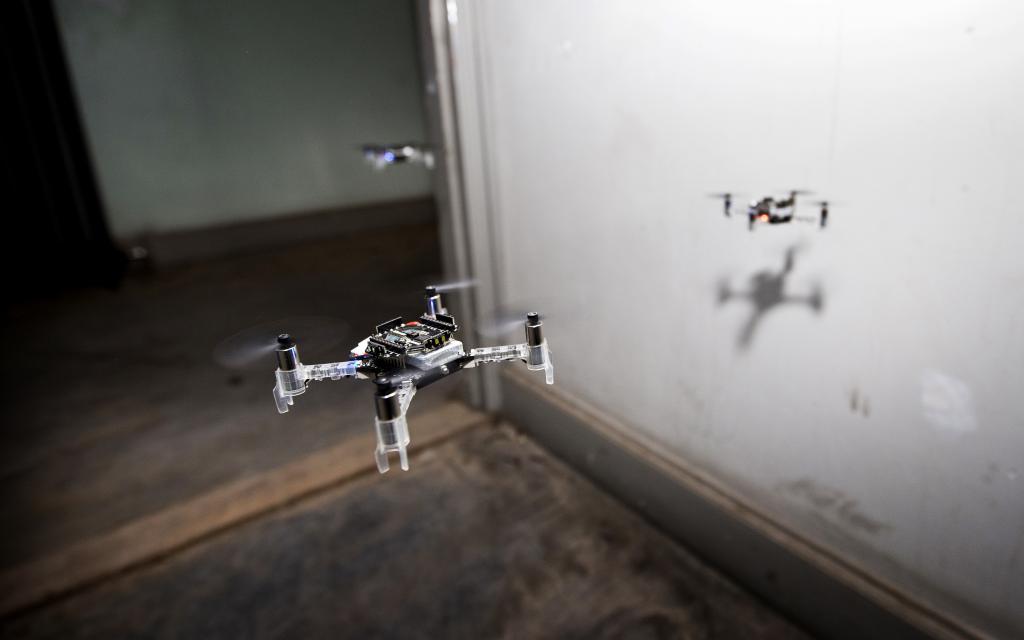
This database contains all the log files of the simulation and real world experiments of the publication: ‘Minimal navigation solution for a swarm of tiny flying robots to explore an unknown environment’ in Science robotics (2019).

The dataset contains robotic flight data of high agility maneuvers and fruit-fly inspired rapid banked turns, which are reported in the manuscript “A tailless aerial robotic flapper reveals that flies use torque coupling in rapid banked turns”.
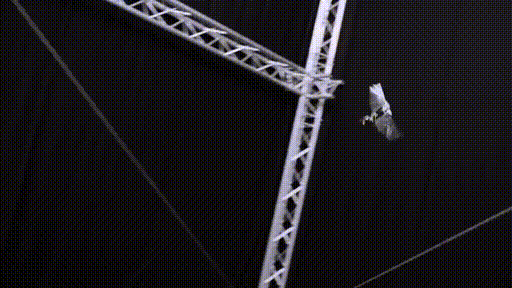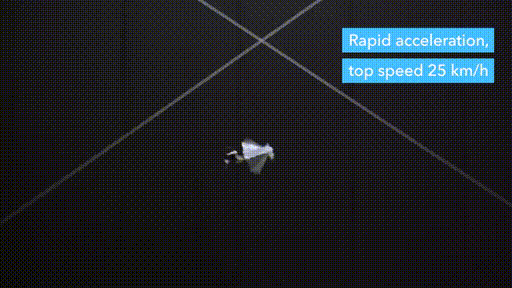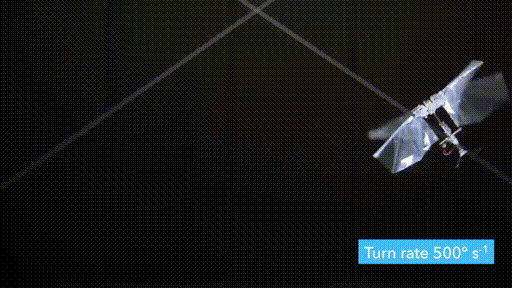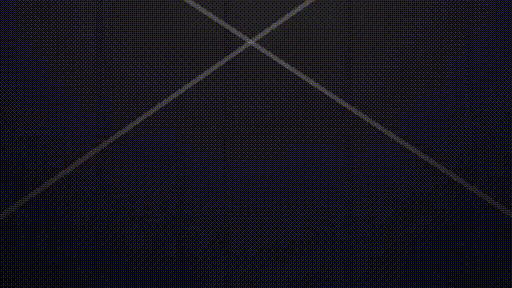
The DelFly Nimble, a new bio-inspired robot developed by MAVLab and employed for insect-flight research, is featured on the cover of the September 14 issue …

Raw data and processing software used to generate the results presented in our publication titled “Vertical Landing for Micro Air Vehicles using Event-Based Optical Flow

Free flight data of a DelFly II flapping wing MAV captured with an AFRL Vicon motion tracking system (four MAV configurations with different CG locations)