Skip to content

MAVLab

Micro Air Vehicle Lab – TUDelft

home
  • News
  • Research
    • Research Summary
    • Research
      • Robots
      • Code
      • Open-source code
      • Datasets
      • Competitions
    • Projects
      • Events
    • Spinoffs
  • People
  • Education
    • University Courses
    • Other
  • Publications and Datasets
    • Publications
    • Datasets
    • Open-source code
  • Media
  • Awards
  • Jobs
  • Contact
  • News
  • Research
    • Research Summary
    • Research
      • Robots
      • Code
      • Open-source code
      • Datasets
      • Competitions
    • Projects
      • Events
    • Spinoffs
  • People
  • Education
    • University Courses
    • Other
  • Publications and Datasets
    • Publications
    • Datasets
    • Open-source code
  • Media
  • Awards
  • Jobs
  • Contact

Category: Datasets

Code, Datasets, News, Research

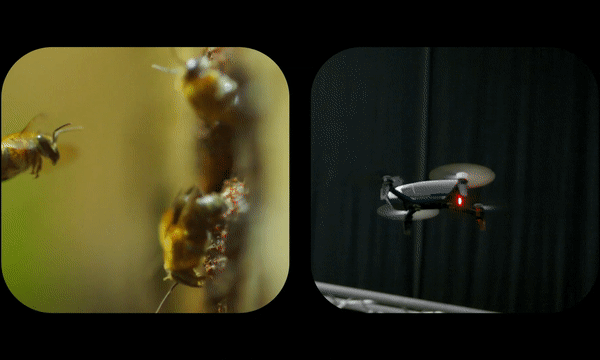
Honeybees teach drones how to navigate

Posted onMay 13, 2026October 30, 2026

It sounds like science fiction, but also strangely familiar: drones buzzing around, inspecting tomatoes in greenhouses, delivering your package or inspecting an industrial site. With …
Code, Datasets, News, Research

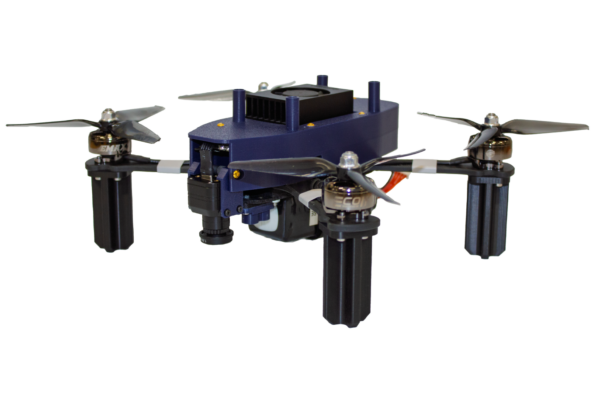
All Eyes, no IMU: Learning Flight Attitude from Vision Alone

Posted onDecember 15, 2025October 30, 2026

Our work on estimating attitude and angular rate with vision alone has been accepted for publication in Nature Portfolio Journals Robotics! It is part of …
Datasets, News, Research, Robots

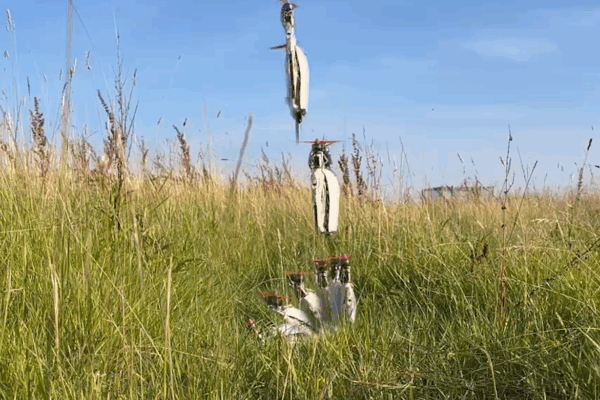
Design and Control of A Tilt-Rotor Tailsitter Aircraft with Pivoting VTOL Capability

Posted onApril 24, 2025October 30, 2026

Design and Control of A Tilt-Rotor Tailsitter Aircraft with Pivoting VTOL Capability Content: In our newly accepted paper in IEEE Robotics and Automation Letters, we …
Competitions, Datasets, News, Robots

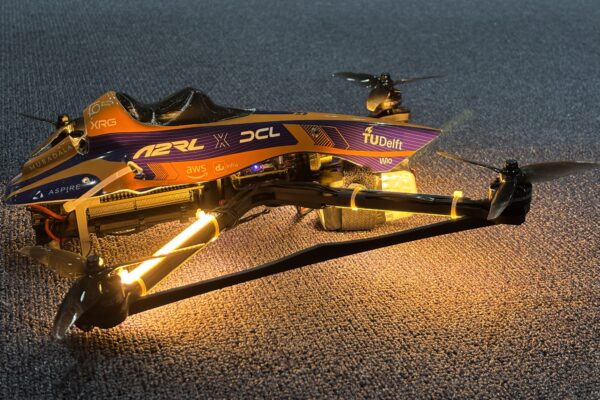
Autonomous Drone from TU Delft Defeats Human Champions in Historic Racing First

Posted onApril 16, 2025October 30, 2026

A team of scientists and students from TU Delft has taken first place at the A2RL Drone Championship in Abu Dhabi – an international race …
Code, Datasets, News, Research

MAVRL: Learn to Fly in Cluttered Environments with Varying Speed

Posted onJanuary 15, 2025October 30, 2026

We introduce a novel obstacle avoidance pipeline named Memory-Augmented Varying-speed Reinforcement Learning (MAVRL). MAVRL utilizes depth maps, along with the drone and target’s states as …
Competitions, Datasets, News

MAVLab & BioMorphic Lab, winners at IMAV2024 competitions!

Posted onSeptember 27, 2024October 30, 2026

Brief: First place at the outdoor competition, first place at the indoor competition, and the best paper award!🥇🥇🥇 The MAVLab and BioMorphic Lab were at …

Code, Datasets, News, Research

Fully neuromorphic vision and control for autonomous drone flight

Posted onApril 28, 2024October 30, 2026

Our work on fully neuromorphic vision and control for autonomous drone flight has been published in the Science Robotics May 2024 issue. In this work, …
Code, Datasets, Research

Direct learning of home vector direction for insect-inspired robot navigation (ICRA’24)

Posted onApril 28, 2024October 30, 2026

Abstract Insects have long been recognized for their ability to navigate and return home using visual cues from their nest’s environment. However, the precise mechanism …
Datasets, News, Research

Nature article reveals how flying insects and drones can discern up from down

Posted onOctober 19, 2022October 30, 2026

Researchers from MAVLab and collaborators have developed a new theory on how flying drones and insects can estimate the gravity direction. Whereas drones typically use …
Datasets, News, Research

Learning process as a Solution to Fundamental Optical-flow Problems

Posted onJanuary 19, 2021October 30, 2026

Optical flow for small flying robots Flying insects heavily rely on optical flow for visual navigation and flight control. Roboticists have endowed small flying robots …

Posts pagination

1 2 ‹
© 2026 MAVLab Powered by WordPress Theme by Design Lab