Skip to content

MAVLab

Micro Air Vehicle Lab – TUDelft

home
  • News
  • Research
    • Research Summary
    • Research
      • Robots
      • Code
      • Open-source code
      • Datasets
      • Competitions
    • Projects
      • Events
    • Spinoffs
  • People
  • Education
    • University Courses
    • Other
  • Publications and Datasets
    • Publications
    • Datasets
    • Open-source code
  • Media
  • Awards
  • Jobs
  • Contact
  • News
  • Research
    • Research Summary
    • Research
      • Robots
      • Code
      • Open-source code
      • Datasets
      • Competitions
    • Projects
      • Events
    • Spinoffs
  • People
  • Education
    • University Courses
    • Other
  • Publications and Datasets
    • Publications
    • Datasets
    • Open-source code
  • Media
  • Awards
  • Jobs
  • Contact

Tag: vision based landing

Datasets, News, Research

Learning process as a Solution to Fundamental Optical-flow Problems

Posted onJanuary 19, 2021October 30, 2026

Optical flow for small flying robots Flying insects heavily rely on optical flow for visual navigation and flight control. Roboticists have endowed small flying robots …
Competitions, Projects, Robots

DELFTACOPTER – Outback Medical Express

Posted onSeptember 19, 2016October 30, 2026

DELFTACOPTER is a hybrid electric UAV with exceptional efficiency both in hovering and fast forward flight. It is equipped with state of the art on-board stereoscopic …
See distances with one eye
Code, Research

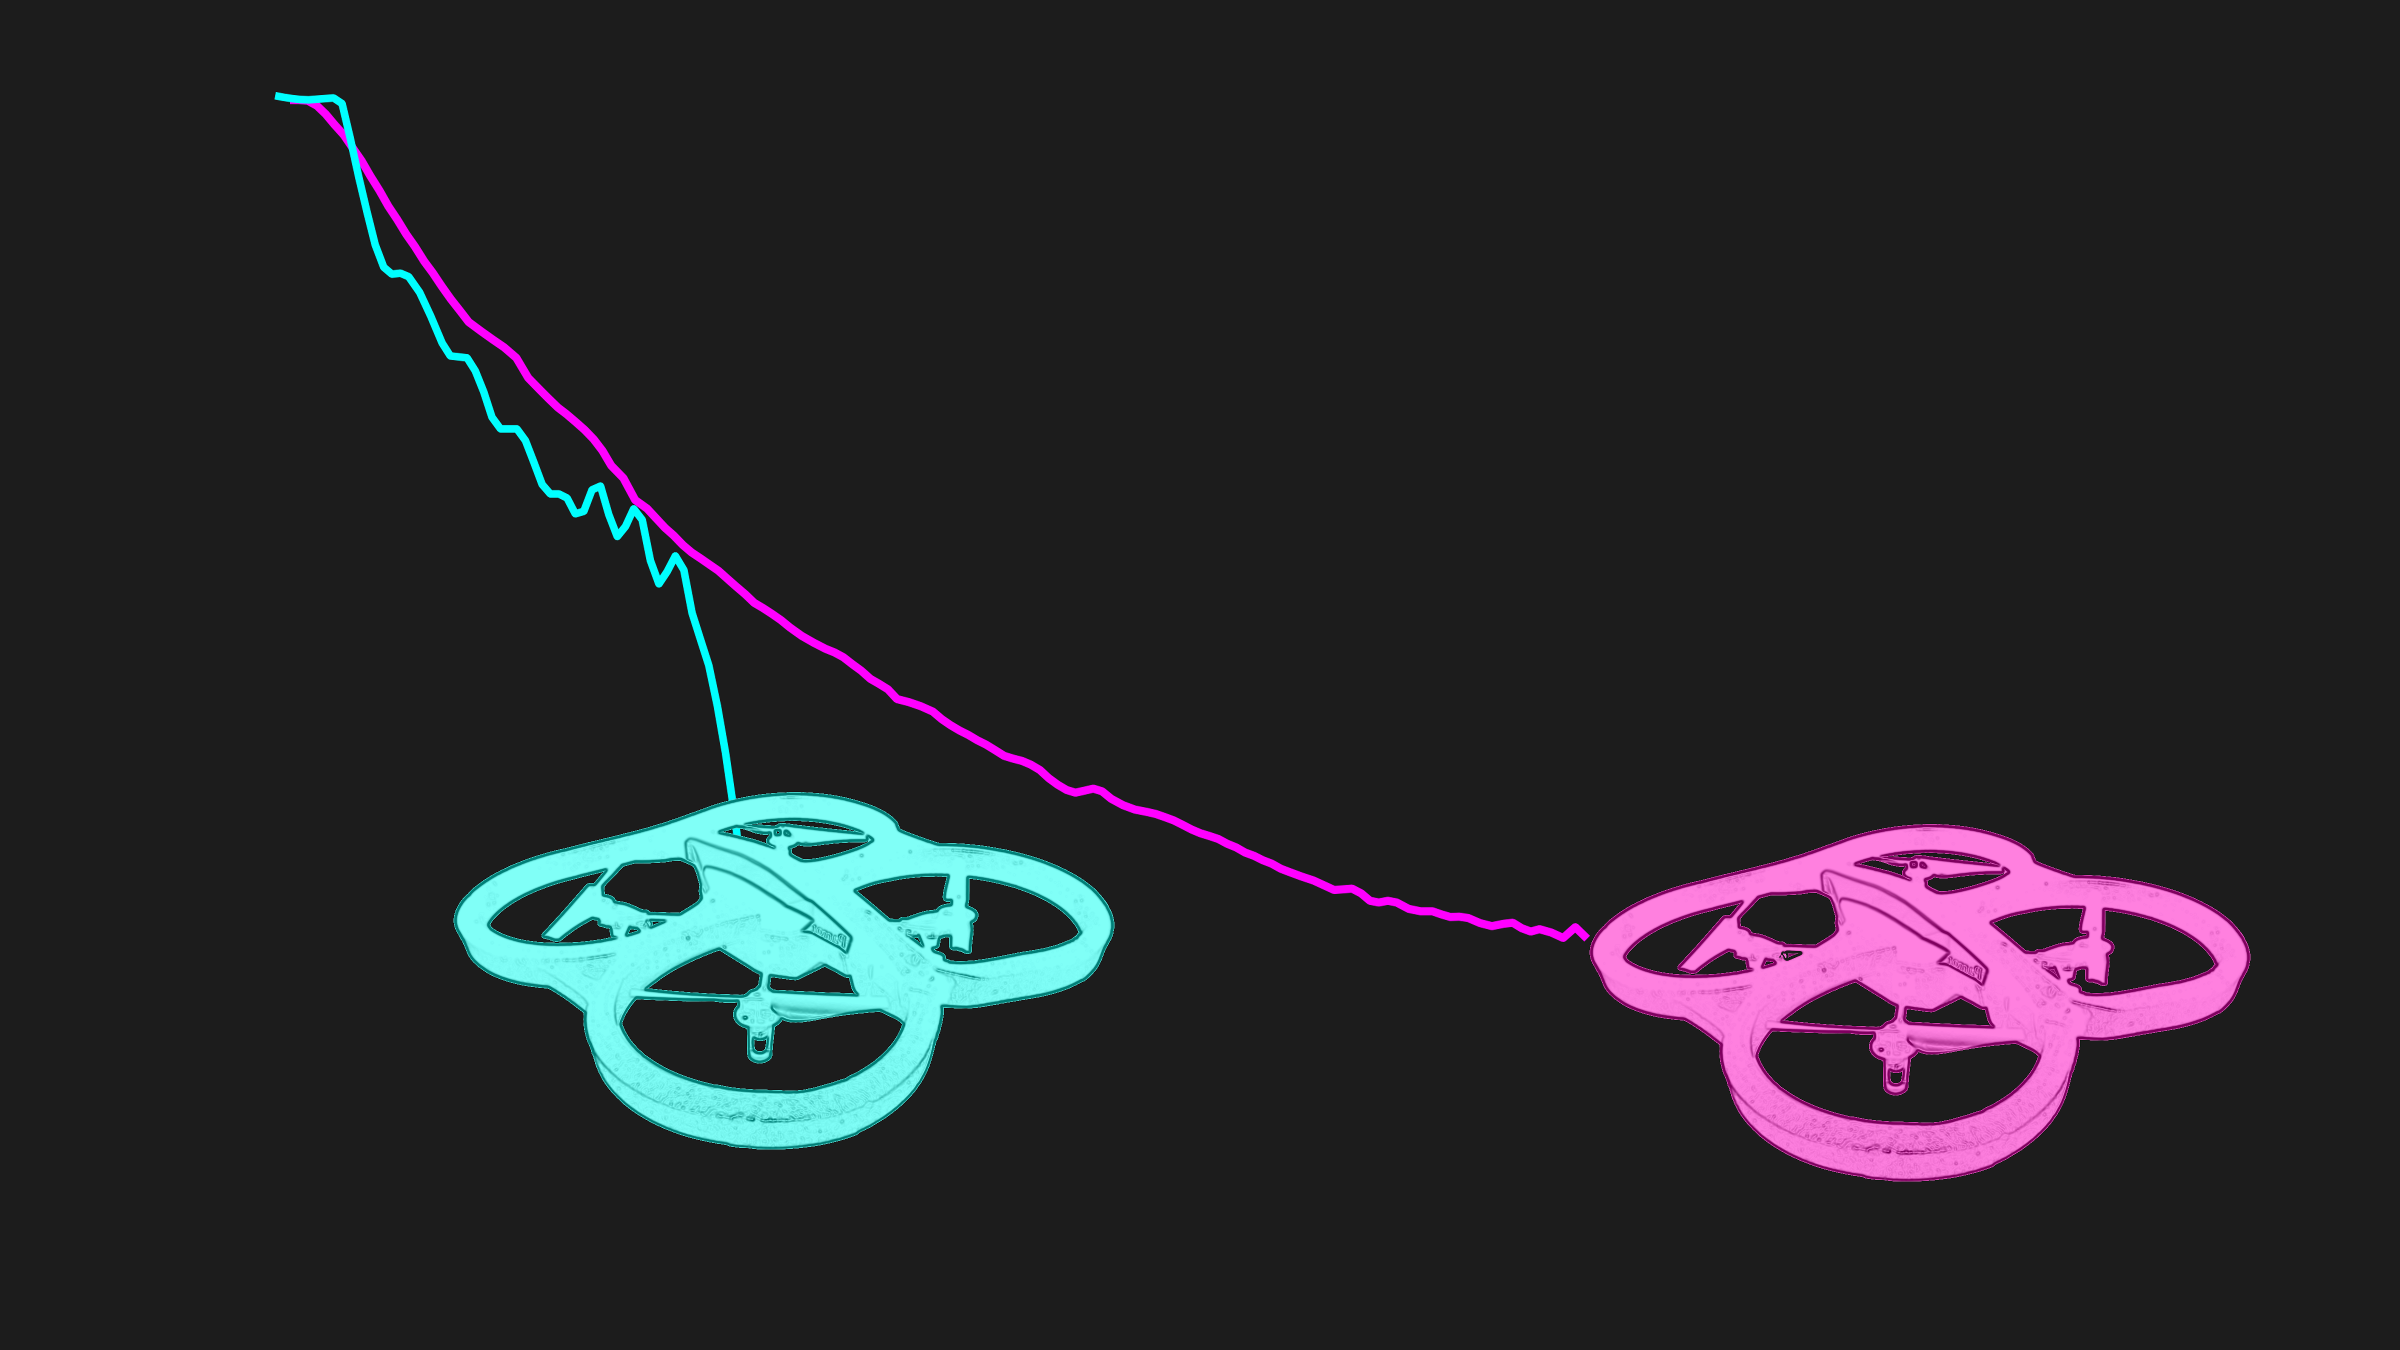
New theory allows drones to see distances with one eye

Posted onJanuary 7, 2016October 30, 2026

A new theory has been published that allows drones to see distances with a single camera. TU Delft’s Micro Air Vehicle Laboratory has found that …
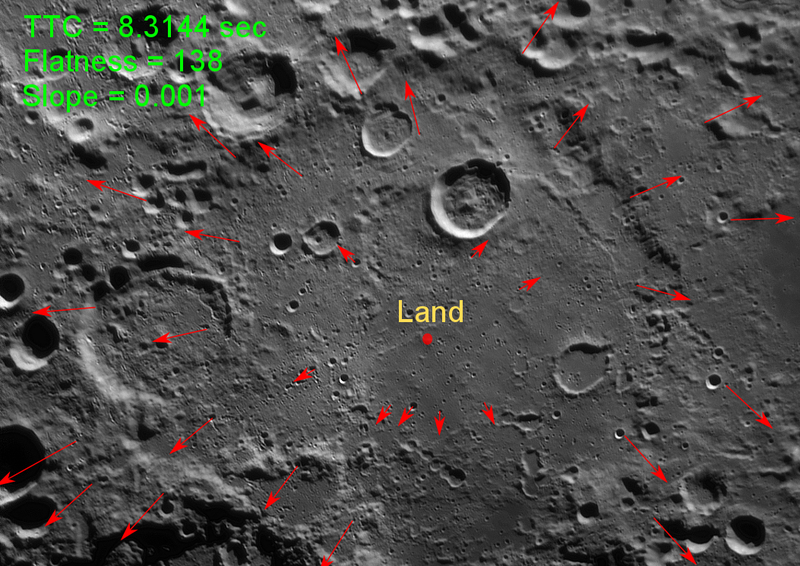
Vision Based Landing
Research

Intelligent Vision-based Landing System of UAVs

Posted onJanuary 1, 2013October 29, 2026

Background The capability of Unmanned Aerial Vehicles (UAVs) to perform landing task is essential for the autonomous operation, especially when they are outside line-of-sight. For autonomous landing, these …

© 2026 MAVLab Powered by WordPress Theme by Design Lab