Skip to content

MAVLab

Micro Air Vehicle Lab – TUDelft

home
  • News
  • Research
    • Research Summary
    • Research
      • Robots
      • Code
      • Open-source code
      • Datasets
      • Competitions
    • Projects
      • Events
    • Spinoffs
  • People
  • Education
    • University Courses
    • Other
  • Publications and Datasets
    • Publications
    • Datasets
    • Open-source code
  • Media
  • Awards
  • Jobs
  • Contact

Tag: open source

IRIDIUM CORE IR9523 CARRIER BOARD
Code

Open Source Iridium Communication IRIDIUM CORE IR9523 Carrier Board

Posted onOctober 1, 2016February 7, 2017

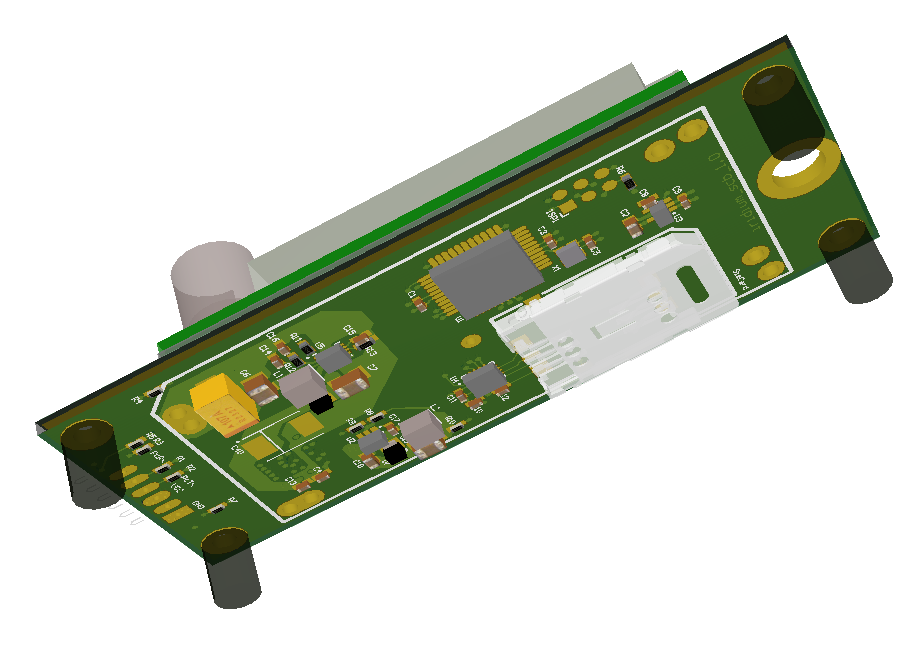
Iridium The MavLab released v1.0 of their Iridium Satellite Communication System. Overall it acts as a transparent link with serial communication at 9600 bps. Internally, …
Competitions, Projects, Robots

DELFTACOPTER – Outback Medical Express

Posted onSeptember 19, 2016October 30, 2026

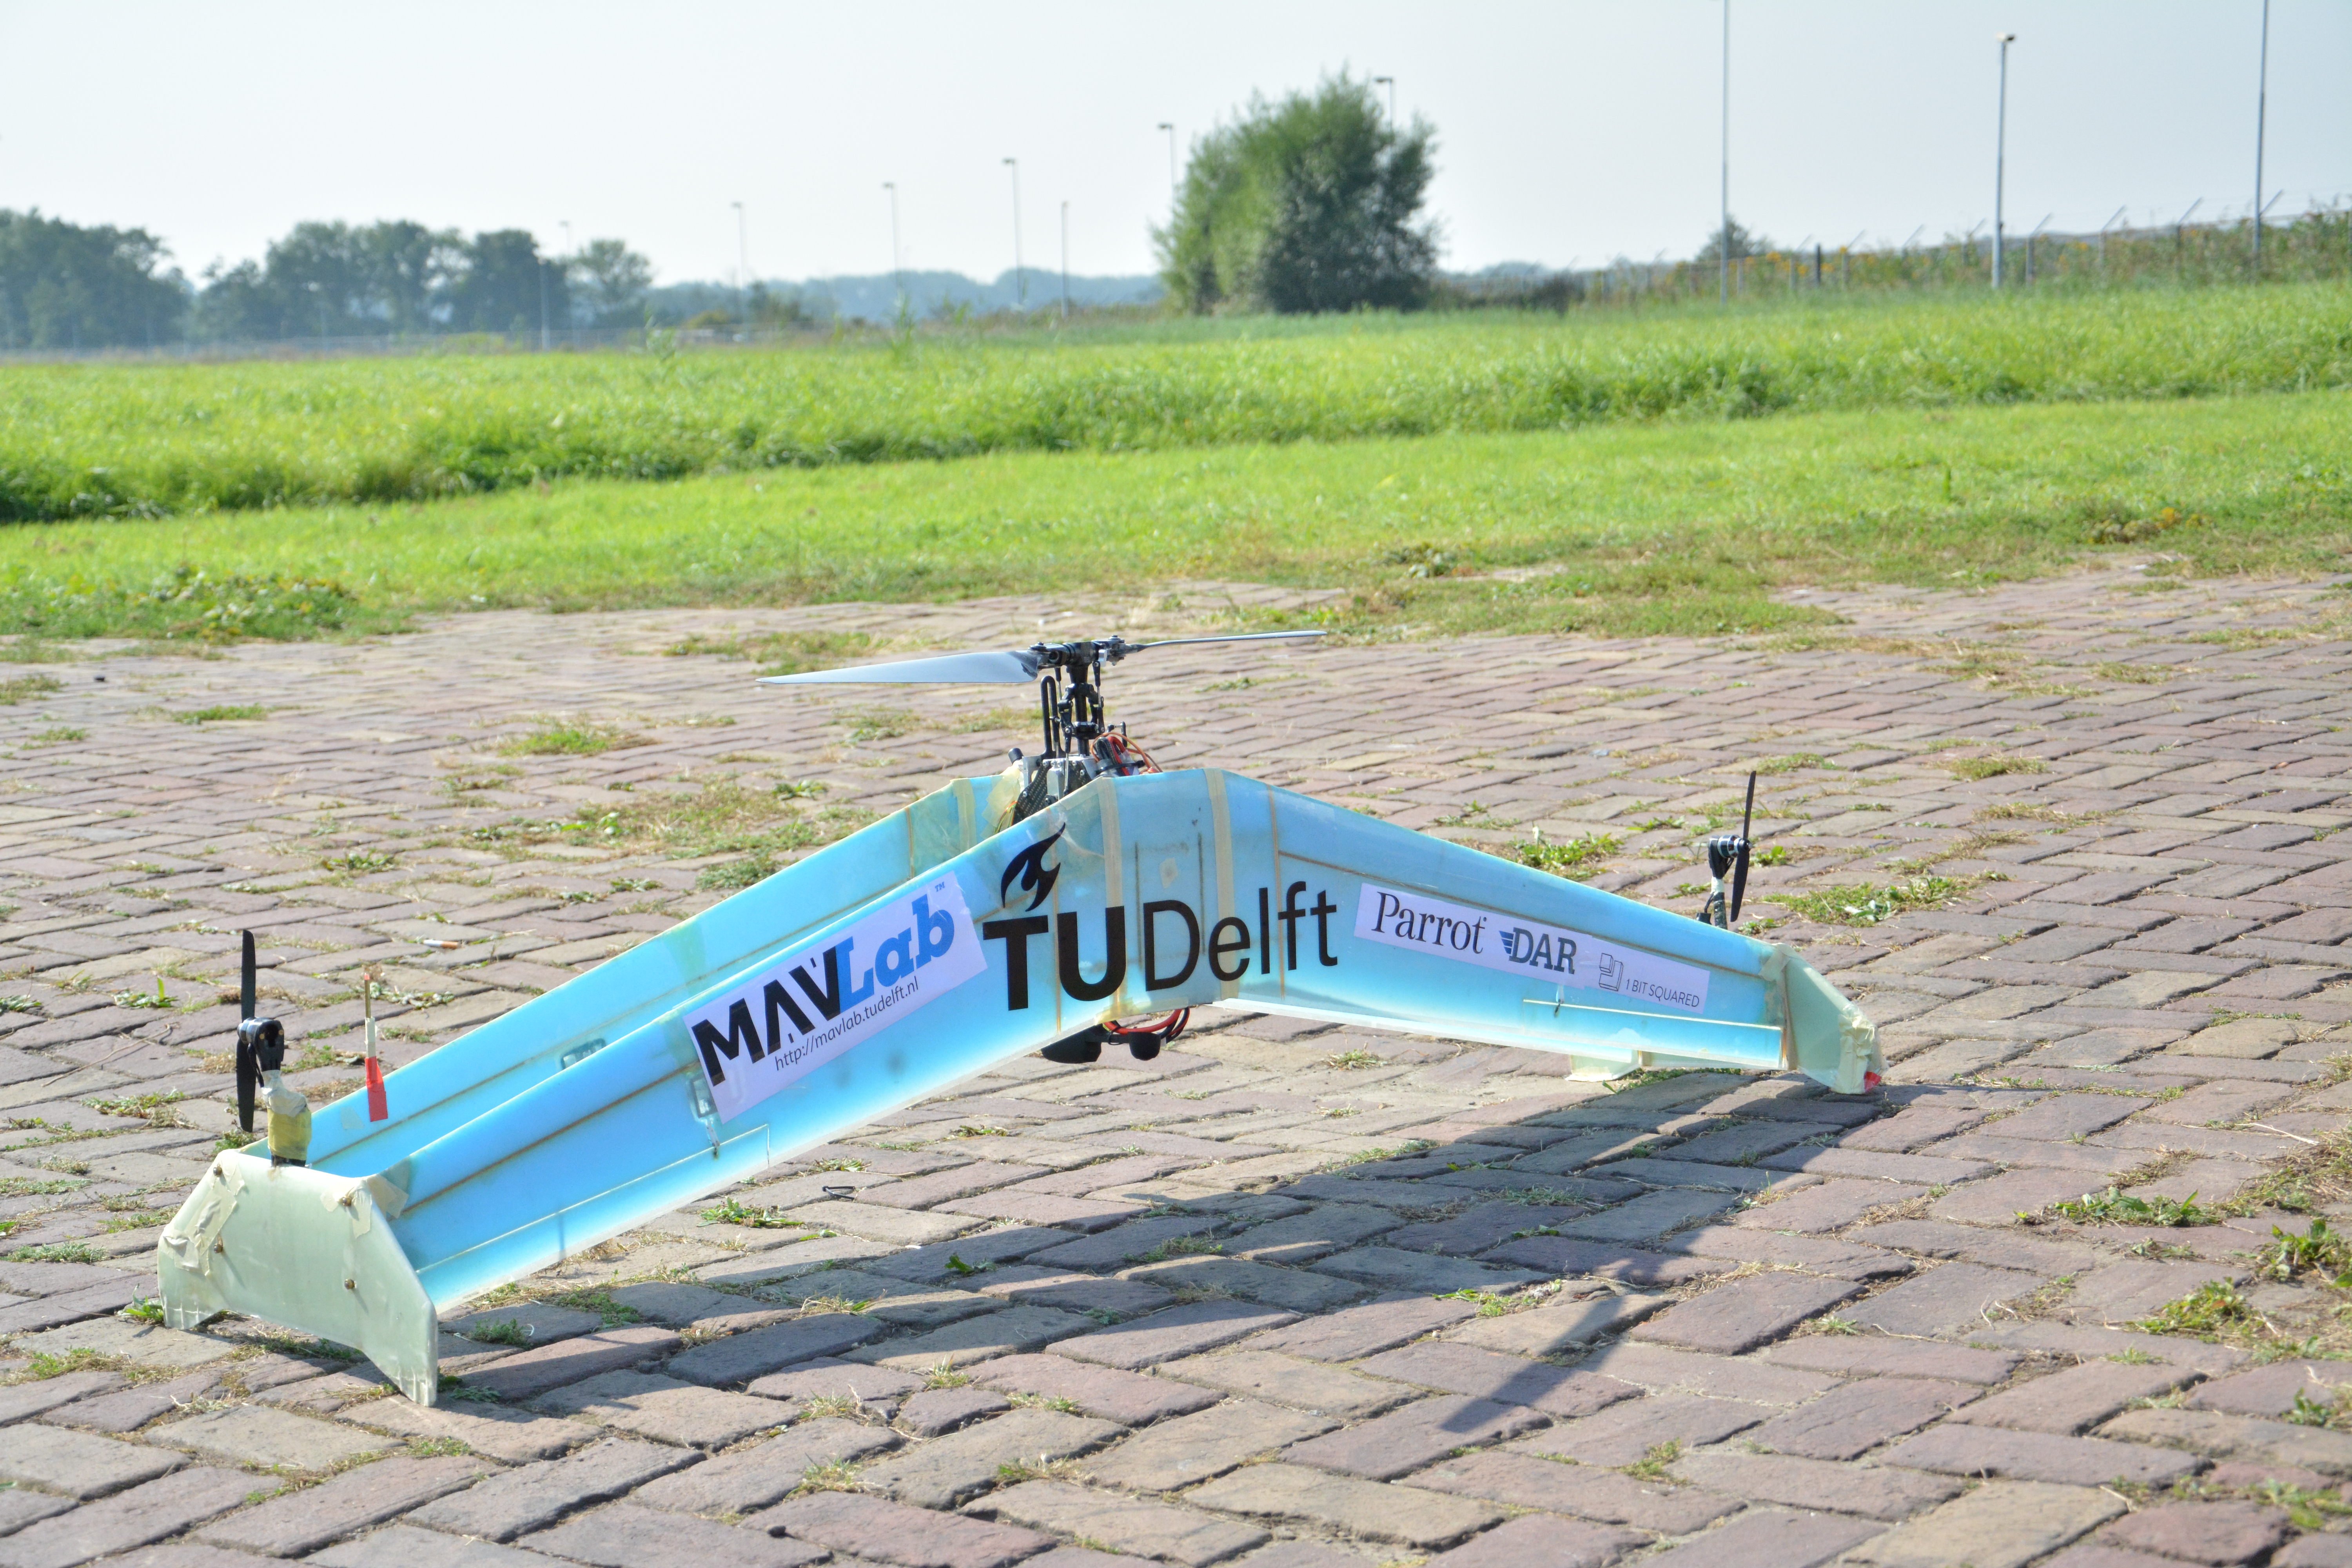
DELFTACOPTER is a hybrid electric UAV with exceptional efficiency both in hovering and fast forward flight. It is equipped with state of the art on-board stereoscopic …

Code

Optical Flow based Slope Estimation

Posted onDecember 15, 2014October 29, 2026

Our open-source “Optical Flow based Slope Estimation” code can be found: first_release_OF_slope_estimation publication:

paparazzi lisa-s
Code, Research

LISA-S: “the world’s smallest open source autopilot”

Posted onAugust 26, 2013October 30, 2026

he Micro Aerial Vehicle Laboratory at the TU Delft faculty of Aerospace Engineering has designed, built and tested the world’s smallest open source autopilot for …

© 2026 MAVLab Powered by WordPress Theme by Design Lab