Neuromorphic processors like Loihi offer a promising alternative to conventional computing modules for endowing constrained systems like micro air vehicles (MAVs) with robust, …
Micro Air Vehicle Lab – TUDelft
Neuromorphic processors like Loihi offer a promising alternative to conventional computing modules for endowing constrained systems like micro air vehicles (MAVs) with robust, …
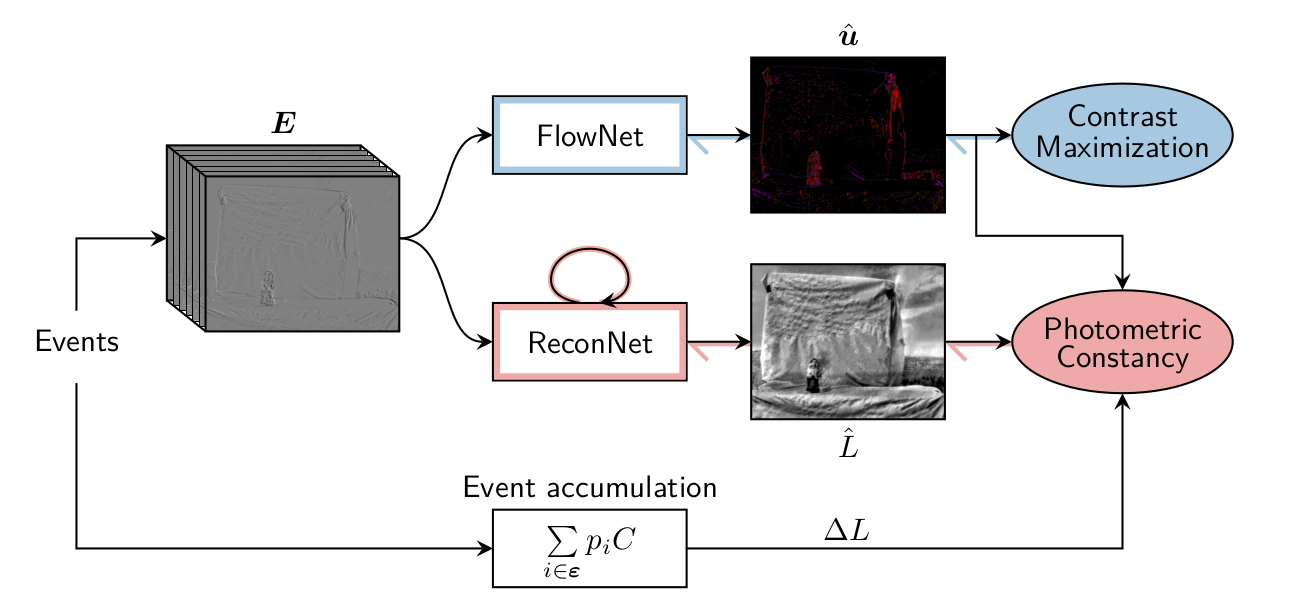
F. Paredes-Valles, G. C. H. E. de Croon Event cameras are novel vision sensors that sample, in an asynchronous fashion, brightness increments with low latency …
<description> Paper <description> Code cuSNN is available on GitHub via the following link: Github Page
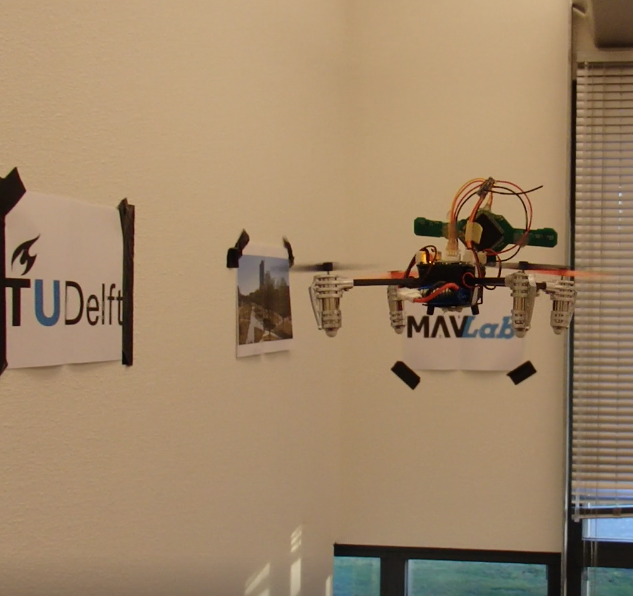
In recent experiments, we were able to show a 40-gram pocket drone flying inside an indoor environment, autonomously, using nothing but a 4-gram stereo-camera. With …

Parapazzi Introductory Course Please find the introduction to vision based control with the paparazzi autopilot on a Bebop in an Optitrack arena at: https://tudelft.github.io/coursePaparazzi/ Video …
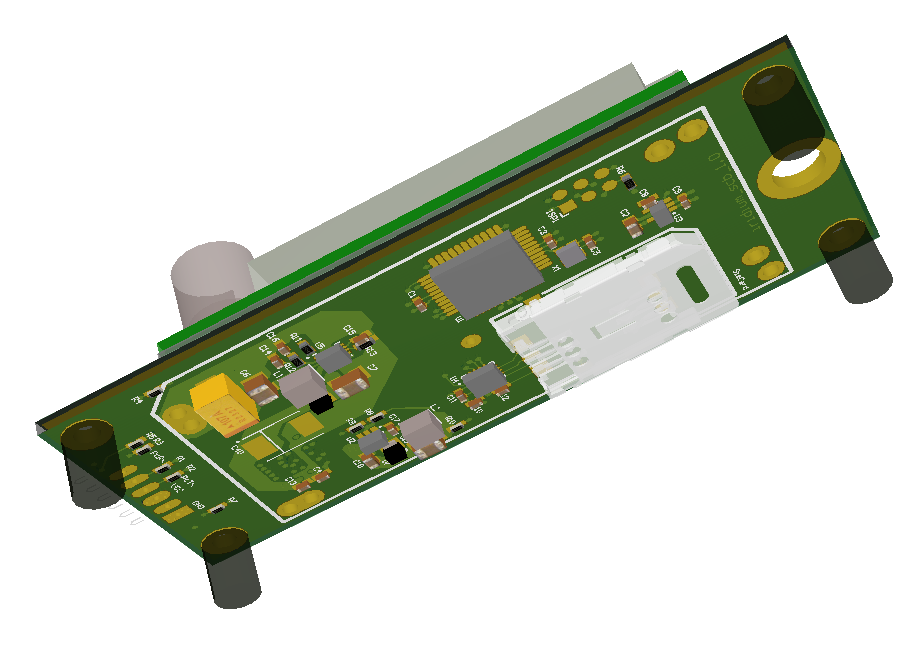
Iridium The MavLab released v1.0 of their Iridium Satellite Communication System. Overall it acts as a transparent link with serial communication at 9600 bps. Internally, …
A new theory has been published that allows drones to see distances with a single camera. TU Delft’s Micro Air Vehicle Laboratory has found that …

Our open-source “Optical Flow based Slope Estimation” code can be found: first_release_OF_slope_estimation publication:

he Micro Aerial Vehicle Laboratory at the TU Delft faculty of Aerospace Engineering has designed, built and tested the world’s smallest open source autopilot for …

The MAVLab participates in several open source projects. The projects can be found on github: http://www.github.com/tudelft/