Skip to content

MAVLab

Micro Air Vehicle Lab – TUDelft

home
  • News
  • Research
    • Research Summary
    • Research
      • Robots
      • Code
      • Open-source code
      • Datasets
      • Competitions
    • Projects
      • Events
    • Spinoffs
  • People
  • Education
    • University Courses
    • Other
  • Publications and Datasets
    • Publications
    • Datasets
    • Open-source code
  • Media
  • Awards
  • Jobs
  • Contact
  • News
  • Research
    • Research Summary
    • Research
      • Robots
      • Code
      • Open-source code
      • Datasets
      • Competitions
    • Projects
      • Events
    • Spinoffs
  • People
  • Education
    • University Courses
    • Other
  • Publications and Datasets
    • Publications
    • Datasets
    • Open-source code
  • Media
  • Awards
  • Jobs
  • Contact

Category: Code

Code, Datasets, News, Research

Honeybees teach drones how to navigate

Posted onMay 13, 2026November 4, 2026

It sounds like science fiction, but also strangely familiar: drones buzzing around, inspecting tomatoes in greenhouses, delivering your package or inspecting an industrial site. With …
Code, Datasets, News, Research

All Eyes, no IMU: Learning Flight Attitude from Vision Alone

Posted onDecember 15, 2025October 30, 2026

Our work on estimating attitude and angular rate with vision alone has been accepted for publication in Nature Portfolio Journals Robotics! It is part of …
Code, News, Research

Depth Transfer: Learning to See Like a Simulator for Real-World Drone Navigation

Posted onOctober 9, 2025October 30, 2026

🧠 Bridging the Gap Between Simulation and Reality Training drones to navigate complex environments autonomously is one of the central challenges in robotics. While simulators …
Code, News, Research

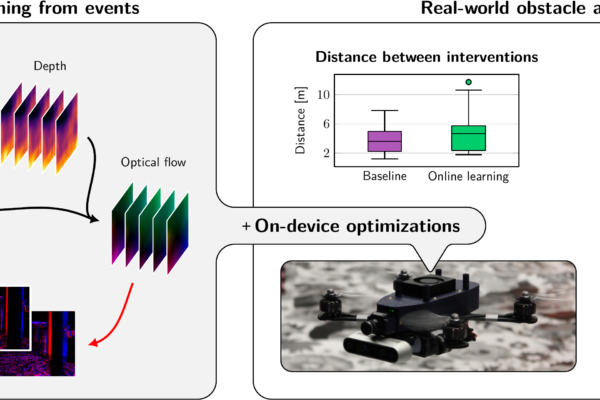
On-Device Self-Supervised Learning of Low-Latency Monocular Depth from Only Events

Posted onMarch 24, 2025October 30, 2026

Our work on online, on-board learning of depth from events has been accepted at CVPR 2025. Event cameras provide low-latency perception for only milliwatts of …
Code, Datasets, News, Research

MAVRL: Learn to Fly in Cluttered Environments with Varying Speed

Posted onJanuary 15, 2025October 30, 2026

We introduce a novel obstacle avoidance pipeline named Memory-Augmented Varying-speed Reinforcement Learning (MAVRL). MAVRL utilizes depth maps, along with the drone and target’s states as …

Code, Datasets, News, Research

Fully neuromorphic vision and control for autonomous drone flight

Posted onApril 28, 2024October 30, 2026

Our work on fully neuromorphic vision and control for autonomous drone flight has been published in the Science Robotics May 2024 issue. In this work, …
Code, Datasets, Research

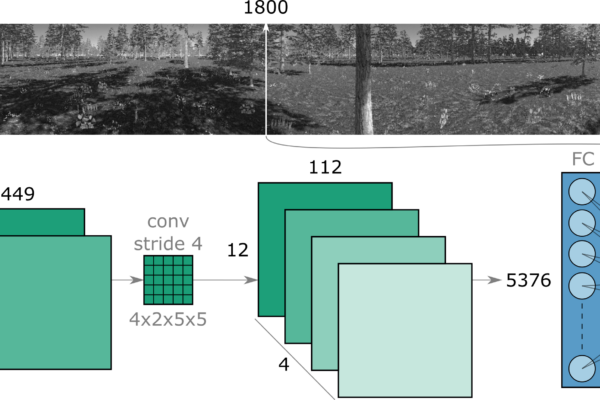
Direct learning of home vector direction for insect-inspired robot navigation (ICRA’24)

Posted onApril 28, 2024October 30, 2026

Abstract Insects have long been recognized for their ability to navigate and return home using visual cues from their nest’s environment. However, the precise mechanism …
Code, Research

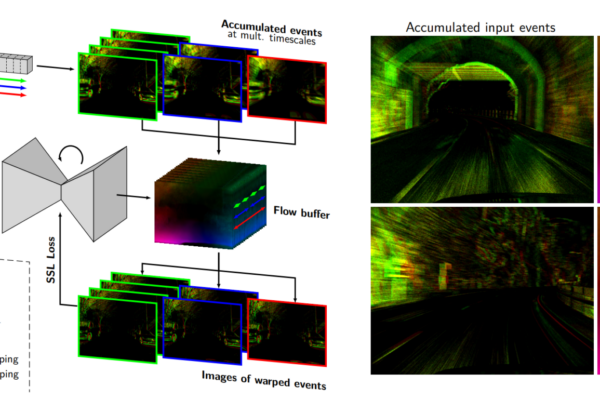
Taming Contrast Maximization for Learning Sequential, Low-latency, Event-based Optical Flow

Posted onAugust 11, 2023October 30, 2026

    Federico Paredes-Vallés, Kirk W. Y. Scheper, Christophe De Wagter, Guido C. H. E. de Croon   Event cameras have recently gained significant traction …
Code, Events, News, Research

AvoidBench @ ICRA 2023

Posted onJune 1, 2023October 30, 2026

At ICRA (IEEE International Conference on Robotics and Automation) 2023, MAVLab presented AvoidBench, a high-fidelity vision-based obstacle avoidance benchmarking suite for multi-rotors. Motivation Vision-based obstacle …

Code, Research

Self-Supervised Learning of Event-Based Optical Flow with Spiking Neural Networks

Posted onOctober 25, 2021October 30, 2026

    Jesse J. Hagenaars*, Federico Paredes-Vallés*, Guido C.H.E. de Croon   The field of neuromorphic computing promises extremely low-power and low-latency sensing and processing. …

Posts pagination

1 2 ‹
© 2026 MAVLab Powered by WordPress Theme by Design Lab