Skip to content

MAVLab

Micro Air Vehicle Lab – TUDelft

home
  • News
  • Research
    • Research Summary
    • Research
      • Robots
      • Code
      • Open-source code
      • Datasets
      • Competitions
    • Projects
      • Events
    • Spinoffs
  • People
  • Education
    • University Courses
    • Other
  • Publications and Datasets
    • Publications
    • Datasets
    • Open-source code
  • Media
  • Awards
  • Jobs
  • Contact
  • News
  • Research
    • Research Summary
    • Research
      • Robots
      • Code
      • Open-source code
      • Datasets
      • Competitions
    • Projects
      • Events
    • Spinoffs
  • People
  • Education
    • University Courses
    • Other
  • Publications and Datasets
    • Publications
    • Datasets
    • Open-source code
  • Media
  • Awards
  • Jobs
  • Contact
Code Datasets News Research

Honeybees teach drones how to navigate

Posted onMay 13, 2026November 4, 2026
Code Datasets News Research

All Eyes, no IMU: Learning Flight Attitude from Vision Alone

Posted onDecember 15, 2025October 30, 2026
Code News Research

Depth Transfer: Learning to See Like a Simulator for Real-World Drone Navigation

Posted onOctober 9, 2025October 30, 2026
Competitions

First place and innovation award at IMAV 2018

A team of TU Delft and ENAC researchers has won the overall 1st prize at the outdoor competition of the International Micro Air Vehicle conference …
By Christophe De Wagter
Posted onDecember 5, 2018April 29, 2019
DelFly Nimble
Competitions, Research

MAVLAB off to IMAV 2018

Posted onNovember 12, 2018October 29, 2026

Next week, the MAVLab will be off to the 10th International Micro Air Vehicle Competition and Conference, which will take place in the beautiful Melbourne …
Projects, Research, Robots

Pelican Drone

Posted onOctober 31, 2018October 30, 2026

Besides dikes, the Netherlands are well known for its many lakes and rivers. It is difficult and labor intensive to properly monitor them all, even …

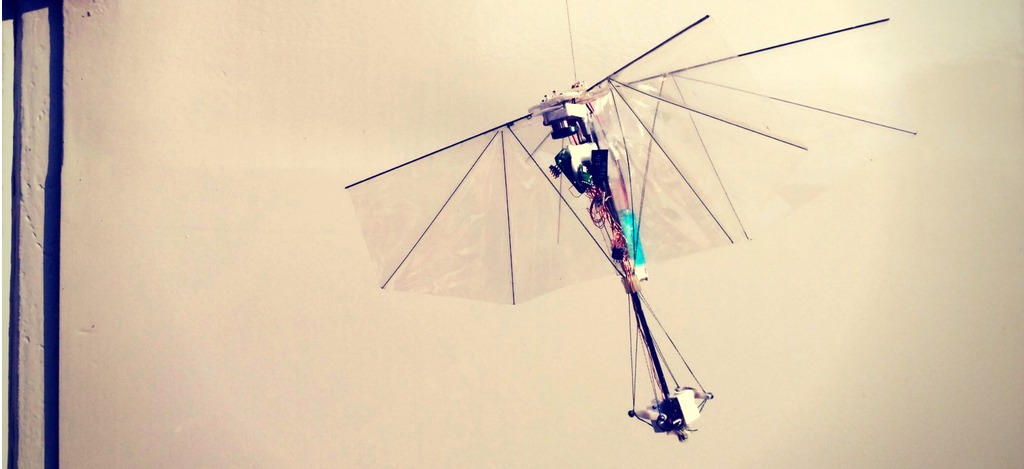
DelFly Nimble in hovering flight. Credits: Henri Werij, TU Delft.
Datasets

A tailless aerial robotic flapper reveals that flies use torque coupling in rapid banked turns

Posted onSeptember 14, 2018October 29, 2026

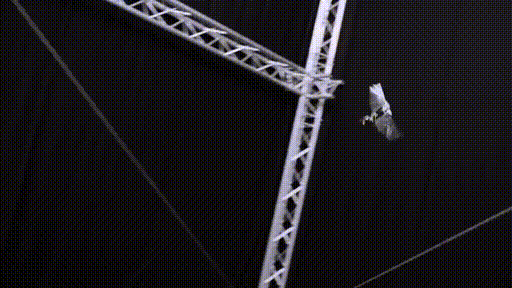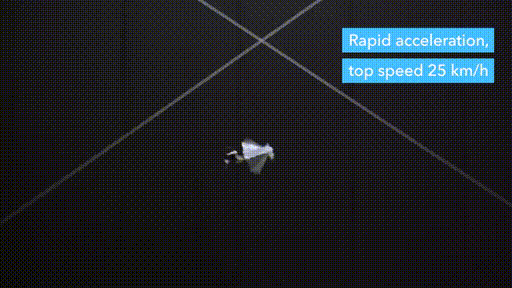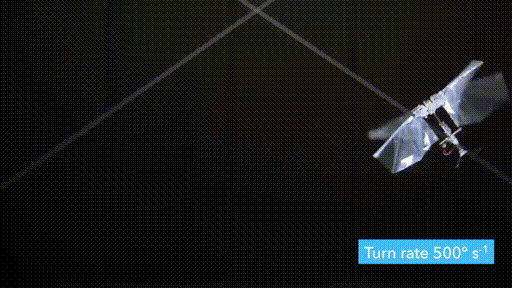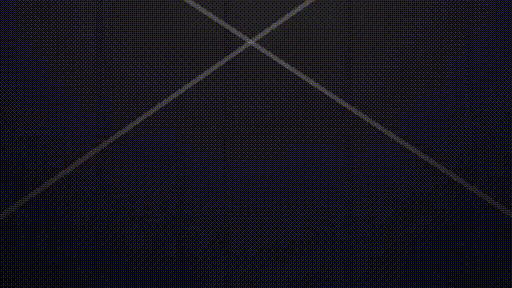
The dataset contains robotic flight data of high agility maneuvers and fruit-fly inspired rapid banked turns, which are reported in the manuscript “A tailless aerial robotic flapper reveals that flies use torque coupling in rapid banked turns”.
Datasets, Robots

DelFly Nimble

Posted onSeptember 13, 2018October 30, 2026

The DelFly Nimble, a new bio-inspired robot developed by MAVLab and employed for insect-flight research, is featured on the cover of the September 14 issue …
Tom van Dijk
News

New PhD student: Tom van Dijk

Posted onNovember 13, 2017October 29, 2026

We are happy to introduce a new Ph.D. student – Tom van Dijk – within the project “PercEvite: Sense and avoid technology for small drones”. …
Research

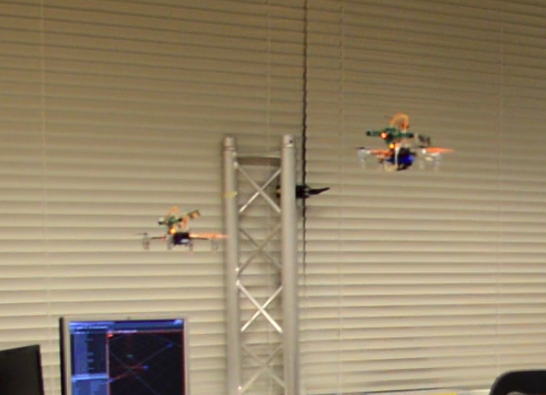
Paper: Towards a swarm with pocket drones – IROS 2017

Posted onOctober 20, 2017October 29, 2026

In a previous post, we showed that a tiny 40-gram pocket drone can fly autonomously inside a room. Now we stepped it up a notch, …

Competitions

3rd place (and more) at the IMAV2017

Posted onOctober 19, 2017October 29, 2026

With a 3rd place prize, a best paper prize and a best system prize at the 2017 installation of the annual International Micro Air Vehicle …
Cyclone
Research, Robots

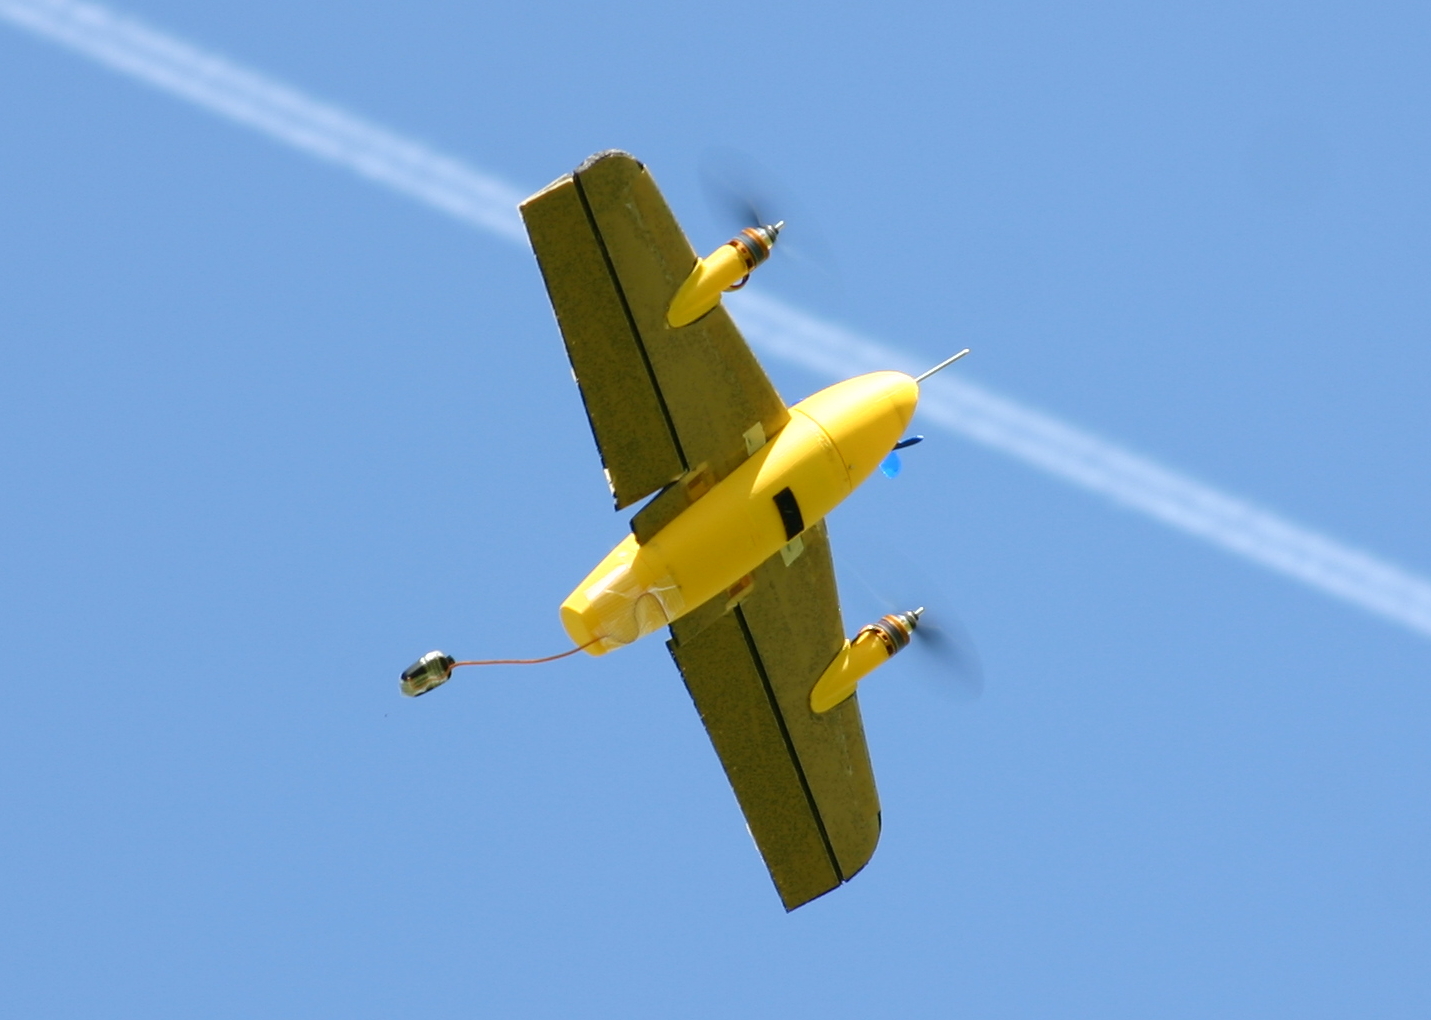
Control of the Cyclone Hybrid UAV

Posted onJune 13, 2017October 29, 2026

Cyclone In cooperation with the dronelab of ENAC in Toulouse, we have developed a hybrid UAV, called ‘Cyclone’. It is hybrid in the sense that …
Code, Research

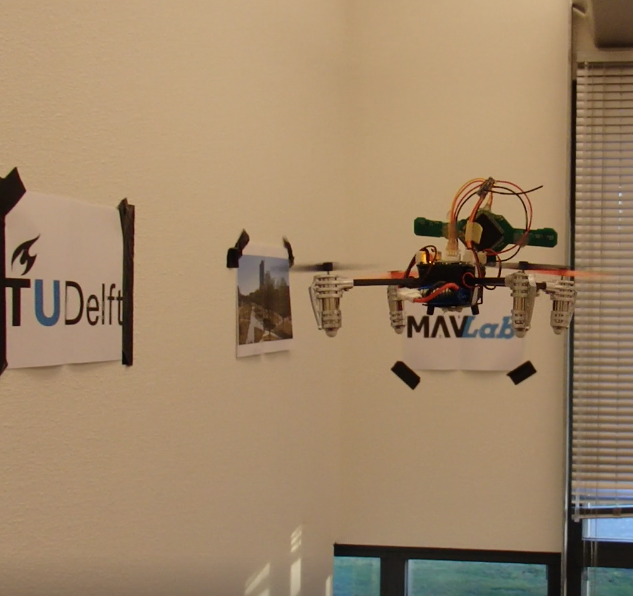
Towards an autonomous pocket drone for indoor navigation

Posted onJune 12, 2017October 30, 2026

In recent experiments, we were able to show a 40-gram pocket drone flying inside an indoor environment, autonomously, using nothing but a 4-gram stereo-camera. With …

Posts pagination

‹ 1 … 4 5 6 7 8 … 11 ›
© 2026 MAVLab Powered by WordPress Theme by Design Lab